Related Experiment Video
Updated: Jun 28, 2026
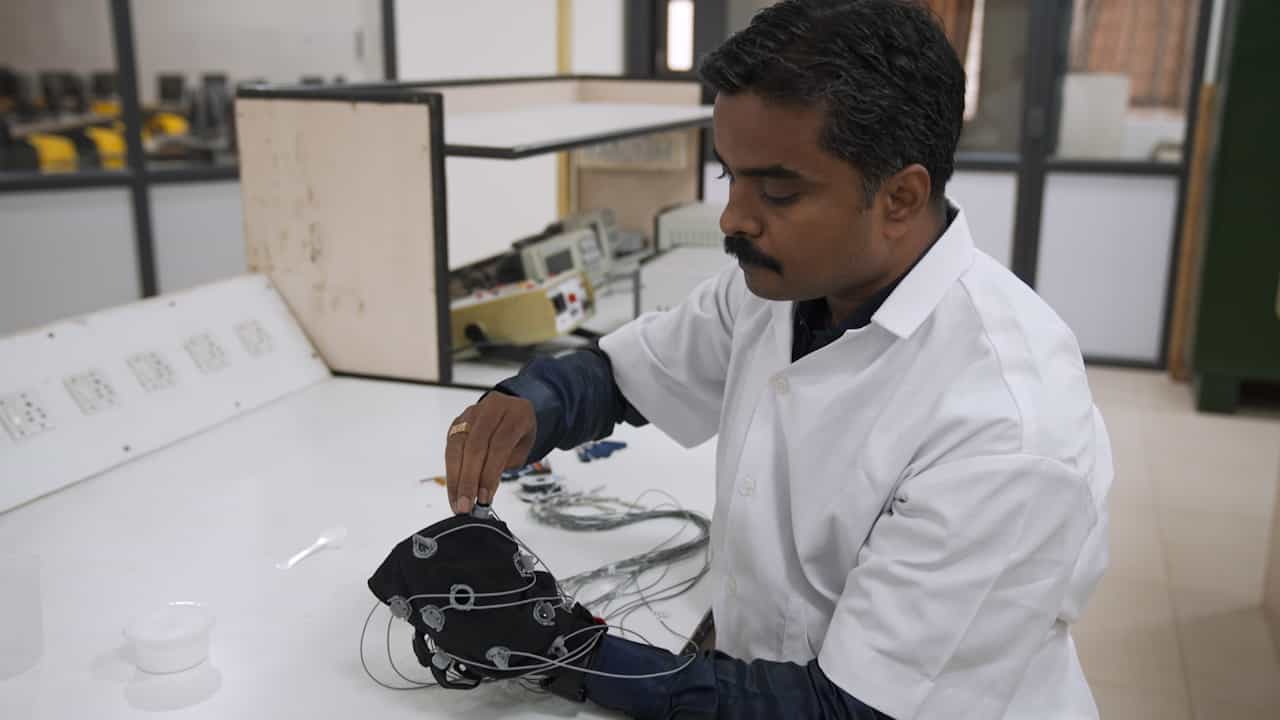

Motor Imagery Performance Through Embodied Digital Twins in a Virtual Reality-Enabled Brain-Computer Interface Environment
Published on: May 10, 2024
The kinematics of motor imagery: comparing the dynamics of real and virtual movements
Manuel Rodriguez1, Catalina Llanos, Magdalena Sabate
1Department of Physiology, University of La Laguna, Tenerife, Canary Islands, Spain. mrdiaz@ull.es

Abstract:
Motor imagery (MI) is a key tool for studying the cognitive functions of movement. These studies assume that movements and their MI (virtual movements) involve the same cognitive functions. The real-virtual isochrony and isometry of movements of different complexity and accuracy, and the kinematics of real and virtual movements (real-virtual spatial homology and partial isometry) were studied to test this hypothesis. Isochrony was high in complex attention-demanding tasks but not in simple or inaccurate tasks, with isometry and spatial homology also being different for different motor patterns. These data suggest that movements and their MI do not always involve the same cognitive functions, and are particularly different in simple motor tasks requiring low attention levels.
More Related Videos

Related Concept Videos
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:20
Virtual Work
In static equilibrium, a body can experience an imaginary or virtual movement, such as displacement or rotation. The virtual work done by a force is equal to the dot product of force and virtual displacement in the direction of the force. When it comes to virtually rotating a...
 01:20
Instantaneous Center of Zero Velocity
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:10
Relative Motion Analysis - Acceleration
 01:18
Kinematic Equations - III
Using the kinematic equations,...