A computational model for rhythmic and discrete movements in uni- and bimanual coordination
Related Experiment Video
Updated: Jun 27, 2026
Efficiently Recording the Eye-Hand Coordination to Incoordination Spectrum
Published on: March 21, 2019
Renaud Ronsse1, Dagmar Sternad, Philippe Lefèvre
1Department of Electrical Engineering and Computer Science, Montefiore Institute, Université de Liège, B-4000 Liège, Belgium. Renaud.Ronsse@faber.kuleuven.be

Abstract:
Current research on discrete and rhythmic movements differs in both experimental procedures and theory, despite the ubiquitous overlap between discrete and rhythmic components in everyday behaviors. Models of rhythmic movements usually use oscillatory systems mimicking central pattern generators (CPGs). In contrast, models of discrete movements often employ optimization principles, thereby reflecting the higher-level cortical resources involved in the generation of such movements. This letter proposes a unified model for the generation of both rhythmic and discrete movements. We show that a physiologically motivated model of a CPG can not only generate simple rhythmic movements with only a small set of parameters, but can also produce discrete movements if the CPG is fed with an exponentially decaying phasic input. We further show that a particular coupling between two of these units can reproduce main findings on in-phase and antiphase stability. Finally, we propose an integrated model of combined rhythmic and discrete movements for the two hands. These movement classes are sequentially addressed in this letter with increasing model complexity. The model variations are discussed in relation to the degree of recruitment of the higher-level cortical resources, necessary for such movements.
Related Concept Videos
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement.
 01:18
Hierarchy of Motor Control
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:15
Kinematic Equations: Problem Solving
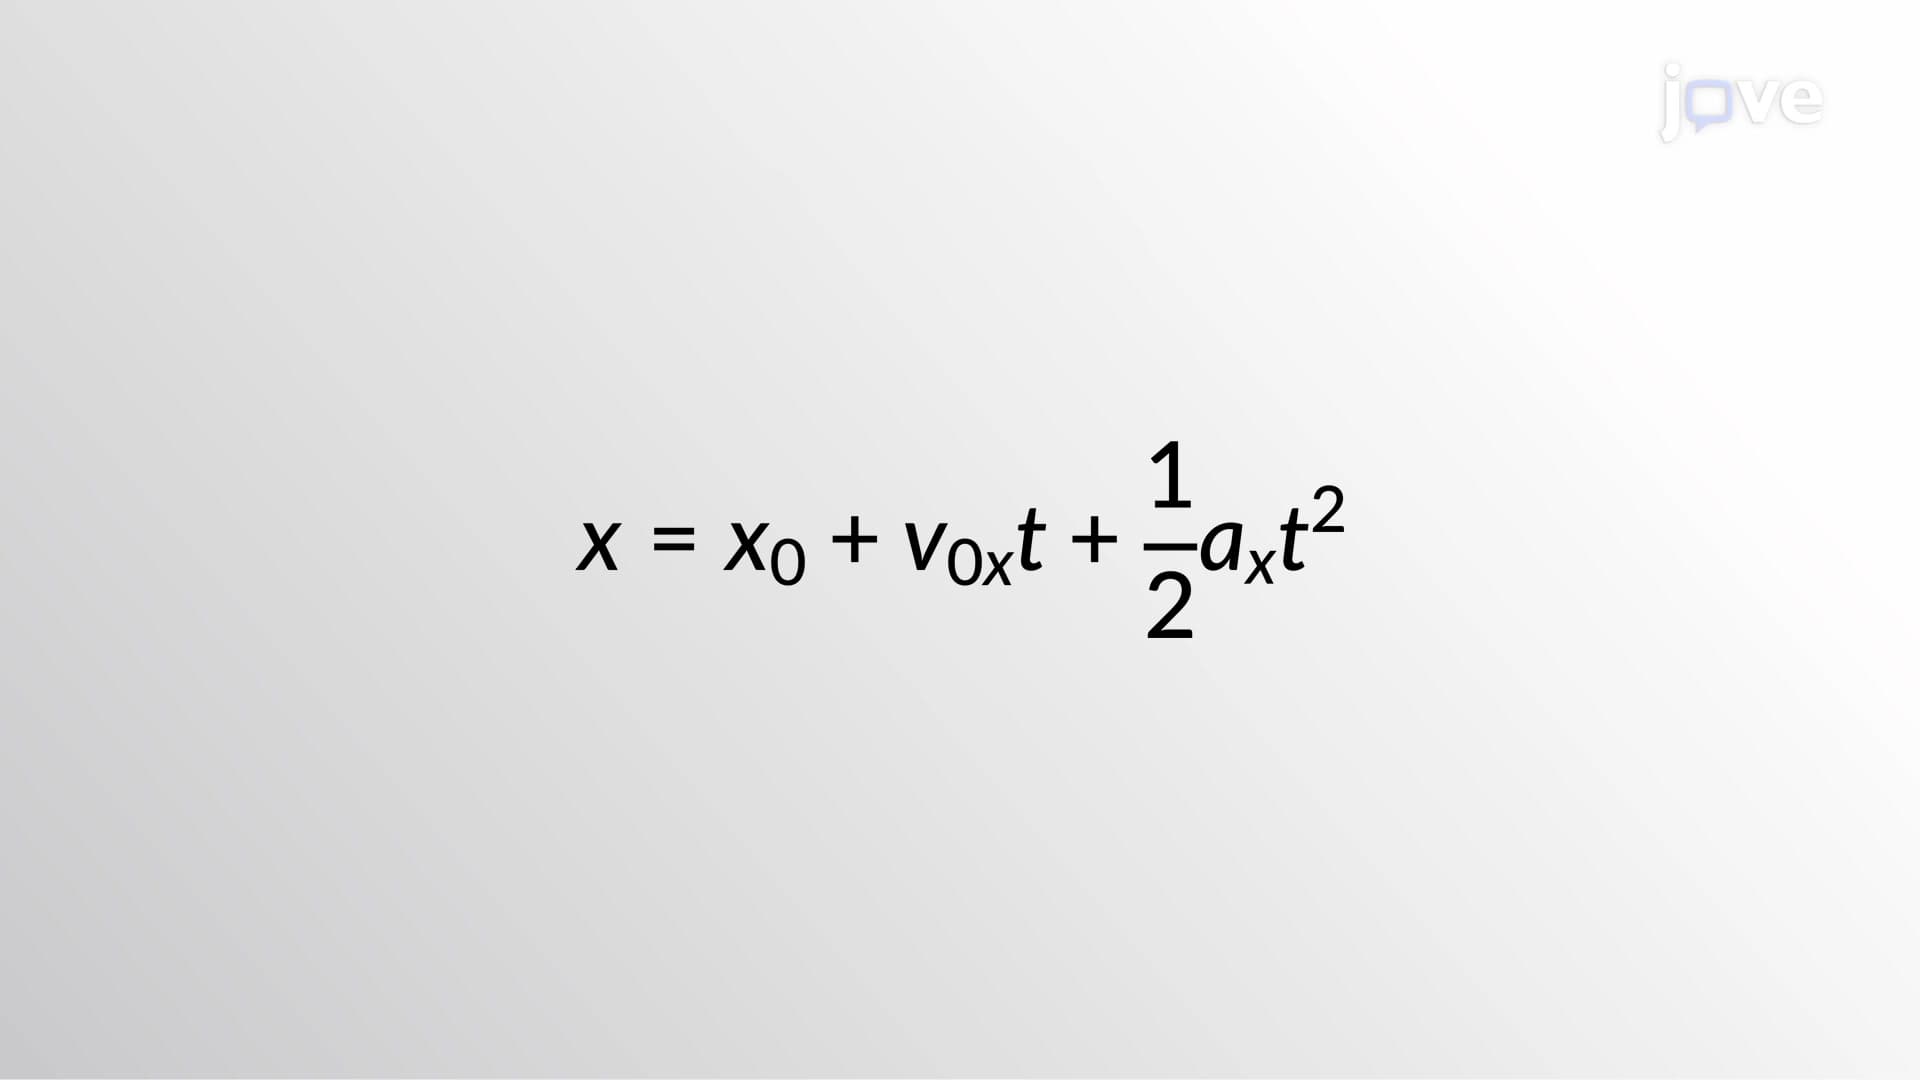 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
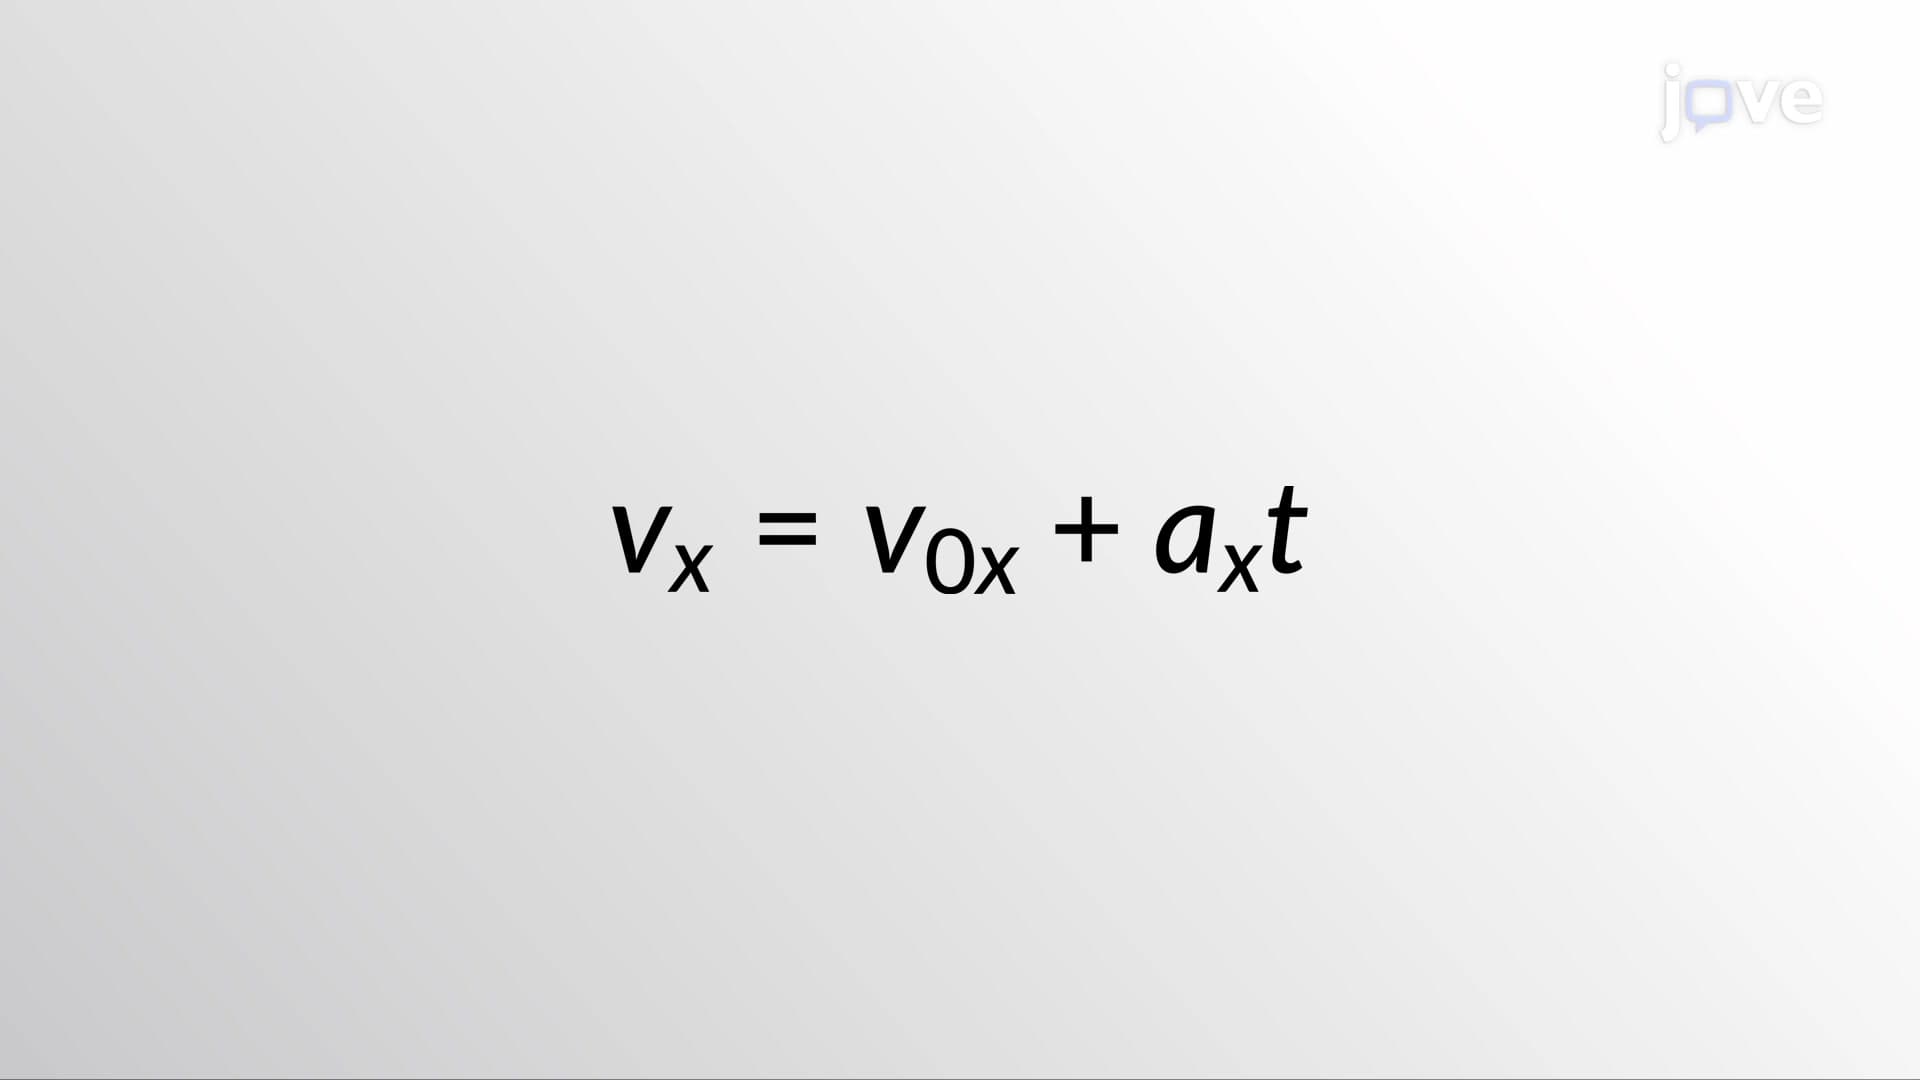 01:26
Kinematic Equations - I