Sliding-mode repetitive learning control with integral sliding-mode perturbation compensation

1Department of Mechatronic Technology, National Taiwan Normal University, Taipei 106, Taiwan. luys@ntnu.edu.tw

Abstract:
This paper proposes a sliding-mode repetitive learning control (SMRLC) scheme with an integral sliding-mode perturbation observer (ISMPO) for repetitive tracking control tasks. The three control strategies which are synthesized to yield excellent tracking performance are: (1) the pole-placement feedback control to specify the desired error dynamics; (2) ISMPO-based feedback compensation as the robust part; and (3) a feedforward learning component that refines the control to improve system performance through repetitive trials. The ISMPO-based feedback compensation ensures that there is only small tracking error during initial learning trials and enhances system insensitivity to exceptional and aperiodic disturbances. The feedforward learning compensation is updated according to a certain switching signal that is equivalent to the compensation error of the feedforward control, yielding fast convergence of the learning process from trial to trial. Experimental results demonstrate the feasibility of the proposed scheme.

Related Concept Videos
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:24
PI Controller: Design
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:19
PID Controller
 01:14
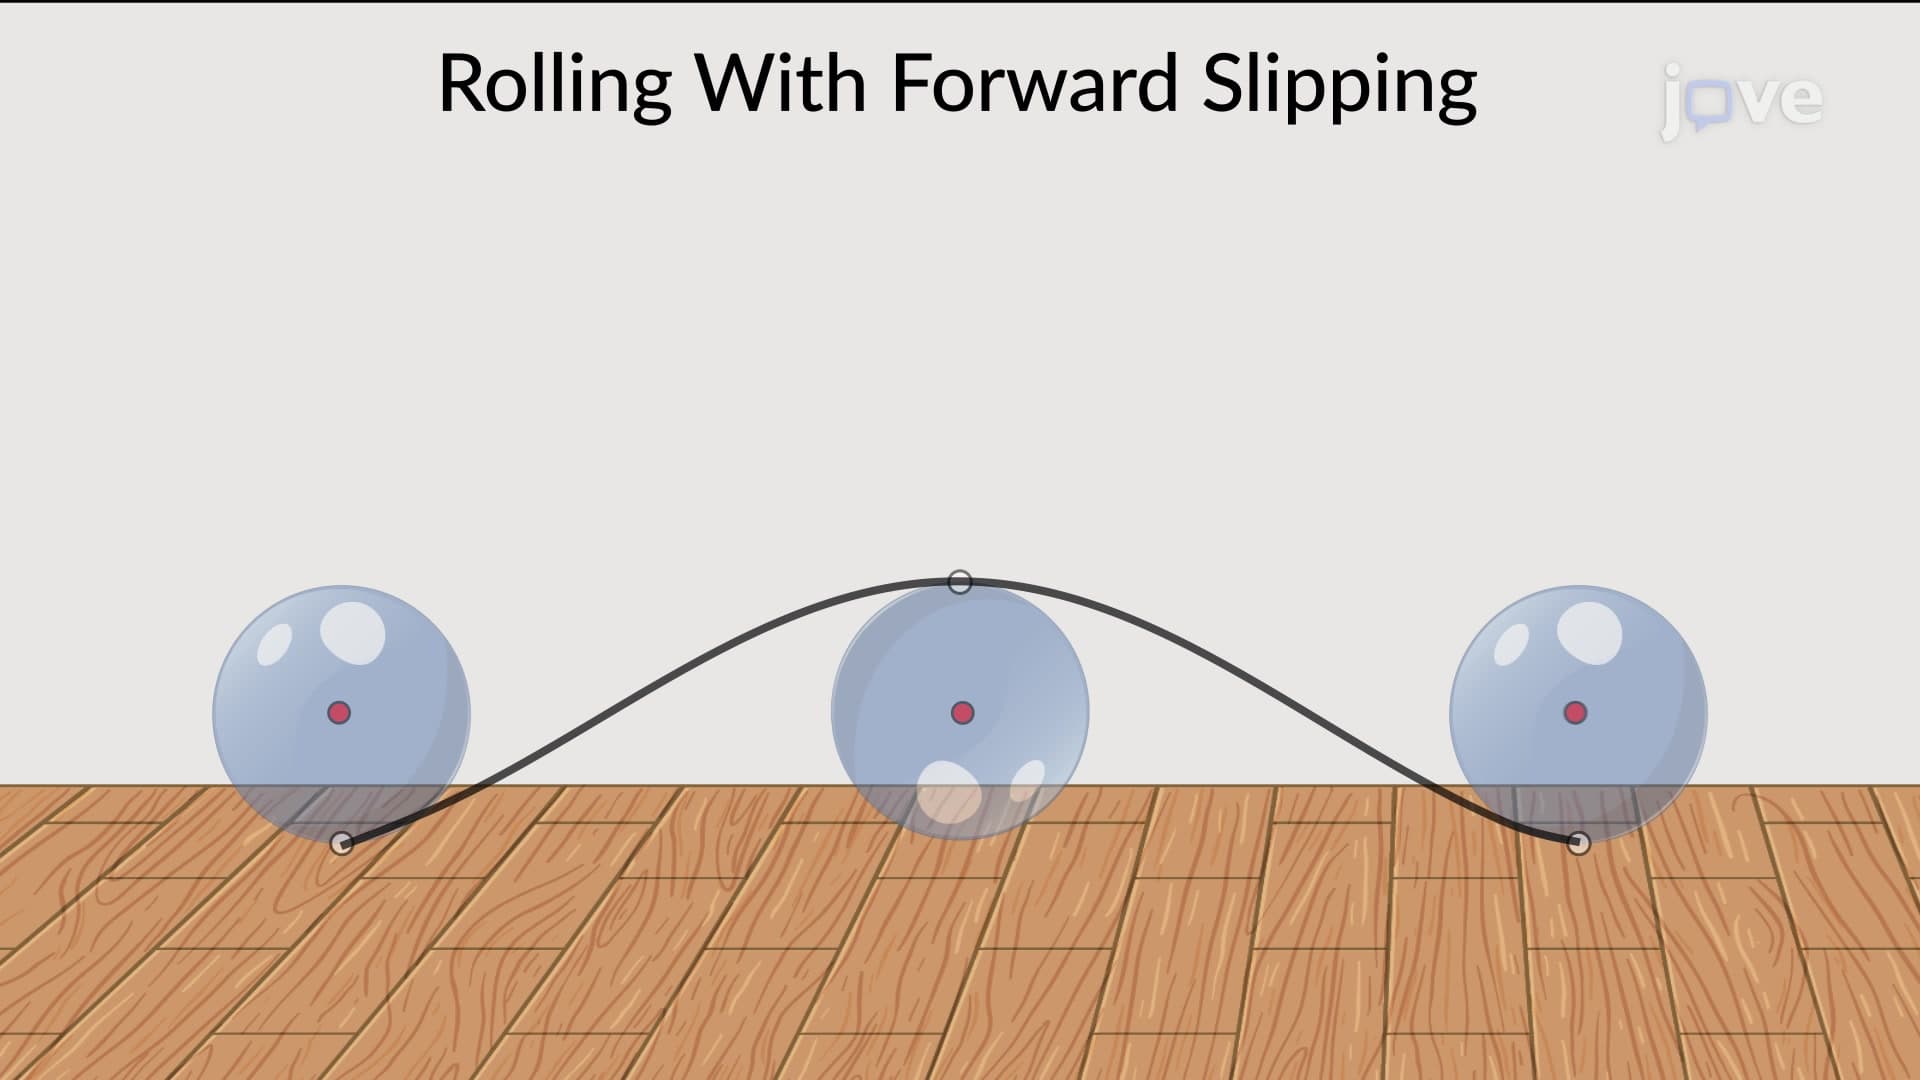
Rolling With Slipping
An object's rolling motion is characterized by its rotation around its axis, while linear motion refers to the object's translational motion along a surface. Frictional forces can affect...