Related Experiment Video
Updated: Jun 27, 2026

Control of Cell Adhesion using Hydrogel Patterning Techniques for Applications in Traction Force Microscopy
Published on: January 29, 2022
Flux Tensor Constrained Geodesic Active Contours with Sensor Fusion for Persistent Object Tracking
Filiz Bunyak1, Kannappan Palaniappan, Sumit Kumar Nath
1Department of Computer Science, University of Missouri-Columbia, MO 65211-2060, USA, Email: {bunyak,palaniappank}@missouri.edu , naths@ecse.rpi.edu.

Abstract:
This paper makes new contributions in motion detection, object segmentation and trajectory estimation to create a successful object tracking system. A new efficient motion detection algorithm referred to as the flux tensor is used to detect moving objects in infrared video without requiring background modeling or contour extraction. The flux tensor-based motion detector when applied to infrared video is more accurate than thresholding "hot-spots", and is insensitive to shadows as well as illumination changes in the visible channel. In real world monitoring tasks fusing scene information from multiple sensors and sources is a useful core mechanism to deal with complex scenes, lighting conditions and environmental variables. The object segmentation algorithm uses level set-based geodesic active contour evolution that incorporates the fusion of visible color and infrared edge informations in a novel manner. Touching or overlapping objects are further refined during the segmentation process using an appropriate shape-based model. Multiple object tracking using correspondence graphs is extended to handle groups of objects and occlusion events by Kalman filter-based cluster trajectory analysis and watershed segmentation. The proposed object tracking algorithm was successfully tested on several difficult outdoor multispectral videos from stationary sensors and is not confounded by shadows or illumination variations.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:26
Orthogonal Trajectories
 01:30
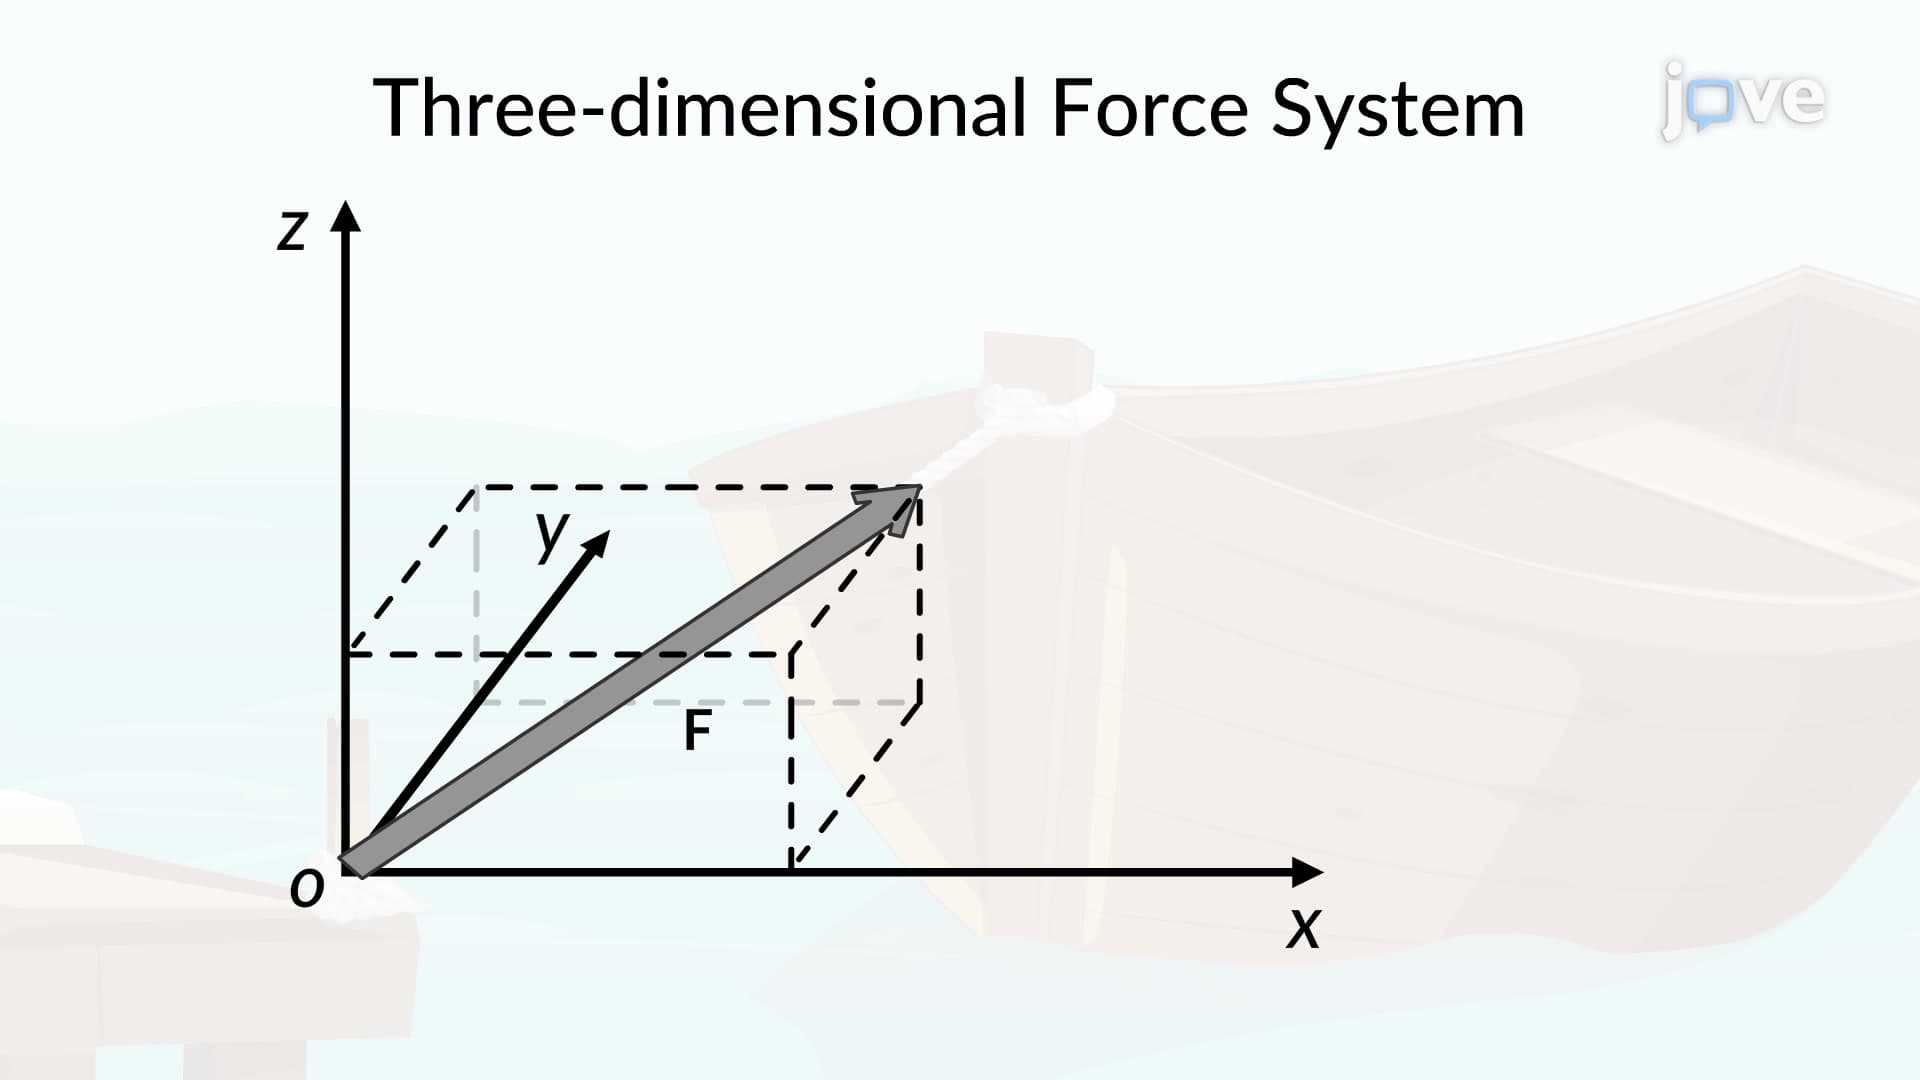
Three-Dimensional Force System
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:27
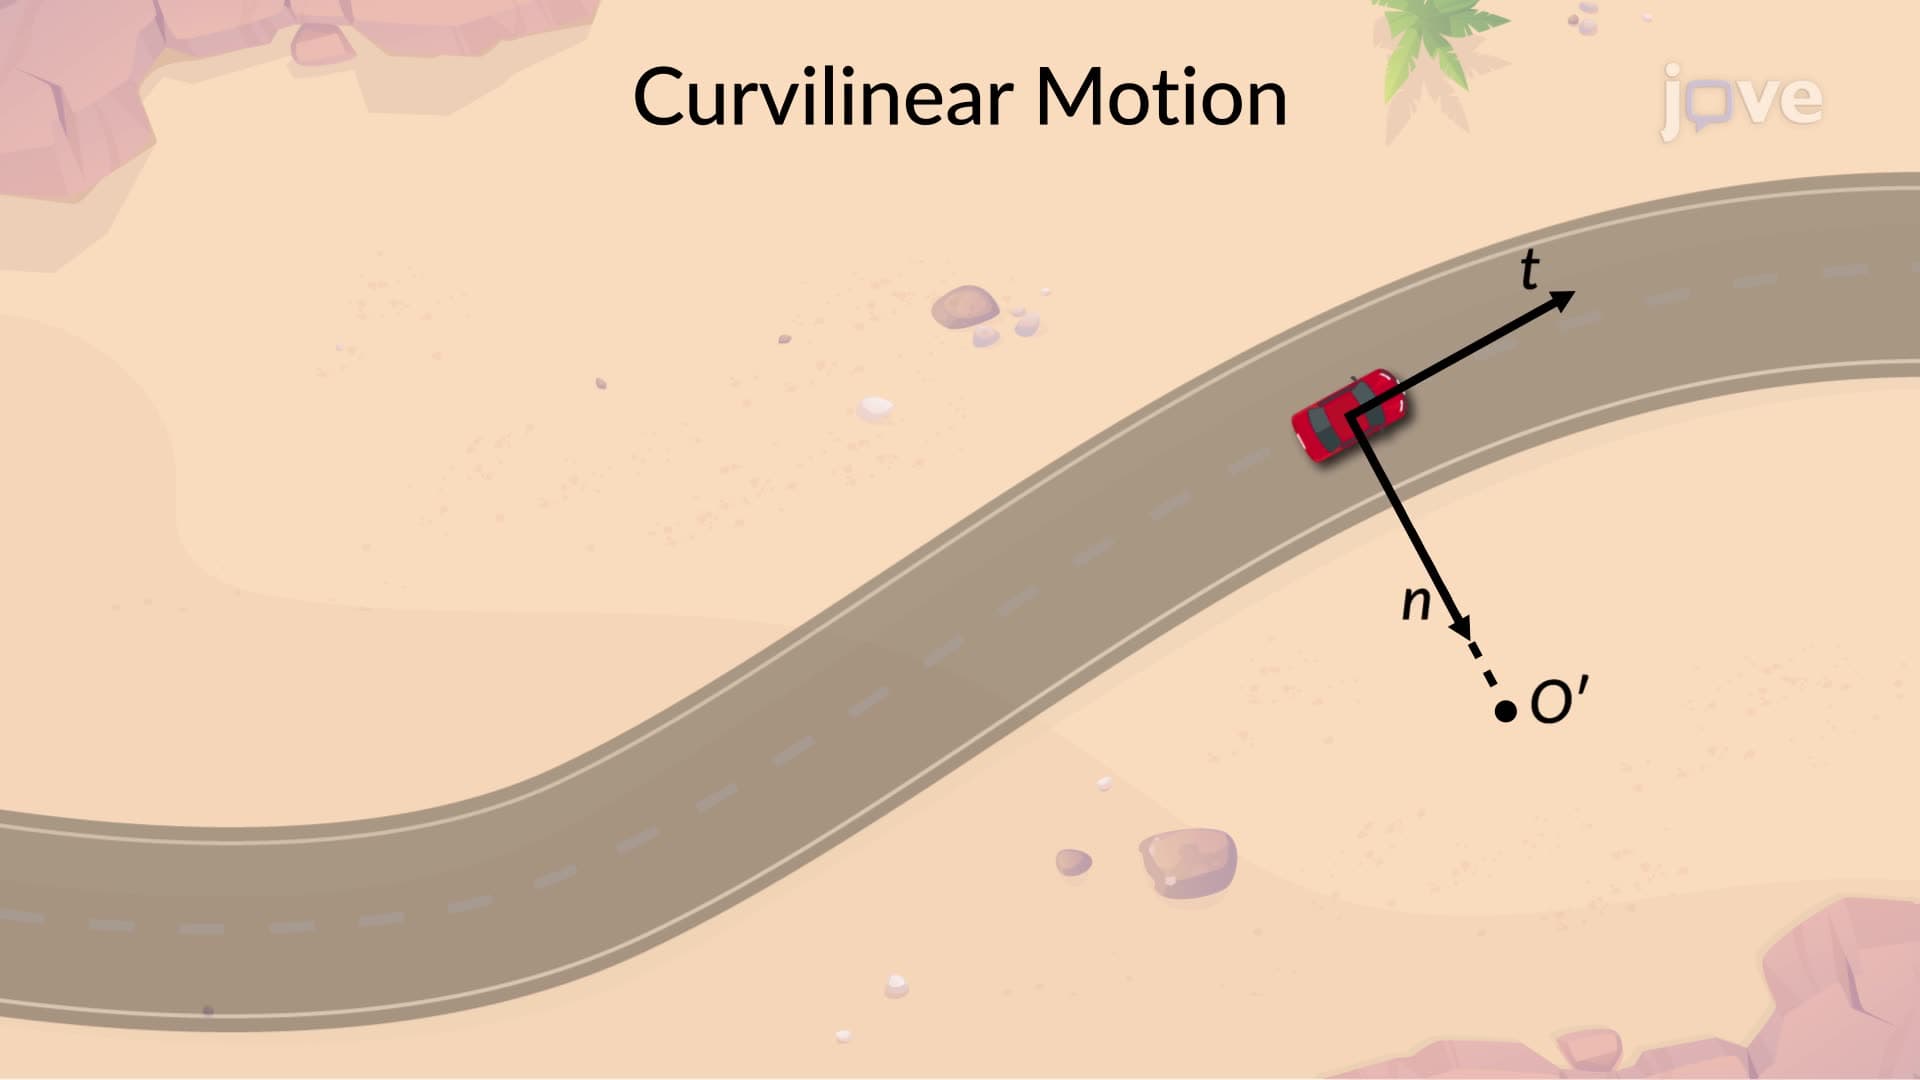
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...