Related Experiment Video
Updated: Jun 26, 2026
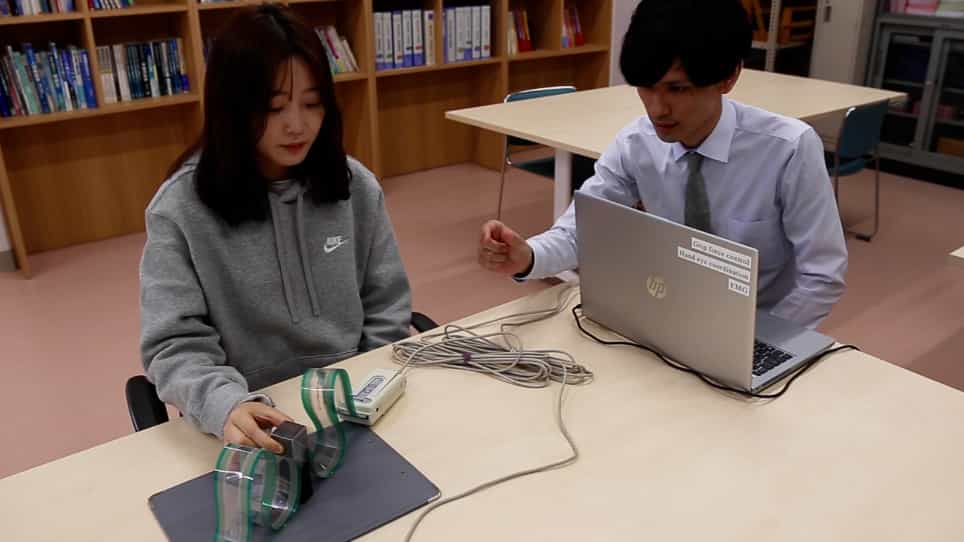

Measurement of Spatial Stability in Precision Grip
Published on: June 4, 2020
Investigation of grip force, normal force, contact area, hand size, and handle size for cylindrical handles
Na Jin Seo1, Thomas J Armstrong
1Department of Industrial and Operations Engineering, University of Michigan, Ann Arbor, MI 48109, USA. najins@umich.edu

Objective:
To investigate relationships among grip forces, normal forces, contact area for cylindrical handles, handle diameter, hand size, and volar hand area.
Background:
Data describing those relationships are needed to predict thrust forces and torque capability.
Method:
Additional analyses were performed retrospectively on data collected in two previous studies in which participants performed maximum grip exertions on cylinders (diameter 38-83 mm) while grip force, normal force, and contact area were recorded. The length, width, and volar area of the hand were measured.
Results:
Average total normal force on cylinders was 2.3 times greater than grip force measured using a split cylinder (R2 = 65%), regardless of the handle diameter examined. The ratio of handle diameter to hand length explained 62%, 57%, and 71% of the variances in grip force, normal force, and contact area, respectively. Estimated hand area (hand length x width) had a linear relationship with measured hand area (using photographs; R2 = 91%), although it was 8% less than the measured area.
Conclusion:
This work describes the relationship between normal force and grip force independent of handle size (for handle diameters from 38 to 83 mm). Normal force and contact area can be explained by the interaction between handle size and hand size. Hand area can be estimated by hand length times width.
Application:
The quantitative relationships described in this paper can be used in the design of objects and hand tools to determine optimal handle sizes for maximizing grip force, total normal force, or contact area.


Related Concept Videos
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:17
Rolling Resistance: Problem Solving
 01:29
Two-Dimensional Force System: Problem Solving
The first step to solving a two-dimensional force system problem is to draw a free-body diagram of the object under consideration. This diagram helps identify all the external forces acting on the object, including their...
 01:24
Bearings: Problem Solving
 01:21
Screw: Problem Solving
To evaluate the...
 01:13
Angle of Twist: Problem Solving