Related Experiment Video
Updated: Jun 26, 2026
Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
The dynamic balance of the children with cerebral palsy and typical developing during gait. Part I: Spatial
Bih-Jen Hsue1, Freeman Miller, Fong-Chin Su
1Institute of Biomedical Engineering, National Cheng Kung University, Tainan, Taiwan.

Abstract:
Analysis of the COM or COP movement has been a simplified method to illustrate the balance disorders in static stance and gait, but has its limitation when examined alone. Dynamic stability of 32 children with cerebral palsy (CP) was examined and compared with 10 typically developing (TD) children by measuring the displacement of center of mass (COM) and center of pressure (COP) and their spatial relationship. The children with CP were further divided into two groups based on topographical involvement, hemiplegia (Hemi) and diplegia (Di). The participants walked with their preferred speed at least 5 successful trials on a walkway with two force plates mounted in the middle. An eight-camera motion analysis was used to capture 26 reflective markers secured at the bony landmarks of the participant. The data obtained from motion analysis and force plates was used to calculate COM and COP. The results showed either of two CP groups demonstrated significantly greater peak-to-peak COM and COP displacement in medio-lateral (ML) and lower peak-to-peak COM and COP displacement in anterio-posterior (AP) direction than TD group. The root mean square (RMS) of COM-COP divergence of Hemi and Di groups were higher than that of TD group in AP and ML direction, but only the difference in ML direction was significant. Present study demonstrates that COM-COP divergence can characterize the dynamic balance of the CP children in walking, and thus assist in comparing and differentiating balance patterns.
Related Concept Videos
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:15
Kinematic Equations: Problem Solving
 01:28
Major Somatic Sensory Pathways
 01:26
Orthogonal Trajectories
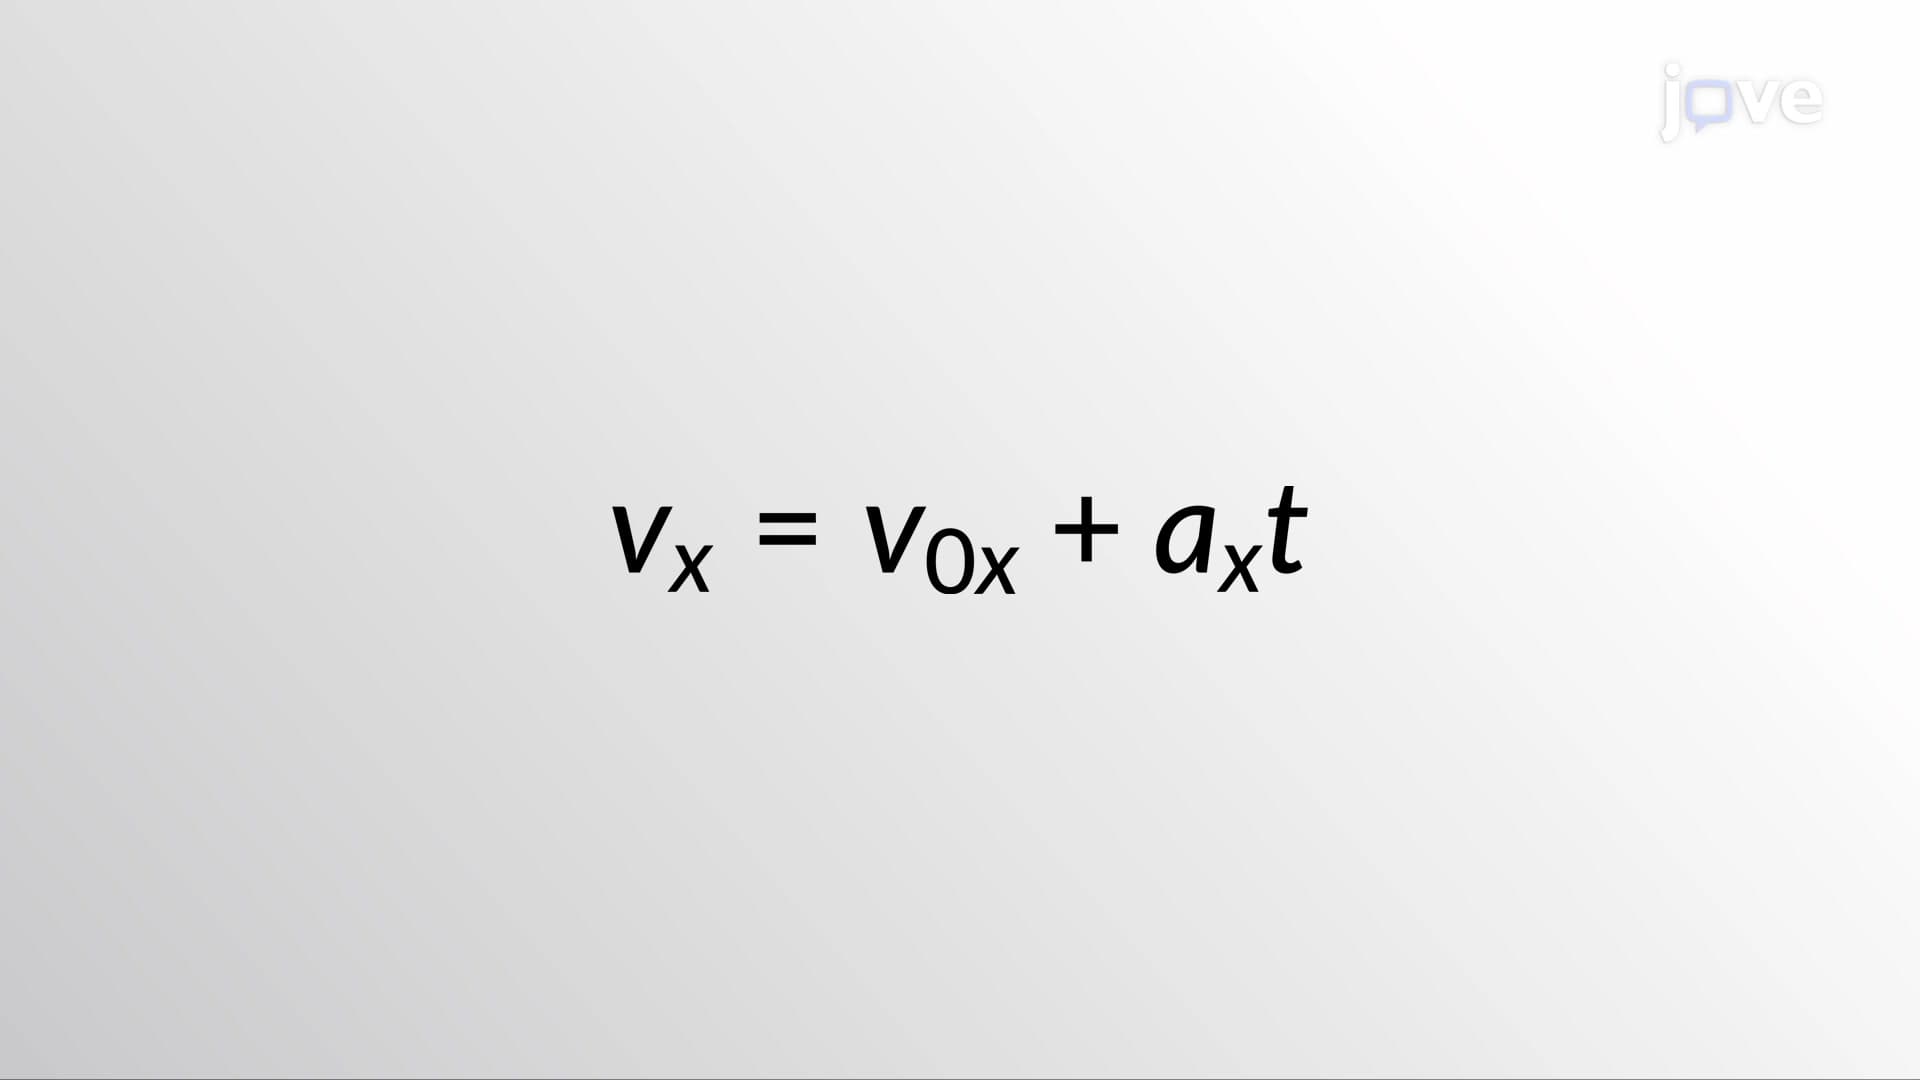 01:26
Kinematic Equations - I