Related Experiment Video
Updated: Jun 26, 2026
A Method for 3D Reconstruction and Virtual Reality Analysis of Glial and Neuronal Cells
Published on: September 28, 2019
A new algorithm for 3D reconstruction from support functions
Richard J Gardner1, Markus Kiderlen
1Western Washington University, Bellingham, WA 98225-9063, USA. Richard.Gardner@wwu.edu

Abstract:
We introduce a new algorithm for reconstructing an unknown shape from a finite number of noisy measurements of its support function. The algorithm, based on a least squares procedure, is very easy to program in standard software such as Matlab, and it works for both 2D and 3D reconstructions (in fact, in principle, in any dimension). Reconstructions may be obtained without any pre- or post-processing steps and with no restriction on the sets of measurement directions except their number, a limitation dictated only by computing time. An algorithm due to Prince and Willsky was implemented earlier for 2D reconstructions, and we compare the performance of their algorithm and ours. But our algorithm is the first that works for 3D reconstructions with the freedom stated in the previous paragraph. Moreover, under mild conditions, theory guarantees that outputs of the new algorithm will converge to the input shape as the number of measurements increases. In addition we offer a linear program version of the new algorithm that is much faster and better, or at least comparable, in performance at low levels of noise and reasonably small numbers of measurements. Another modification of the algorithm, suitable for use in a "focus of attention" scheme, is also described.
Related Concept Videos
 01:20
Divergence Theorem in 3D Space
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:29
Three-Dimensional Analysis of Strain
 01:28
Cylinders in Three-Dimensional Space
 01:30
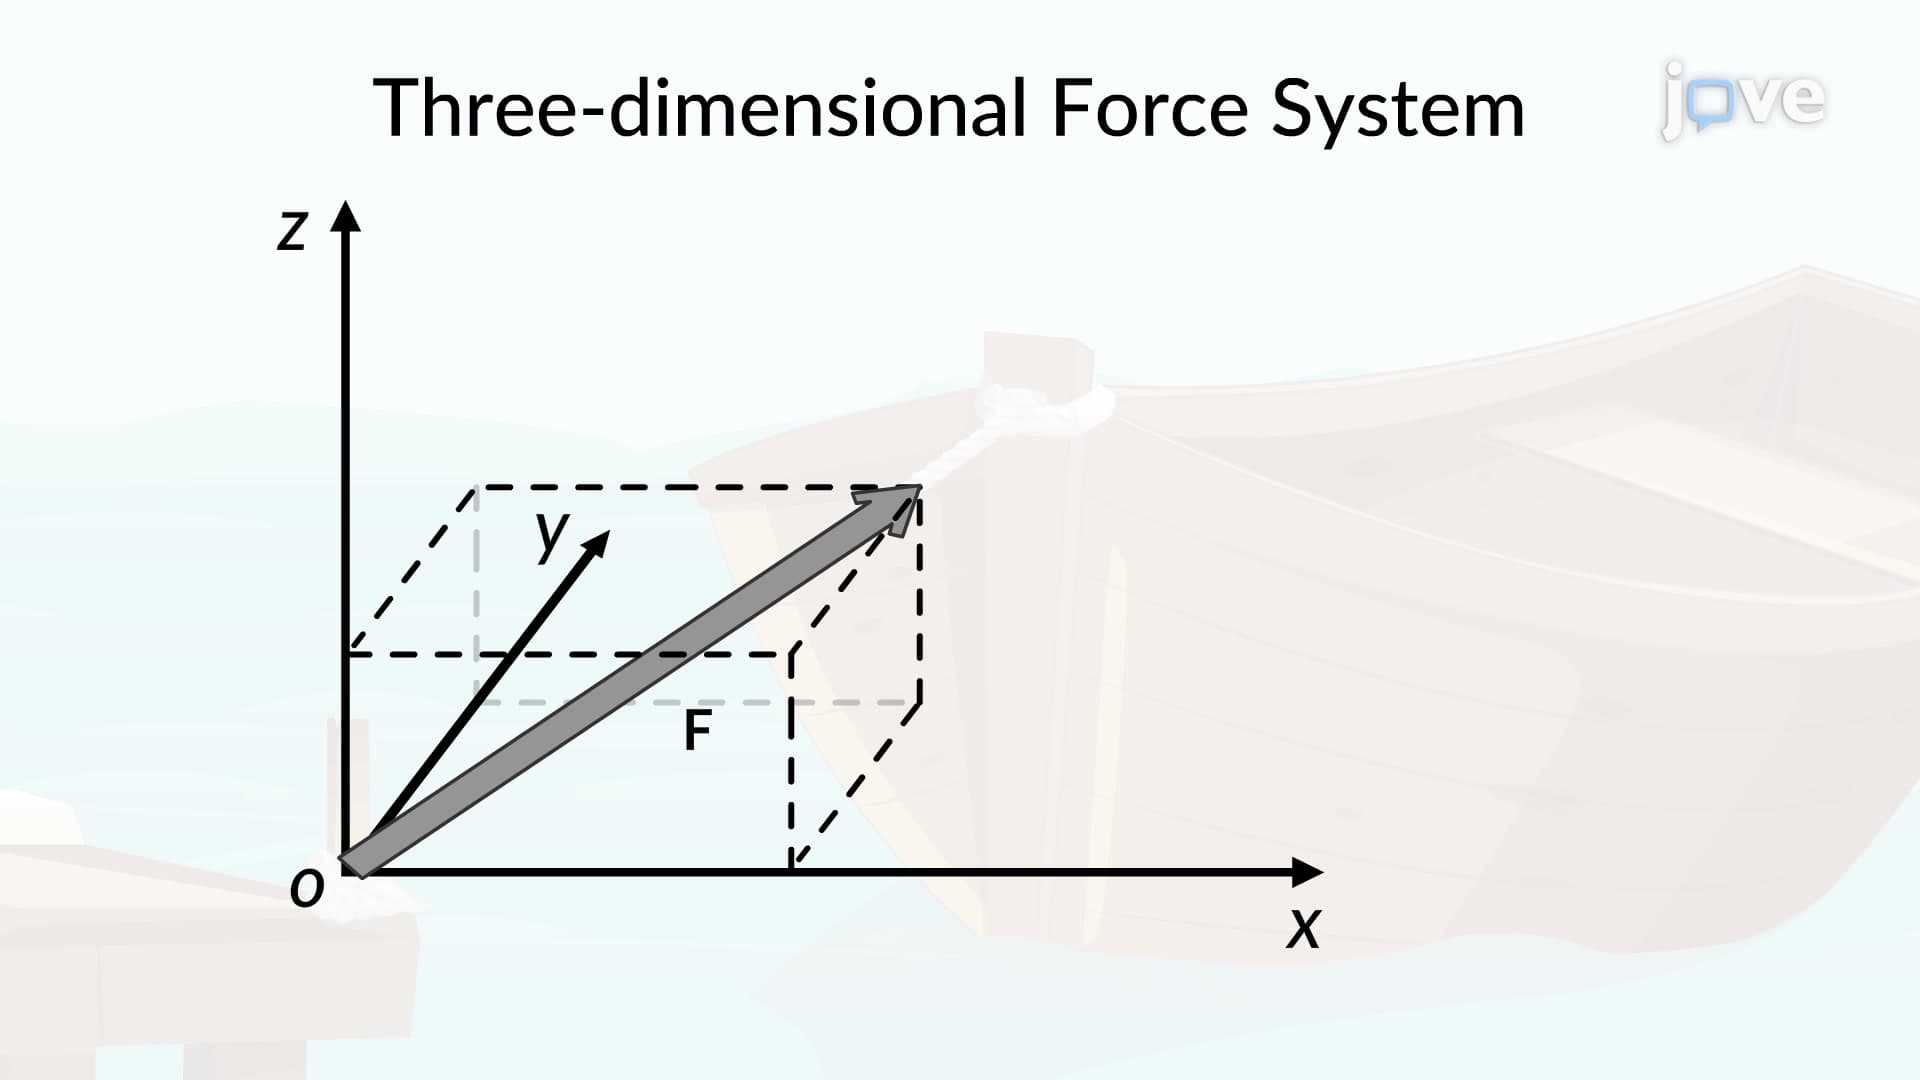
Three-Dimensional Force System
 01:27
Support Reactions in Three Dimensions
Ball and Socket Joint is one of the supports allowing free rotation about any axis. This freedom of rotation is...