Related Experiment Video
Updated: Jun 26, 2026

Force and Position Control in Humans - The Role of Augmented Feedback
Published on: June 19, 2016
Control of fracture reduction robot using force/torque measurement
1The University of Tokyo, Japan.

Abstract:
We have developed a surgical robotic system for femoral fracture reduction employing indirect traction. Indirect traction in fracture reduction is a generally used surgical method for preventing complications such as bone splits caused by high stress on bones. For traction, a patient's foot is gripped by a jig and pulled to the distal side. Indirect traction has the advantage of distributing bone stress by utilizing a strong traction force; however, this procedure does not accurately control the proper positioning of fractured fragments when a surgical robot is used. The human leg has knee and an ankle joints, and thus robotic motion presents problems in not being able to directly propagate reduction motion to a fractured femoral fragment, rendering control of bone position difficult. We propose a control method for fracture reduction robots using external force/torque measurements of the human leg to achieve precise fracture reduction. Results showed that the proposed method reduced repositioning error from 6.8 mm and 15.9 degrees to 0.7 mm and 5.3 degrees, respectively.
Related Concept Videos
 01:15
Torque Free Motion
 01:10
Torque
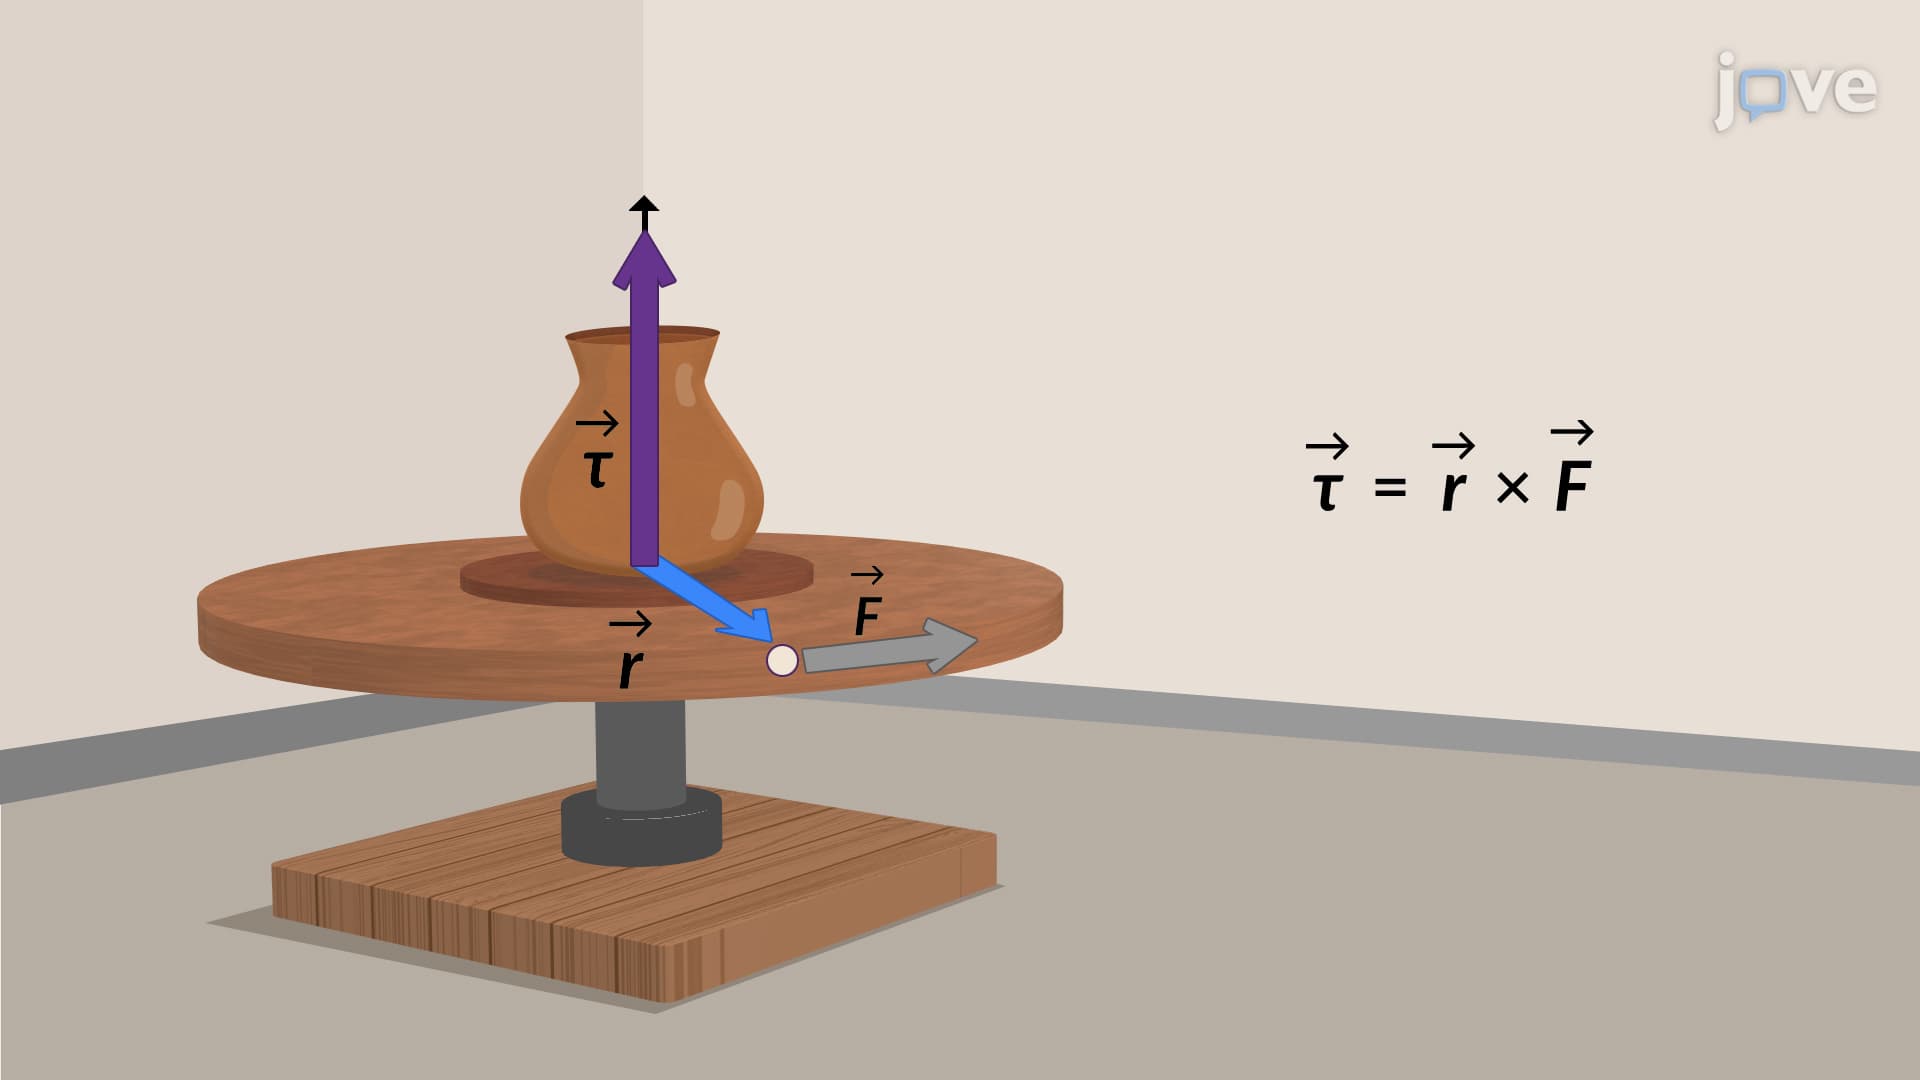
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
 01:19
Net Torque Calculations
 01:23
Simplification of a Force and Couple System: II
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
 01:30
Three-Dimensional Force System