Related Experiment Video
Updated: Jun 26, 2026
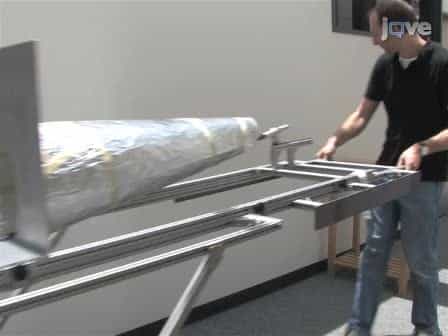

Adaptation of a Haptic Robot in a 3T fMRI
Published on: October 4, 2011
A hybrid ultrasonic motor and electrorheological fluid clutch actuator for force-feedback in MRI/fMRI
Dominique Chapuis1, Roger Gassert, Etienne Burdet
1Laboratoire de Systémes Robotiques, Ecole Polytechnique Fédérale de Lausanne, Switzerland. dominique.chapuis@epfl.ch

Abstract:
This paper presents a safe, electrically powered MR-compatible actuator with a large range of output impedance, which can be used at the entry of the scanner bore. This actuator is composed of an ultrasonic motor (USM) and a torque-controlled electrorheological fluid clutch which modulates the output torque of the USM. This paper describes the developments on the electrorheological fluid (ERF) clutch and its high voltage driver. The performances of the ERF brake constituting the clutch are evaluated, and its torque range is adapted using an epicyclic differential. The transmissible torque of the ERF clutch, i.e., the maximum system output torque, is 94.4 mNm and its drag torque is 2.6 mNm. The MR compatibility of the complete hybrid actuator is shown in extensive tests including subtraction of images and comparison of signal-to-noise ratios in powered and unpowered conditions. This novel MR-compatible actuator may be used to study the neural control of the hand.
More Related Videos
 07:34
Functional MRI in Conjunction with a Novel MRI-compatible Hand-induced Robotic Device to Evaluate Rehabilitation of Individuals Recovering from Hand Grip Deficits
Published on: November 23, 2019
 08:55
Use of a Foot-Induced Digitally Controlled Resistance Device for Functional Magnetic Resonance Imaging Evaluation in Patients with Foot Paresis
Published on: July 7, 2023
Related Concept Videos
 01:24
Magnetic Resonance Imaging
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...