Related Experiment Video
Updated: Jun 26, 2026
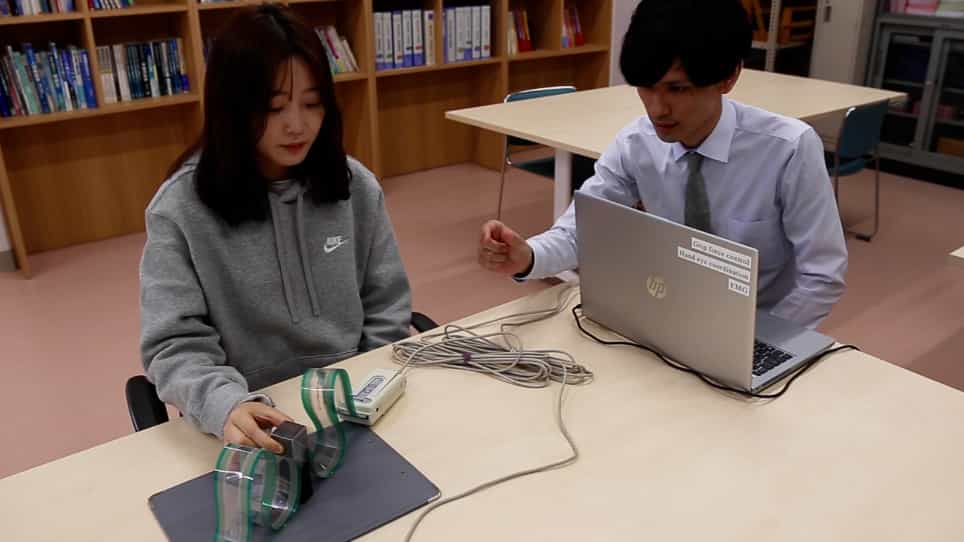

Measurement of Spatial Stability in Precision Grip
Published on: June 4, 2020
Exploring the human grip force system: a preliminary study
Alejandro Villasenor-Herrera1, Sophie J De Serres, Ross Wagner
1Department of Biomedical Engineering, McGill University, Montreal, QC H3A2B4, Canada. alejandro.villasenor-herrera@mail.mcgill.ca

Abstract:
It has been postulated that cutaneo-receptors from the digits contribute to the control of manipulatory functions of the hand. However, few studies have examined the dynamics of the human grip force system (HGFS) in terms of the dynamic relationship between the vertical loads, taken as an input and the resulting grip force, taken as the output. This paper describes the experimental procedures we have developed to explore the HGFS and presents some initial experimental results. These demonstrate that the step response of the HGFS is biphasic. The first, short latency phase, likely involves only passive and intrinsic components. The second, longer latency phase is likely related to reflex mechanisms since it is preceded by a strong burst of EMG. Moreover, the HGFS response depended nonlinearly on the amplitude and direction of the load applied. These results indicate that further investigation of HGFS dynamics will require the use of nonlinear identification methods.

Related Concept Videos
 01:05
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:22
Force Classification
Contact and non-contact forces are two of the most widely used categories of forces. As the name suggests, contact forces require physical contact between two objects to act upon each other. Examples of contact forces include frictional,...
 01:30
Three-Dimensional Force System
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 01:23
Simplification of a Force and Couple System: II
 01:30
Machines: Problem Solving II