Related Experiment Video
Updated: Jun 26, 2026

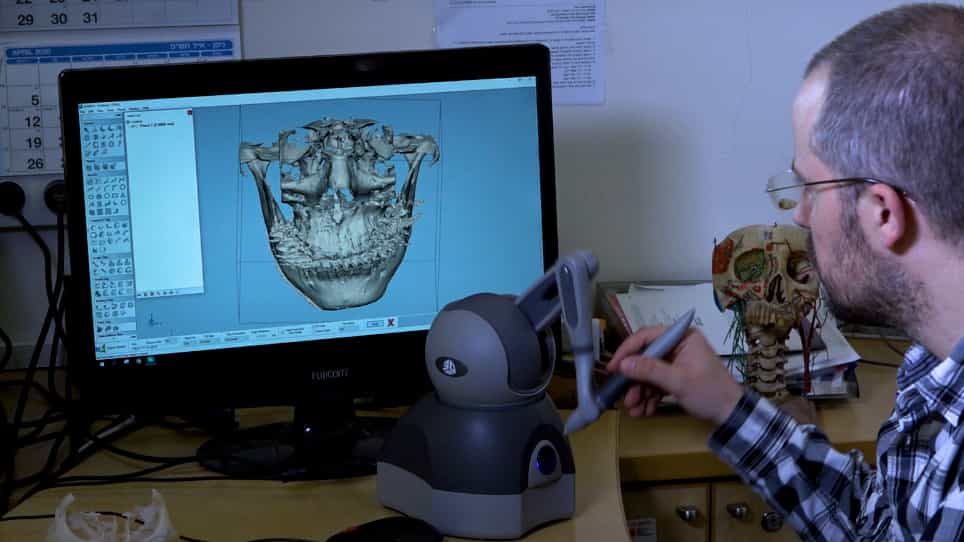
Three-Dimensional Preoperative Virtual Planning in Derotational Proximal Femoral Osteotomy
Published on: February 17, 2023
First 3D ultrasound scanning, planning, and execution of CT-free milling interventions with a surgical robot
Philipp J Stolka1, Dominik Henrich, Steffen H Tretbar
1Lehrstuhl für Angewandte Informatik III (Robotik und Eingebettete Systeme), Universität Bayreuth, D-95440, Germany. philipp.stolka@uni-bayreuth.de

Abstract:
Surgical procedures with navigation or robot system support usually require pre-operative planning data. This data can be acquired with imaging techniques such as computed tomography (CT), the current gold standard due to its high precision. With such planning data, access trajectories, implant positions, individual milling paths etc. can be computed. We present a novel ultrasound-based method to generate equivalent 3D image data which is well-suited for many interventions, but less costly than the CT-based method. The method is demonstrated for robot-based implant bed milling in the lateral skull base, in a complete process consisting of infrared navigation registration, manual ultrasound scan path delineation, path smoothing and checking, robot-based ultrasound scan execution, 3D ultrasound volume reconstruction, implant position optimization, robot milling path planning, and intervention execution. This represents, to the best of our knowledge, the first time such a CT-free, 3D-ultrasound-based intervention has been demonstrated in the laboratory.