Feasibility of iterative learning control mediated by functional electrical stimulation for reaching after stroke
Related Experiment Video
Updated: Jun 25, 2026
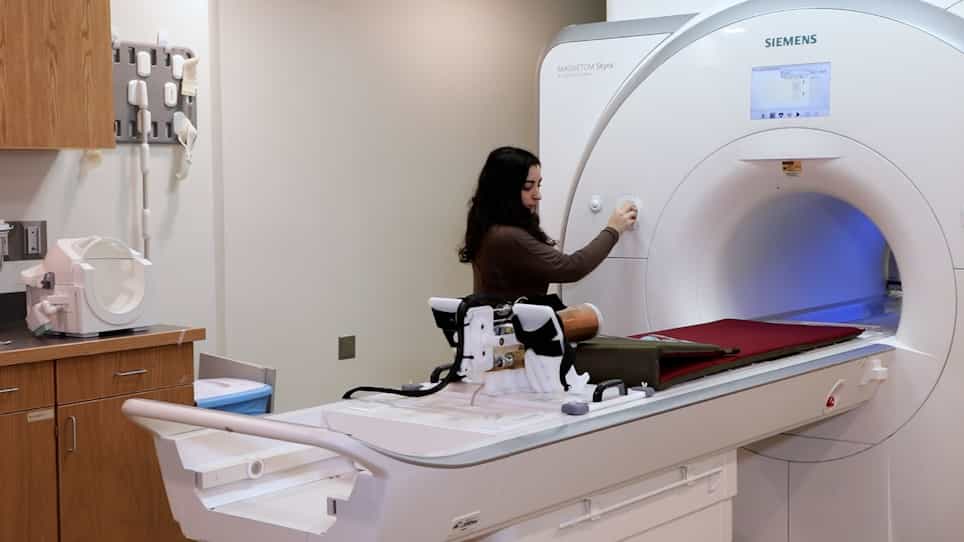
Use of a Foot-Induced Digitally Controlled Resistance Device for Functional Magnetic Resonance Imaging Evaluation in Patients with Foot Paresis
Published on: July 7, 2023
A M Hughes1, C T Freeman, J H Burridge
1School of Health Sciences, University of Southampton, Southampton, United Kingdom. ah10@soton.ac.uk

Background:
An inability to perform tasks involving reaching is a common problem following stroke. Evidence supports the use of robotic therapy and functional electrical stimulation (FES) to reduce upper limb impairments, but current systems may not encourage maximal voluntary contribution from the participant because assistance is not responsive to performance.
Objective:
This study aimed to investigate whether iterative learning control (ILC) mediated by FES is a feasible intervention in upper limb stroke rehabilitation.
Methods:
Five hemiparetic participants with reduced upper limb function who were at least 6 months poststroke were recruited from the community. No participants withdrew.
Intervention:
Participants undertook supported tracking tasks using 27 different trajectories augmented by responsive FES to their triceps brachii muscle, with their hand movement constrained in a 2-dimensional plane by a robot. Eighteen 1-hour treatment sessions were used with 2 participants receiving an additional 7 treatment sessions.
Outcome Measures:
The primary functional outcome measure was the Action Research Arm Test (ARAT). Impairment measures included the upper limb Fugl-Meyer Assessment (FMA), tests of motor control (tracking accuracy), and isometric force.
Results:
Compliance was excellent and there were no adverse events. Statistically significant improvements were measured (P
Conclusion:
This study has demonstrated the feasibility of using ILC mediated by FES for upper limb stroke rehabilitation.
