Spatial disorientation in gondola centrifuges predicted by the form of motion as a whole in 3-D
Related Experiment Video
Updated: Jun 25, 2026
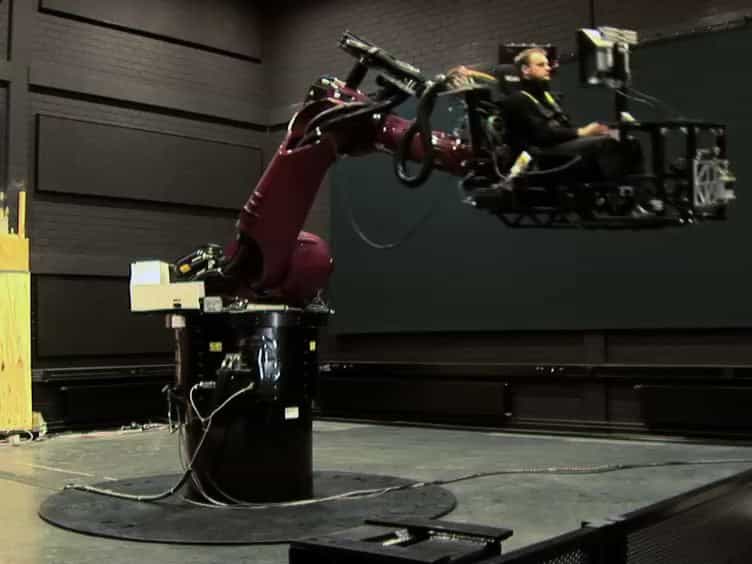
MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
Jan E Holly1, Katharine J Harmon
1Department of Mathematics, Colby College, 5845 Mayflower Hill, Waterville, ME 04901, USA. jeholly@colby.edu

Introduction:
During a coordinated turn, subjects can misperceive tilts. Subjects accelerating in tilting-gondola centrifuges without external visual reference underestimate the roll angle, and underestimate more when backward-facing than when forward-facing. In addition, during centrifuge deceleration, the perception of pitch can include tumble while paradoxically maintaining a fixed perceived pitch angle. The goal of the present research was to test two competing hypotheses: 1) that components of motion are perceived relatively independently and then combined to form a three-dimensional (3-D) perception; and 2) that perception is governed by familiarity of motions as a whole in three dimensions, with components depending more strongly on the overall shape of the motion.
Methods:
Published experimental data from existing tilting-gondola centrifuge studies were used. The two hypotheses were implemented formally in computer models, and centrifuge acceleration and deceleration were simulated.
Results:
The second, whole-motion oriented hypothesis better predicted subjects' perceptions, including the forward-backward asymmetry and the paradoxical tumble upon deceleration. The predominant stimulus at the beginning of the motion and the familiarity of centripetal acceleration were important factors.
Conclusion:
Three-dimensional perception is better predicted by taking into account familiarity with the form of 3-D motion.
More Related Videos
Related Concept Videos
 01:20
Instantaneous Center of Zero Velocity
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...
 01:02
Gyroscope
 01:27
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:22
Non-uniform Circular Motion
For example, such accelerations...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:24
Gyroscope: Precession