Related Experiment Video
Updated: Jun 25, 2026
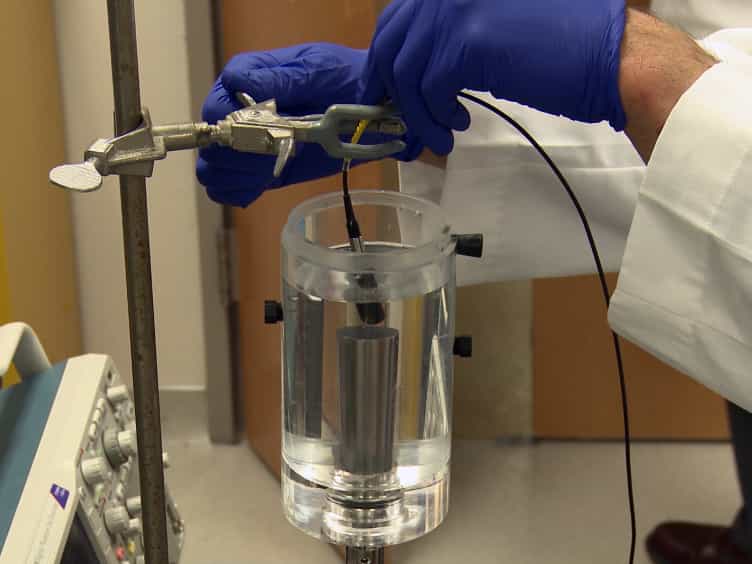
Generation and Quantitative Analysis of Pulsed Low Frequency Ultrasound to Determine the Sonic Sensitivity of Untreated and Treated Neoplastic Cells
Published on: July 22, 2015
Measuring derived acoustic power of an ultrasound surgical device in the linear and nonlinear operating modes
Antonio Petosić1, Bojan Ivancević, Dragoljub Svilar
1Department of Electroacoustics, Faculty of Electrical Engineering and Computing, Unska 3, 10000 Zagreb, Croatia. antonio.petosic@fer.hr

Objective And Motivation:
The method for measuring derived acoustic power of an ultrasound point source in the form of a sonotrode tip has been considered in the free acoustic field, according to the IEC 61847 standard. The main objective of this work is measuring averaged pressure magnitude spatial distribution of an sonotrode tip in the free acoustic field conditions at different electrical excitation levels and calculation of the derived acoustic power at excitation frequency (f0 approximately 25 kHz). Finding the derived acoustic power of an ultrasonic surgical device in the strong cavitation regime of working, even in the considered laboratory conditions (anechoic pool), will enable better understanding of the biological effects on the tissue produced during operation with the considered device.
Experimental Method:
The pressure magnitude spatial distribution is measured using B&K 8103 hydrophone connected with a B&K 2626 conditioning amplifier, digital storage oscilloscope LeCroy Waverunner 474, where pressure waveforms in the field points are recorded. Using MATLAB with DSP processing toolbox, averaged power spectrum density of recorded pressure signals in different field positions is calculated. The measured pressure magnitude spatial distributions are fitted with the appropriate theoretical models.
Theoretical Approaches:
In the linear operating mode, using the acoustic reciprocity principle, the sonotrode tip is theoretically described as radially oscillating sphere (ROS) and transversely oscillating sphere (TOS) in the vicinity of pressure release boundary. The measured pressure magnitude spatial distribution is fitted with theoretical curves, describing the pressure field of the considered theoretical models. The velocity and displacement magnitudes with derived acoustic power of equivalent theoretical sources are found, and the electroacoustic efficiency factor is calculated. When the transmitter is excited at higher electrical power levels, the displacement magnitude of sonotrode tip is increased, and nonlinear behaviour in loading medium appears, with strong cavitation activity produced hydrodynamically. The presence of harmonics, subharmonics and ultraharmonics as a consequence of stable cavitation is evident in the averaged power spectral density. The cavitation noise with continuous frequency components is present as a consequence of transient cavitation. The averaged pressure magnitude at the frequency components of interest (discrete and continuous) in the field points is found by calculating average power spectral density of the recorded pressure waveform signal using the welch method. The frequency band of interest where average power spectral density is calculated is in the range from 15 Hz up to 120 kHz due to measurement system restrictions. The novelty in the approach is the application of the acoustic reciprocity principle on the nonlinear system (sonotrode tip and bubble cloud) to find necessary acoustic power of the equivalent acoustic source to produce the measured pressure magnitude in the field points at the frequency components of interest.
Results:
In the nonlinear operating mode, the ROS model for the considered sonotrode tip is chosen due to the better agreement between measurement results and theoretical considerations. At higher excitation levels, it is shown that the averaged pressure magnitude spatial distribution of discrete frequency components, produced due to stable cavitation, can be fitted in the far field with the inverse distance law. The reduced electroacoustic efficiency factor, calculated at excitation frequency component as ratio of derived acoustic power with applied electrical power, is reduced from 40% in the linear to 3% in the strong nonlinear operating mode. The derived acoustic power at other frequency components (subharmonic, harmonic and ultraharmonic) is negligible in comparison with the derived acoustic power at excitation frequency.
Discussion And Conclusions:
The sonotrode tip and loading medium are shown in the strong cavitation regime as the coupled nonlinear dynamical system radiating acoustic power at frequency components appearing in the spectrum. The bubble cloud in the strong nonlinear operating mode decreases the derived acoustic power significantly at the excitation frequency.
More Related Videos
 08:38
Simultaneous Focused Ultrasound Neuromodulation and Fiber Photometry Recording in Free-Moving Mouse
Published on: September 6, 2024
 16:01
An Experimental Protocol for Assessing the Performance of New Ultrasound Probes Based on CMUT Technology in Application to Brain Imaging
Published on: September 24, 2017
Related Concept Videos
 01:25
Ultrasound II: Endoscopic Ultrasound and FibroScan
Endoscopic Ultrasound (EUS):
 01:17
Ultrasonography
During an ultrasonography procedure, a handheld device called a...