Related Experiment Video
Updated: Jun 25, 2026


A Structured Rehabilitation Protocol for Improved Multifunctional Prosthetic Control: A Case Study
Published on: November 6, 2015
Automated optimal coordination of multiple-DOF neuromuscular actions in feedforward neuroprostheses
J Luis Lujan1, Patrick E Crago
1Cleveland Clinic Foundation, Cleveland, OH 44195, USA. lujanl@ccf.org

Abstract:
This paper describes a new method for designing feedforward controllers for multiple-muscle, multiple-DOF, motor system neural prostheses. The design process is based on experimental measurement of the forward input/output properties of the neuromechanical system and numerical optimization of stimulation patterns to meet muscle coactivation criteria, thus resolving the muscle redundancy (i.e., overcontrol) and the coupled DOF problems inherent in neuromechanical systems. We designed feedforward controllers to control the isometric forces at the tip of the thumb in two directions during stimulation of three thumb muscles as a model system. We tested the method experimentally in ten able-bodied individuals and one patient with spinal cord injury. Good control of isometric force in both DOFs was observed, with rms errors less than 10% of the force range in seven experiments and statistically significant correlations between the actual and target forces in all ten experiments. Systematic bias and slope errors were observed in a few experiments, likely due to the neuromuscular fatigue. Overall, the tests demonstrated the ability of a general design approach to satisfy both control and coactivation criteria in multiple-muscle, multiple-axis neuromechanical systems, which is applicable to a wide range of neuromechanical systems and stimulation electrodes.
More Related Videos
 09:14
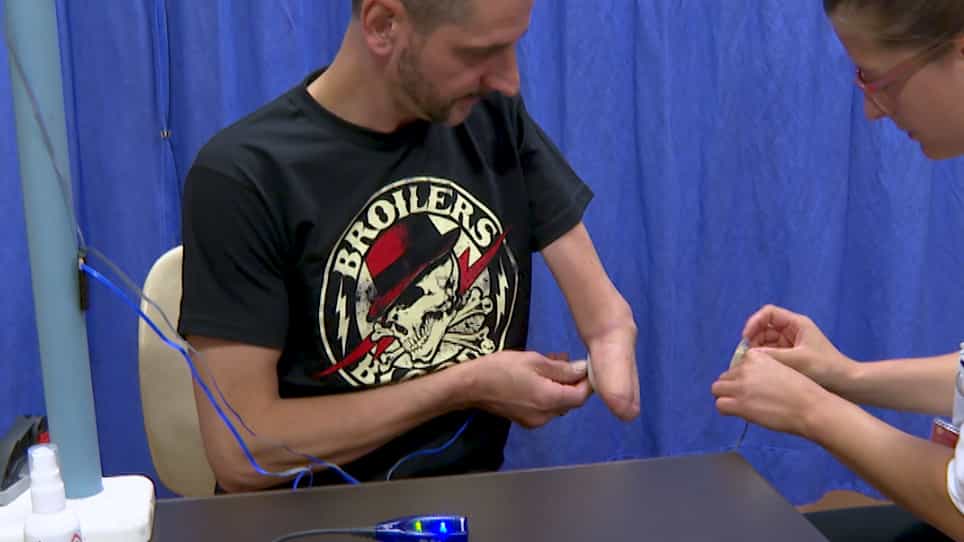
Surface Electromyographic Biofeedback as a Rehabilitation Tool for Patients with Global Brachial Plexus Injury Receiving Bionic Reconstruction
Published on: September 28, 2019
 11:16
Engineering Platform and Experimental Protocol for Design and Evaluation of a Neurally-controlled Powered Transfemoral Prosthesis
Published on: July 22, 2014
Related Concept Videos
 01:24
Muscle Coordination and Action
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement.
 01:18
Hierarchy of Motor Control
 01:20
Motor Unit Stimulation
The latent period of contraction marks the onset of excitation-contraction coupling, when the action potential propagates across the sarcolemma, preparing the muscle fibers for contraction. As the fibers enter the contraction phase, the...