Related Experiment Video
Updated: Jun 24, 2026
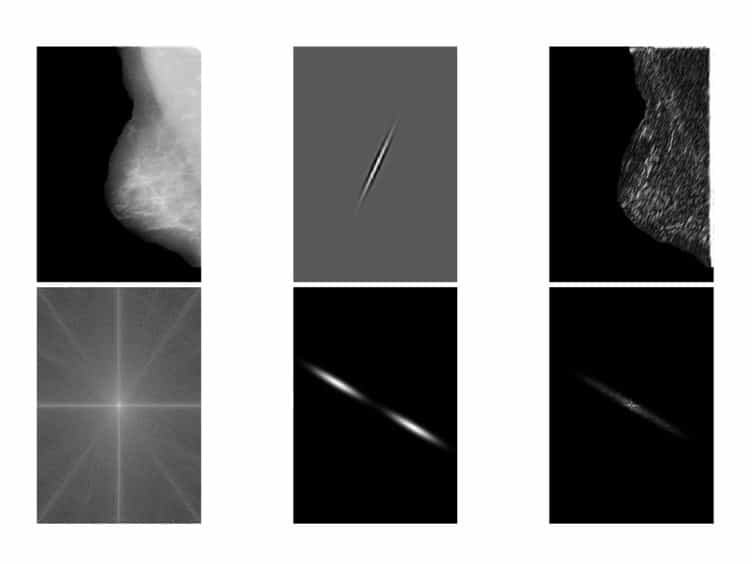
Detection of Architectural Distortion in Prior Mammograms via Analysis of Oriented Patterns
Published on: August 30, 2013
Low-rank matrix fitting based on subspace perturbation analysis with applications to structure from motion
Hongjun Jia1, Aleix M Martinez
1Department of Electrical and Computer Engineering, The Ohio State University, 205 Dreese Lab, 2015 Neil Ave.,Columbus, OH 43210, USA. jia.22@osu.edu

Abstract:
The task of finding a low-rank (r) matrix that best fits an original data matrix of higher rank is a recurring problem in science and engineering. The problem becomes especially difficult when the original data matrix has some missing entries and contains an unknown additive noise term in the remaining elements. The former problem can be solved by concatenating a set of r-column matrices that share a common single r-dimensional solution space. Unfortunately, the number of possible submatrices is generally very large and, hence, the results obtained with one set of r-column matrices will generally be different from that captured by a different set. Ideally, we would like to find that solution that is least affected by noise. This requires that we determine which of the r-column matrices (i.e., which of the original feature points) are less influenced by the unknown noise term. This paper presents a criterion to successfully carry out such a selection. Our key result is to formally prove that the more distinct the r vectors of the r-column matrices are, the less they are swayed by noise. This key result is then combined with the use of a noise model to derive an upper bound for the effect that noise and occlusions have on each of the r-column matrices. It is shown how this criterion can be effectively used to recover the noise-free matrix of rank r. Finally, we derive the affine and projective structure-from-motion (SFM) algorithms using the proposed criterion. Extensive validation on synthetic and real data sets shows the superiority of the proposed approach over the state of the art.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...