Related Experiment Video
Updated: Jun 24, 2026

Study Motor Skill Learning by Single-pellet Reaching Tasks in Mice
Published on: March 4, 2014
Learning to play the violin: motor control by freezing, not freeing degrees of freedom
Jürgen Konczak1, Heidi Vander Velden, Lukas Jaeger
1Human Sensorimotor Control Lab, School of Kinesiology, University of Minnesota, Minneapolis, MN, USA. jkonczak@umn.edu

Abstract:
Playing a violin requires precise patterns of limb coordination that are acquired over years of practice. In the present study, the authors investigated how motion at proximal arm joints influenced the precision of bow movements in novice learners and experts. The authors evaluated the performances of 11 children (4-12 years old), 3 beginning-to-advanced level adult players, and 2 adult concert violinists, using a musical work that all had mastered as their first violin piece. The authors found that learning to play the violin was not associated with a release or freeing of joint degrees of freedom. Instead, learning was characterized by an experience-dependent suppression of sagittal shoulder motion, as documented by an observed reduction in joint angular amplitude. This reduction in the amplitude of shoulder flexion-extension correlated highly with a decrease of bow-movement variability. The remaining mechanical degrees of freedom at the elbow and shoulder showed patterns of neither suppression nor freeing. Only violinists with more than 700 practice hr achieved sagittal shoulder range of motion comparable to experts. The findings imply that restricting joint amplitude at selected joint degrees of freedom, while leaving other degrees of freedom unconstrained, constitutes an appropriate strategy for learning complex, high-precision motor patterns in children and adults. The findings also highlight that mastering even seemingly simple bowing movements constitutes a prolonged learning process.
Related Concept Videos
 01:18
Hierarchy of Motor Control
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:15
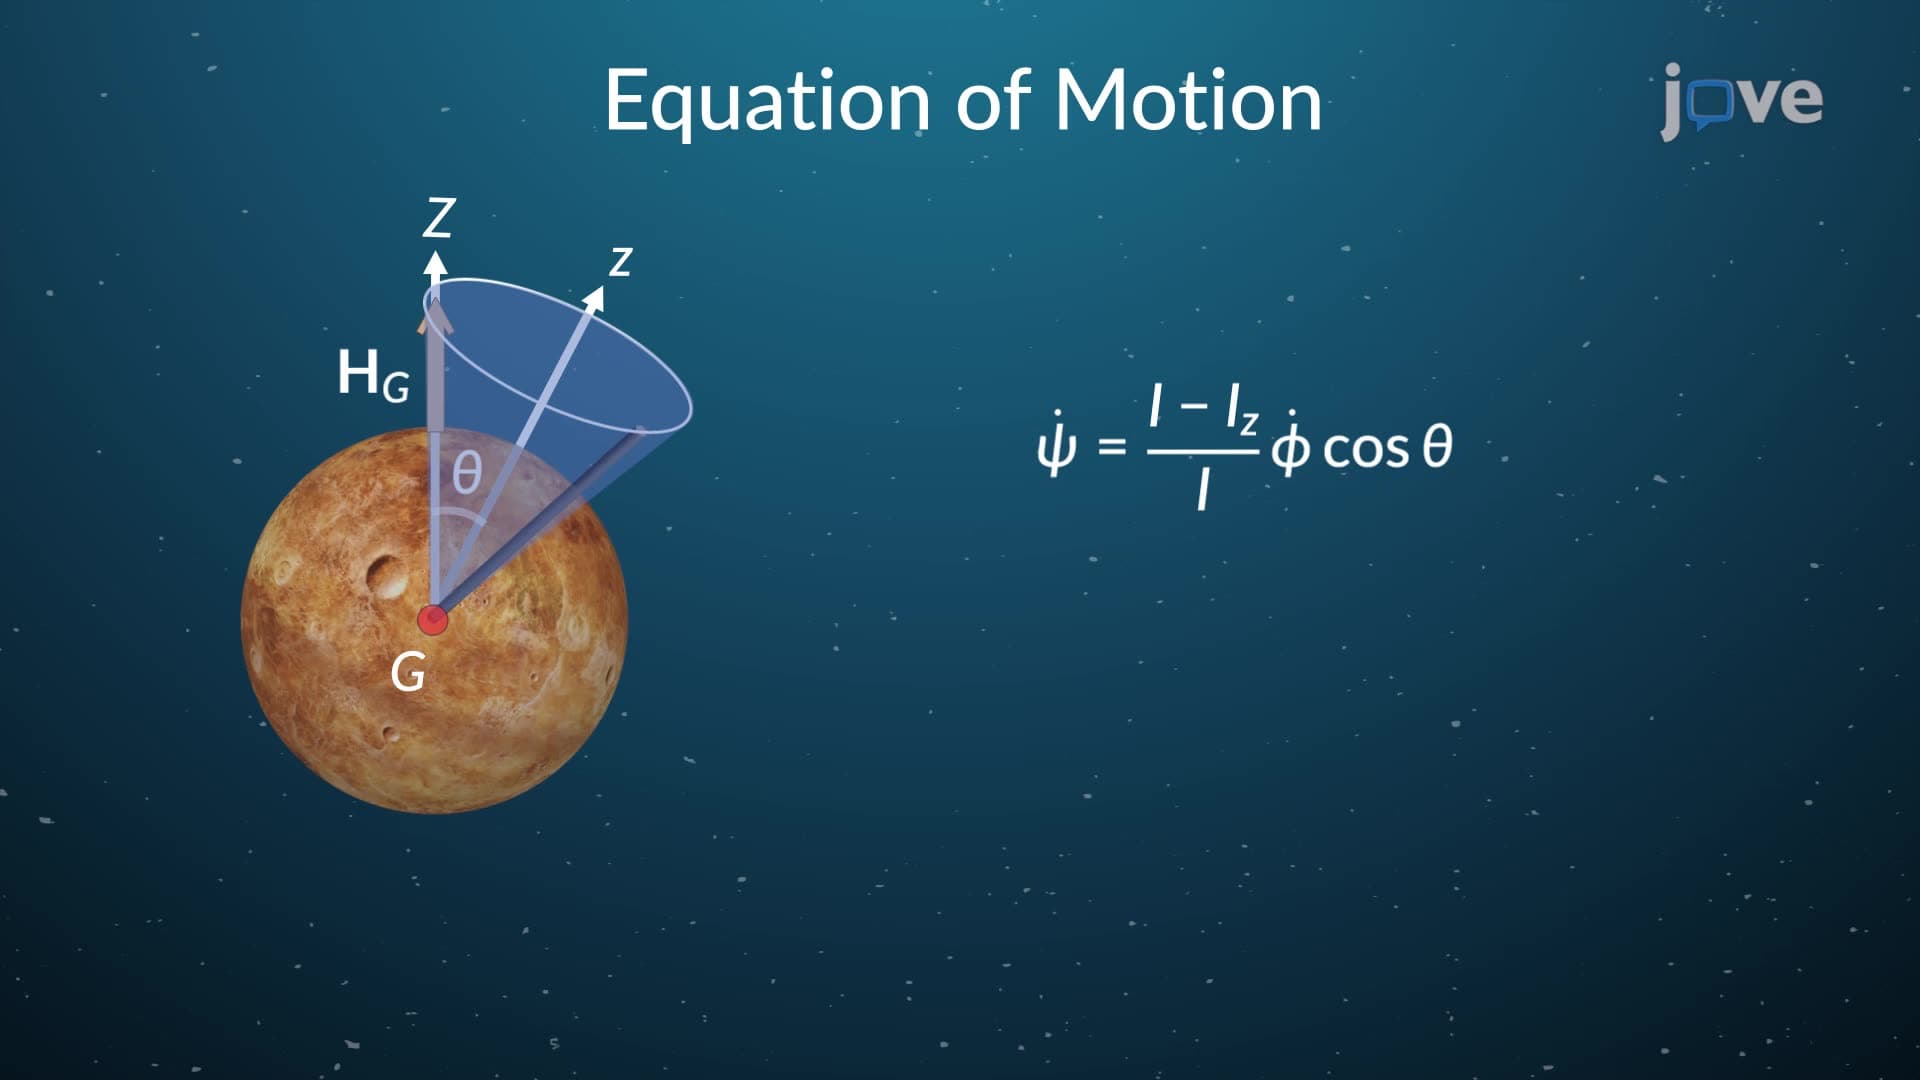
Torque Free Motion
 01:30
Vector Functions and Motion: Problem Solving
 00:49
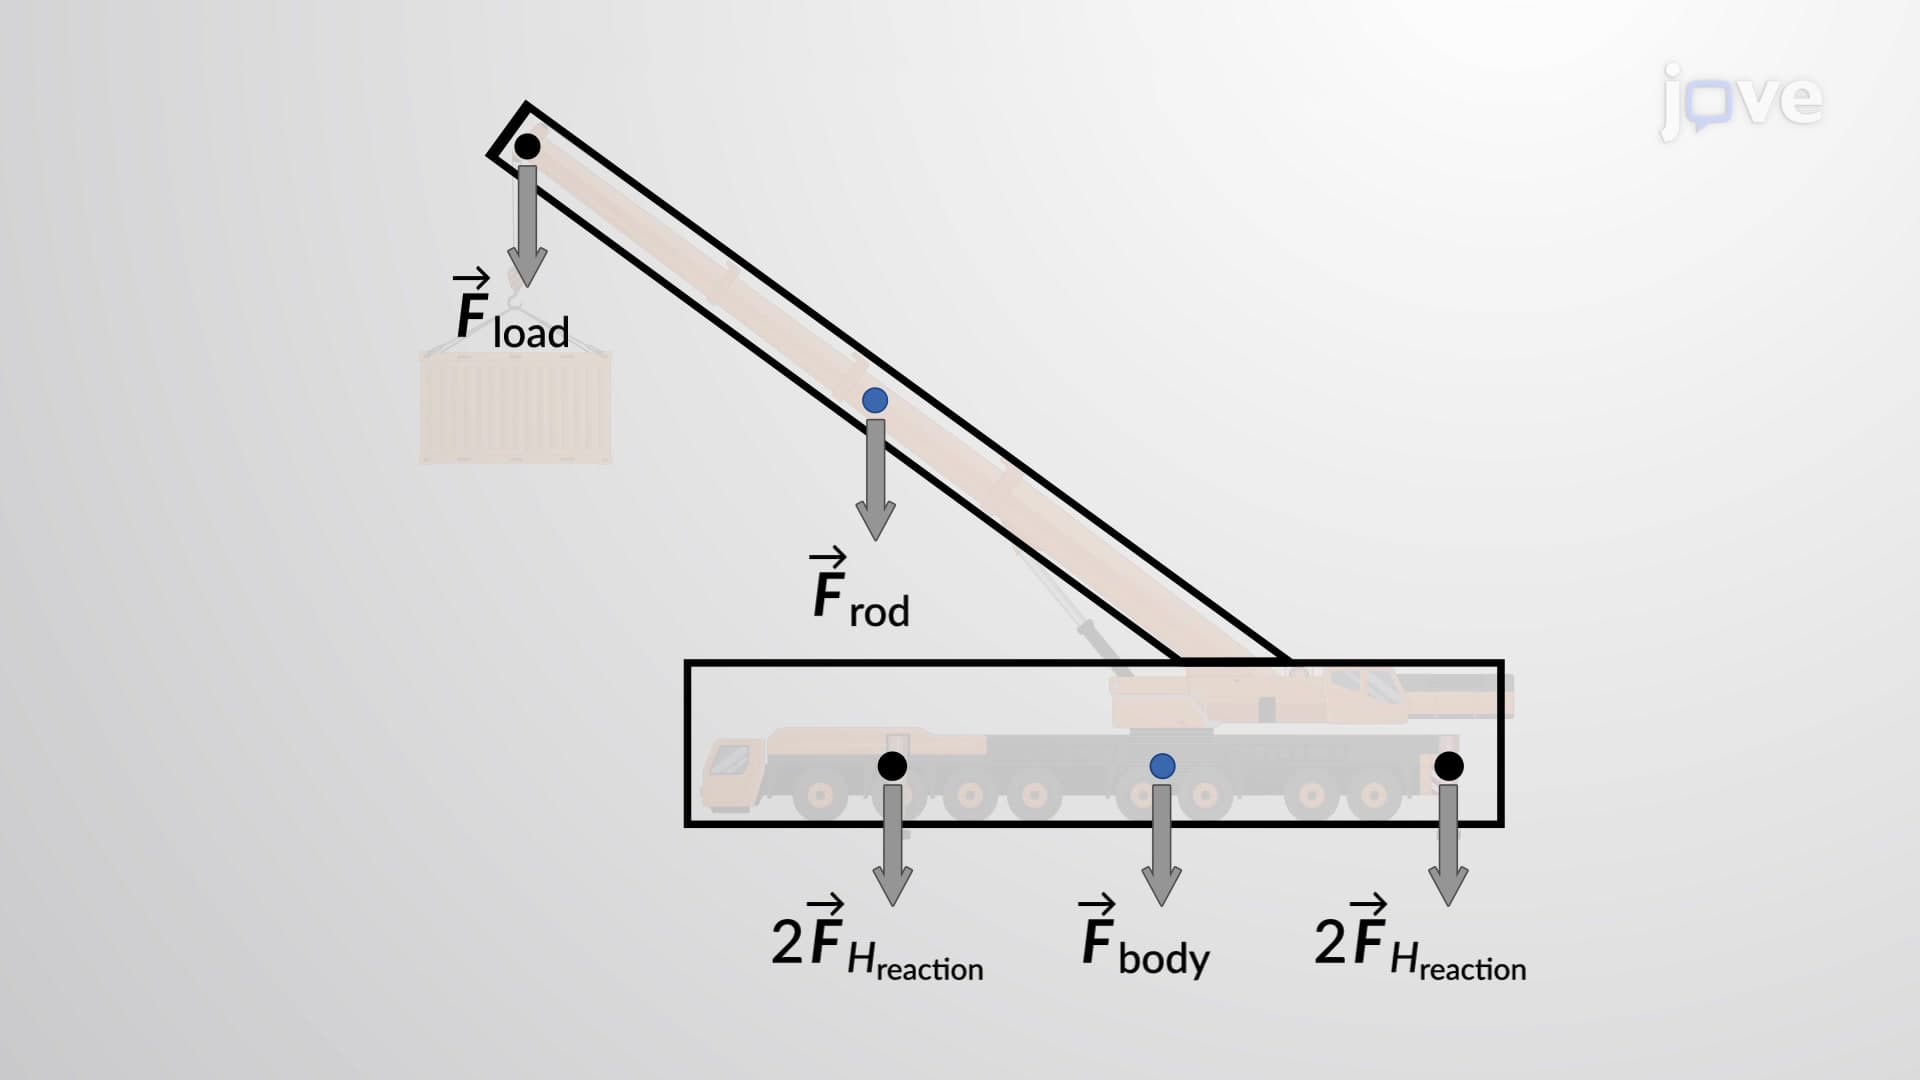
Rigid Body Equilibrium Problems - I
 01:30
Three-Dimensional Force System:Problem Solving
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...