Consistent depth maps recovery from a video sequence
Related Experiment Video
Updated: Jun 23, 2026
High-resolution, High-speed, Three-dimensional Video Imaging with Digital Fringe Projection Techniques
Published on: December 3, 2013
Guofeng Zhang1, Jiaya Jia, Tien-Tsin Wong
1State Key Lab of CAD & CG, Zijingang Campus, Zhejiang University, Hangzhou, 310058, P.R. China. zhangguofeng@cad.zju.edu.cn

Abstract:
This paper presents a novel method for recovering consistent depth maps from a video sequence. We propose a bundle optimization framework to address the major difficulties in stereo reconstruction, such as dealing with image noise, occlusions, and outliers. Different from the typical multi-view stereo methods, our approach not only imposes the photo-consistency constraint, but also explicitly associates the geometric coherence with multiple frames in a statistical way. It thus can naturally maintain the temporal coherence of the recovered dense depth maps without over-smoothing. To make the inference tractable, we introduce an iterative optimization scheme by first initializing the disparity maps using a segmentation prior and then refining the disparities by means of bundle optimization. Instead of defining the visibility parameters, our method implicitly models the reconstruction noise as well as the probabilistic visibility. After bundle optimization, we introduce an efficient space-time fusion algorithm to further reduce the reconstruction noise. Our automatic depth recovery is evaluated using a variety of challenging video examples.
Related Concept Videos
 01:18
Uniform Depth Channel Flow: Problem Solving
 01:15
Depth Perception and Spatial Vision
 01:27
Uniform Depth Channel Flow
 01:20
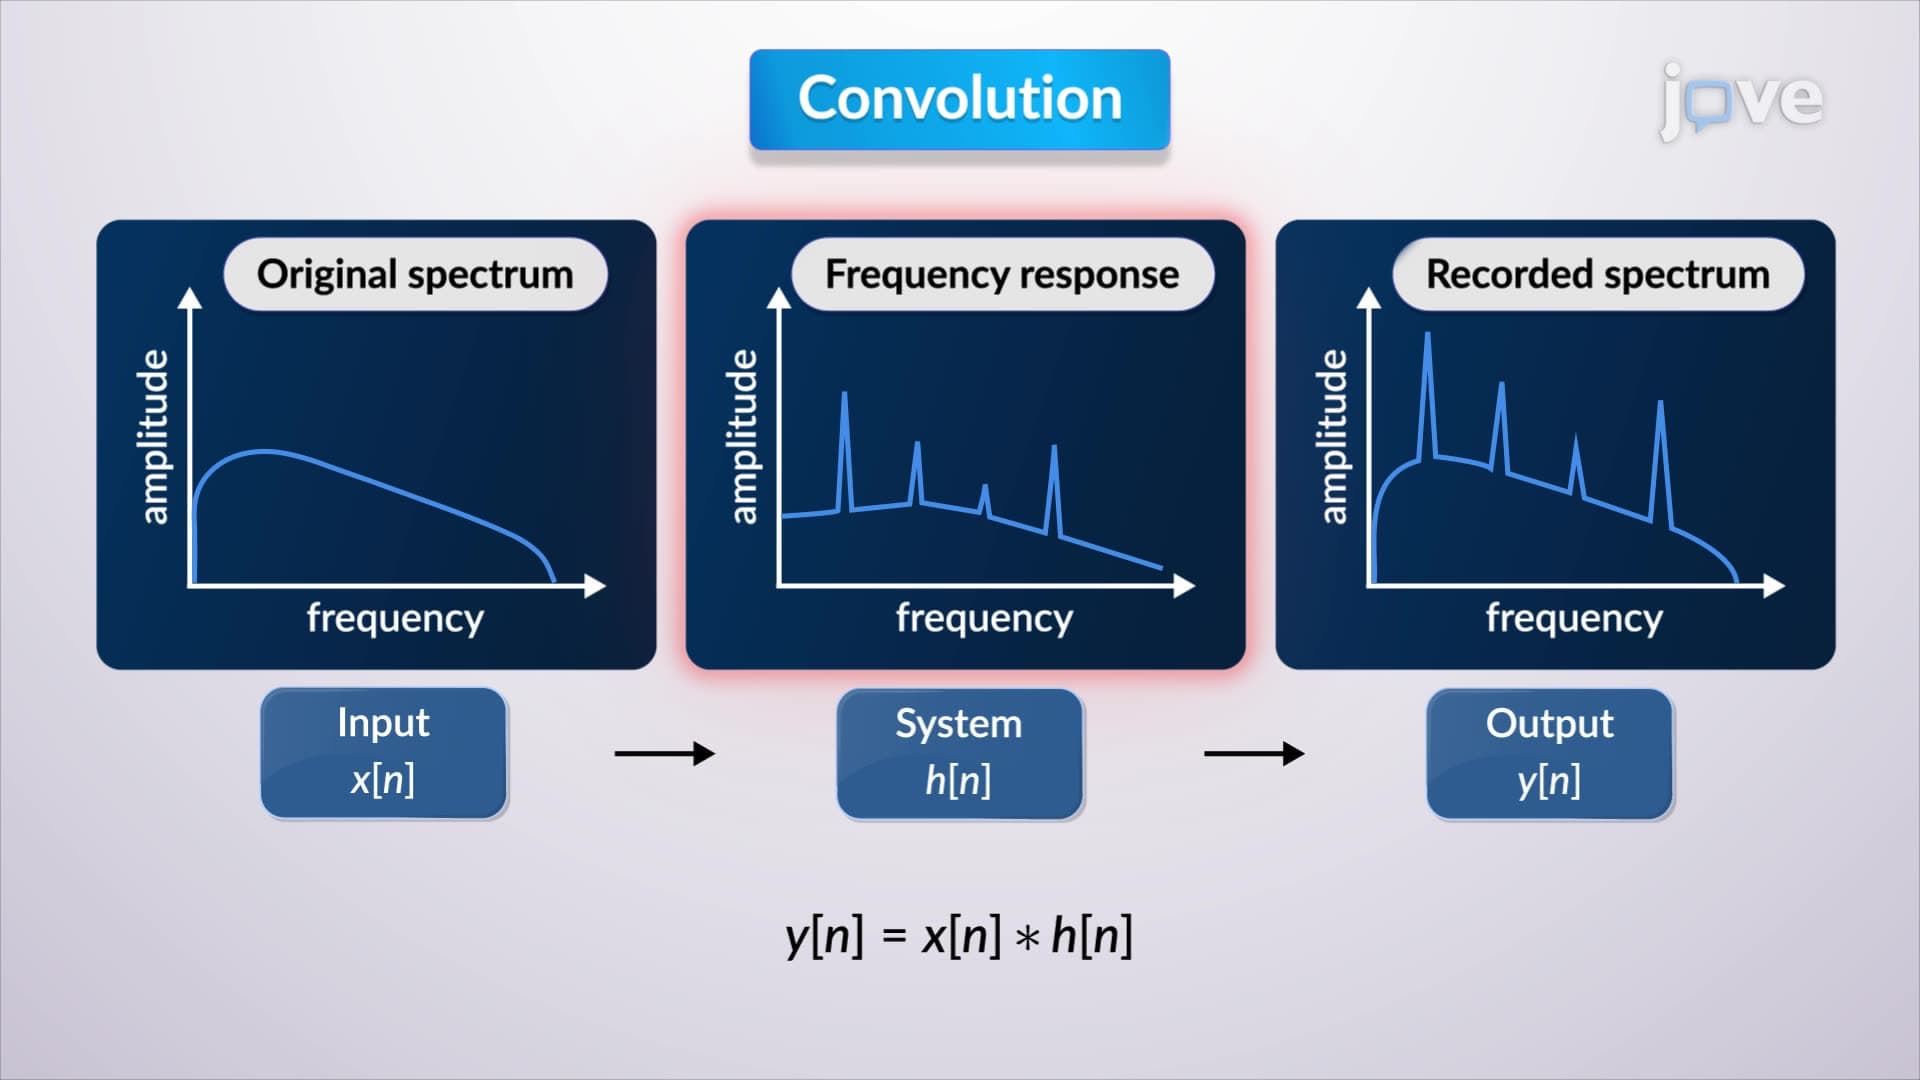
Deconvolution
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
 01:18
Distance Measurements by Taping
 01:22
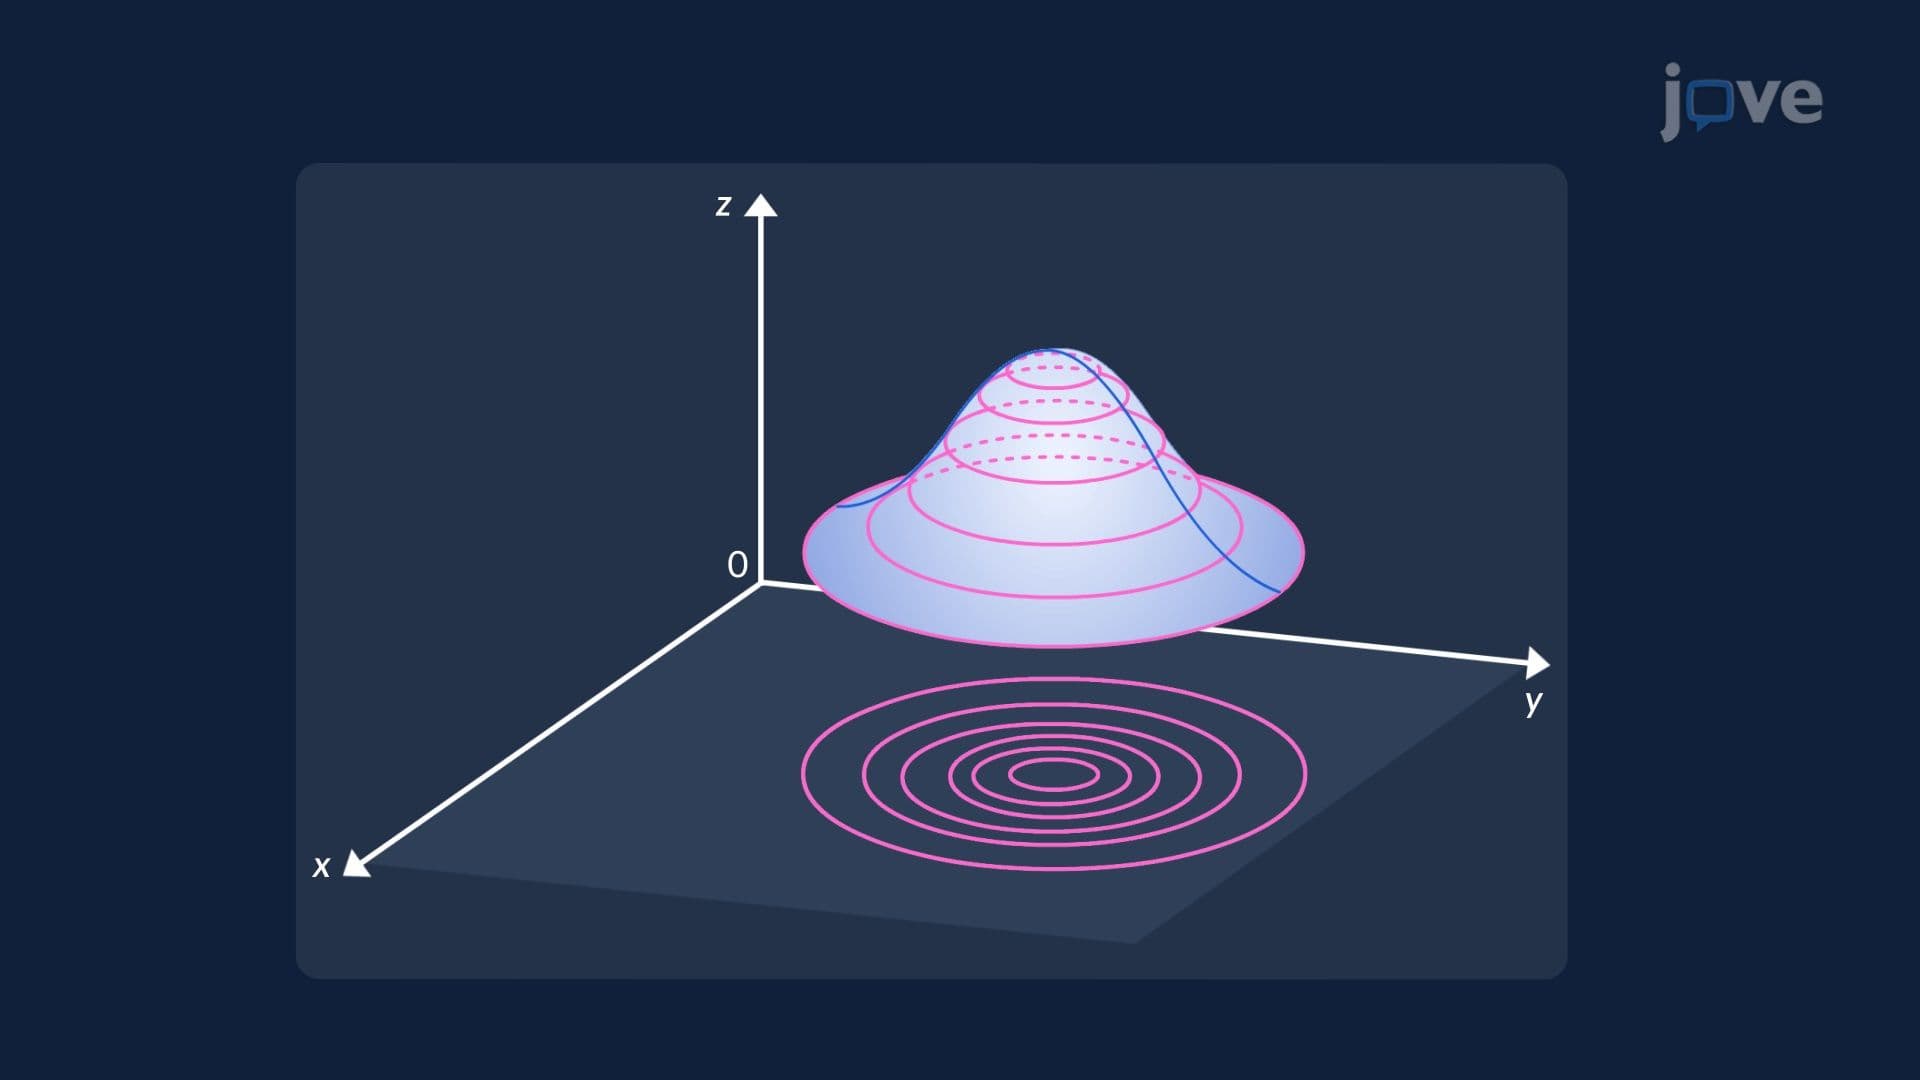
Level Curves and Contour Maps