Comparison of different state space definitions for local dynamic stability analyses
Related Experiment Video
Updated: Jun 23, 2026

Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Deanna H Gates1, Jonathan B Dingwell
1Department of Biomedical Engineering, University of Texas, Austin, TX 78712, USA. dgates@mail.utexas.edu

Abstract:
Measures of local dynamic stability, such as the local divergence exponent (lambda*(s)) quantify how quickly small perturbations deviate from an attractor that defines the motion. When the governing equations of motion are unknown, an attractor can be reconstructed by defining an appropriate state space. However, state space definitions are not unique and accepted methods for defining state spaces have not been established for biomechanical studies. This study first determined how different state space definitions affected lambda*(s) for the Lorenz attractor, since exact theoretical values were known a priori. Values of lambda*(s) exhibited errors <10% for 7 of the 9 state spaces tested. State spaces containing redundant information performed the poorest. To examine these effects in a biomechanical context, 20 healthy subjects performed a repetitive sawing-like task for 5 min before and after fatigue. Local stability of pre- and post-fatigue shoulder movements was compared for 6 different state space definitions. Here, lambda*(s)decreased post-fatigue for all 6 state spaces. Differences were statistically significant for 3 of these state spaces. For state spaces defined using delay embedding, increasing the embedding dimension decreased lambda*(s) in both the Lorenz and experimental data. Overall, our findings suggest that direct numerical comparisons between studies that use different state space definitions should be made with caution. However, trends across experimental comparisons appear to persist. Biomechanical state spaces constructed using positions and velocities, or delay reconstruction of individual states, are likely to provide consistent results.
Related Concept Videos
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:28
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:23
Transfer Function to State Space
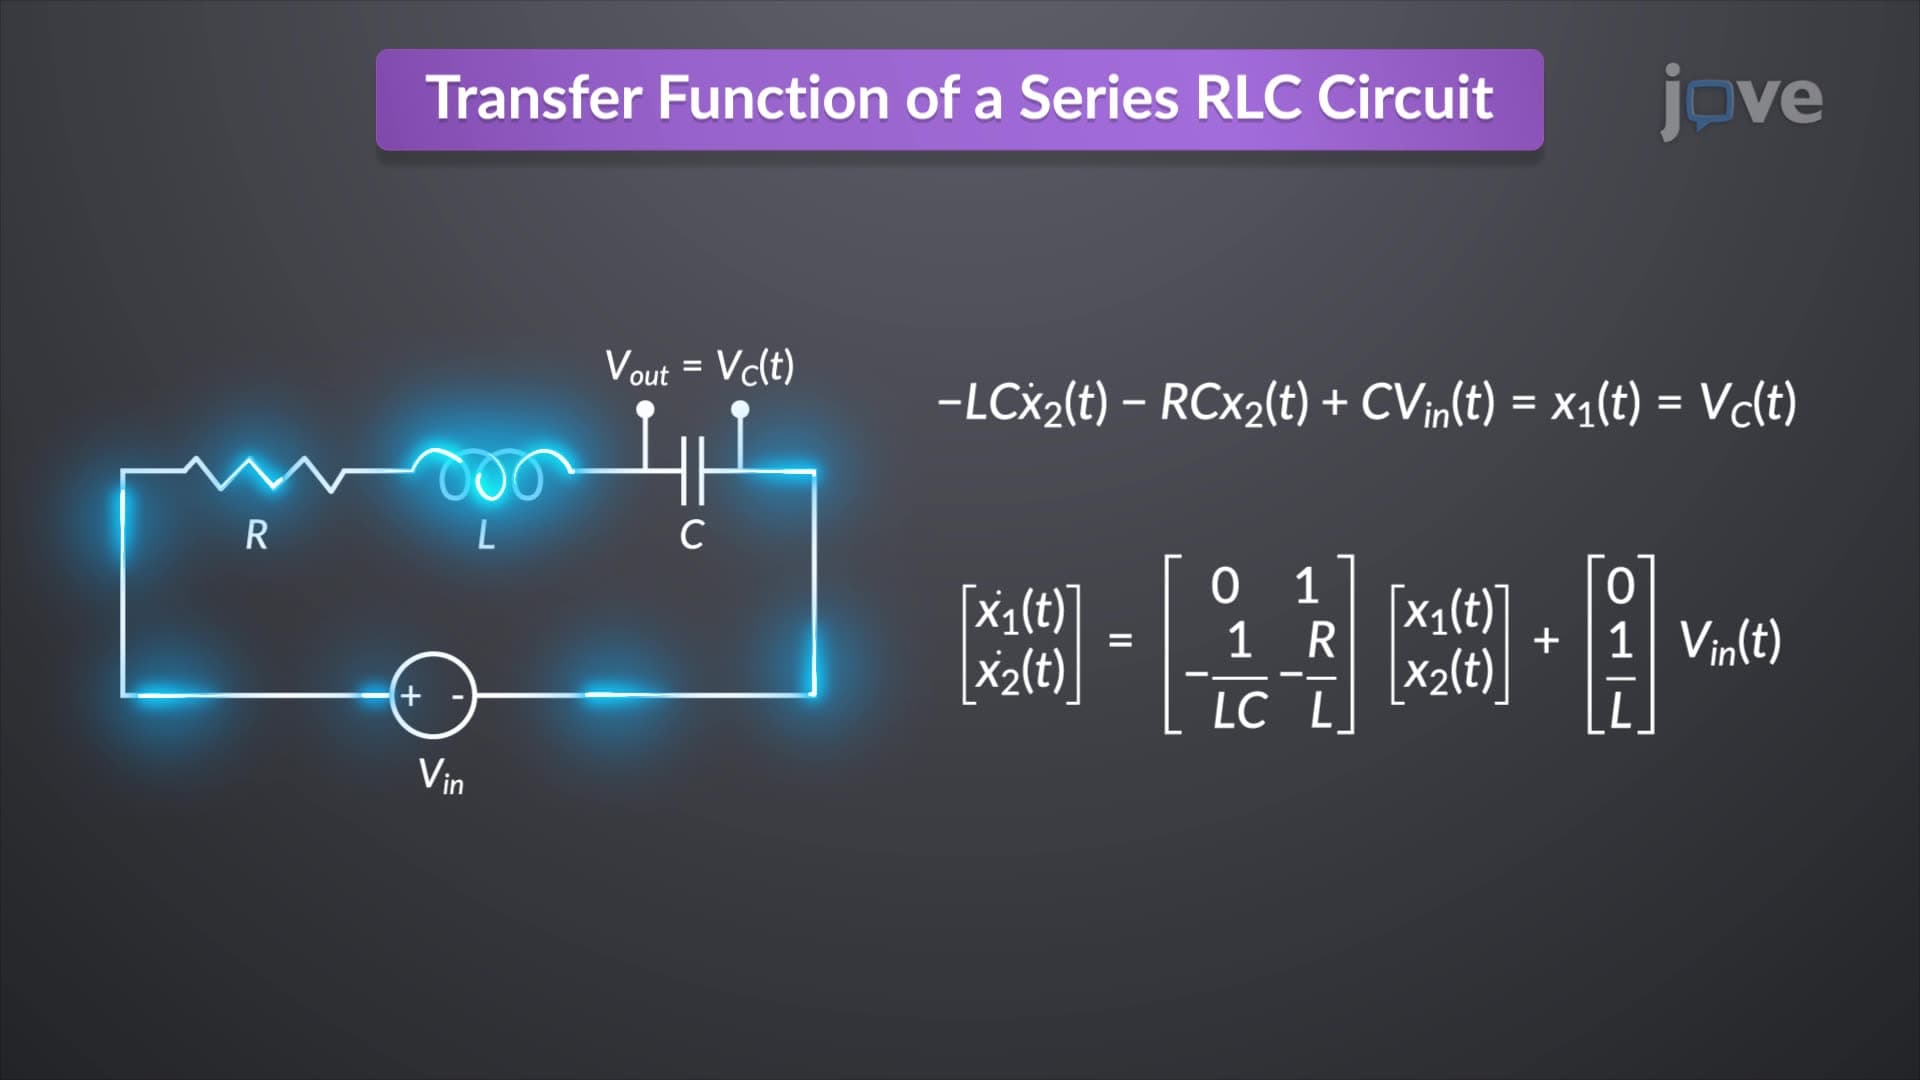
In an RLC...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:21
State Space to Transfer Function
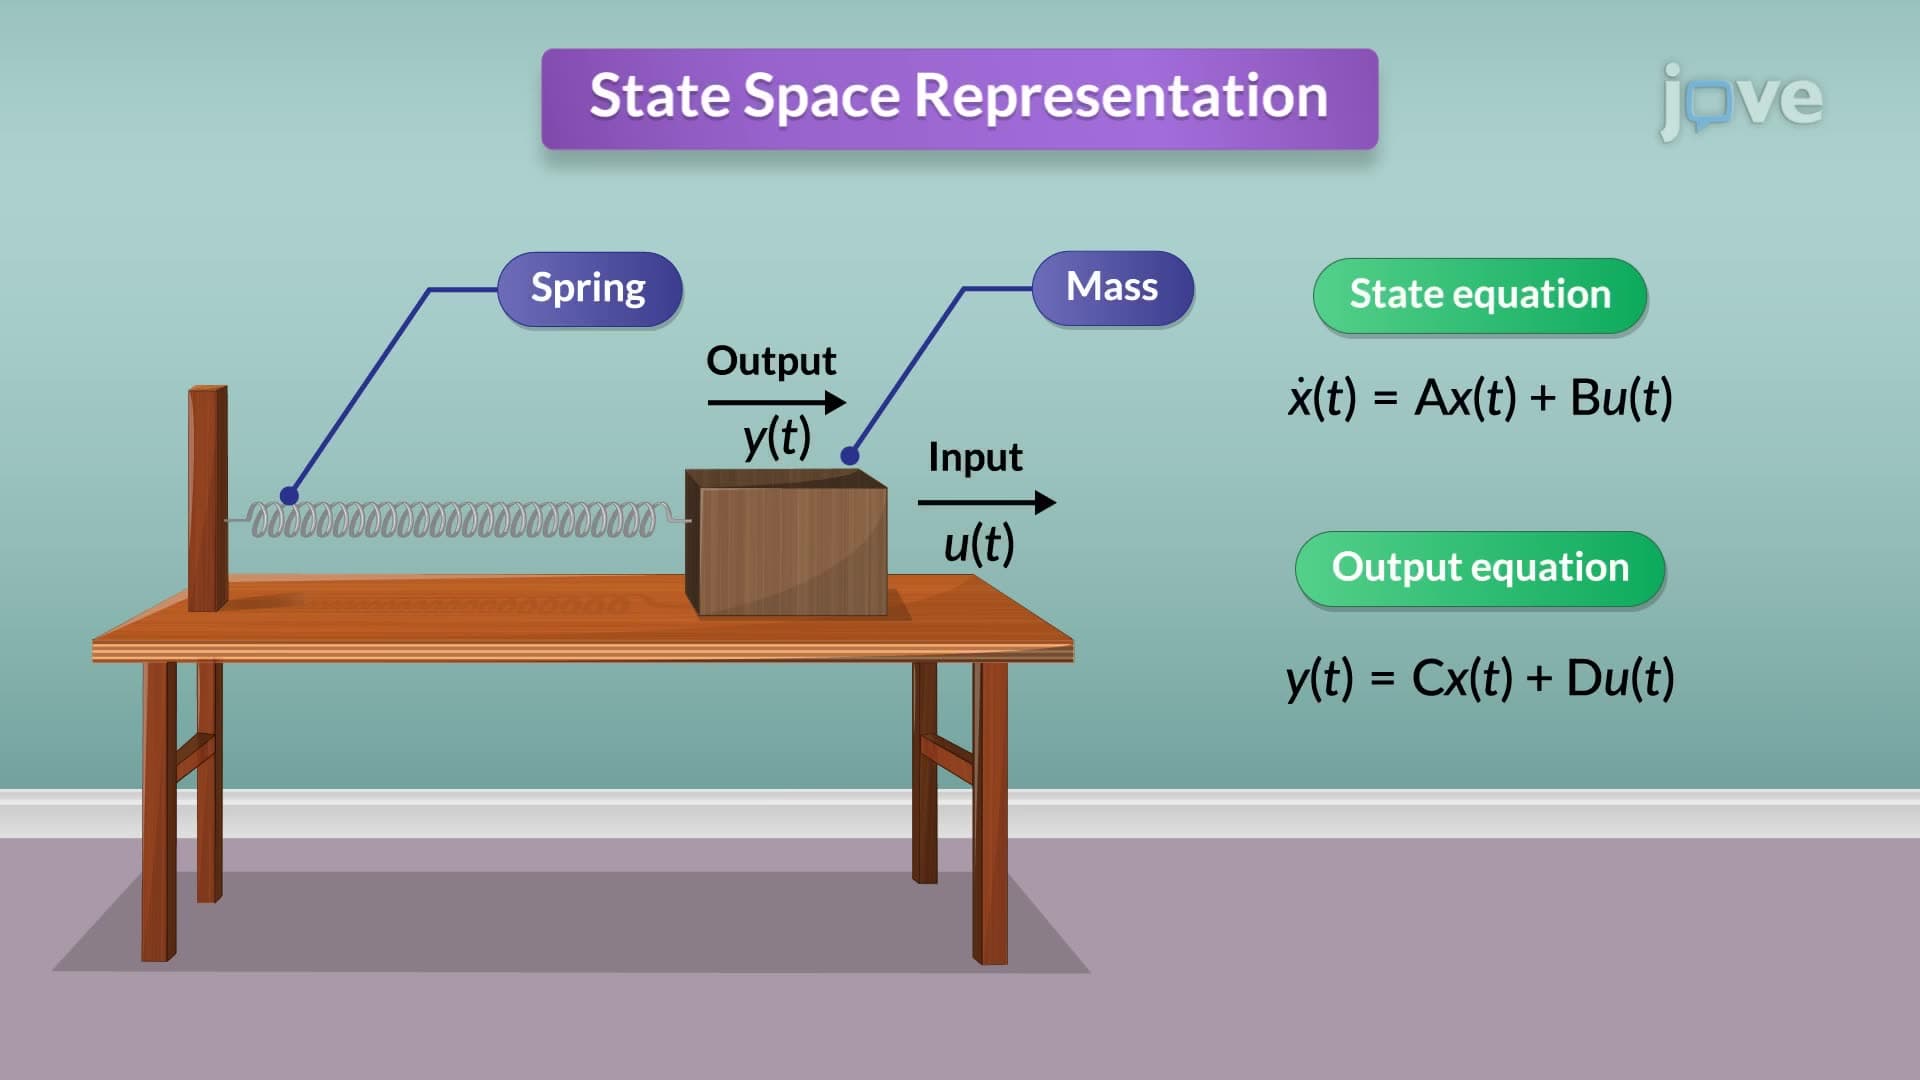
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by: