Related Experiment Video
Updated: Jun 23, 2026
Quantification of Strain in a Porcine Model of Skin Expansion Using Multi-View Stereo and Isogeometric Kinematics
Published on: April 16, 2017
Variational B-spline level-set: a linear filtering approach for fast deformable model evolution
Olivier Bernard1, Denis Friboulet, Philippe Thévenaz
1CREATIS, INSA, UCB, CNRS UMR 5220, Inserm U630, 69621 Villeurbanne Cedex, France. bernard@creatis.insa-lyon.fr

Abstract:
In the field of image segmentation, most level-set-based active-contour approaches take advantage of a discrete representation of the associated implicit function. We present in this paper a different formulation where the implicit function is modeled as a continuous parametric function expressed on a B-spline basis. Starting from the active-contour energy functional, we show that this formulation allows us to compute the solution as a restriction of the variational problem on the space spanned by the B-splines. As a consequence, the minimization of the functional is directly obtained in terms of the B-spline coefficients. We also show that each step of this minimization may be expressed through a convolution operation. Because the B-spline functions are separable, this convolution may in turn be performed as a sequence of simple 1-D convolutions, which yields an efficient algorithm. As a further consequence, each step of the level-set evolution may be interpreted as a filtering operation with a B-spline kernel. Such filtering induces an intrinsic smoothing in the algorithm, which can be controlled explicitly via the degree and the scale of the chosen B-spline kernel. We illustrate the behavior of this approach on simulated as well as experimental images from various fields.
More Related Videos
Related Concept Videos
 01:25
Modeling with Differential Equations
 01:26
Linear Approximation in Frequency Domain
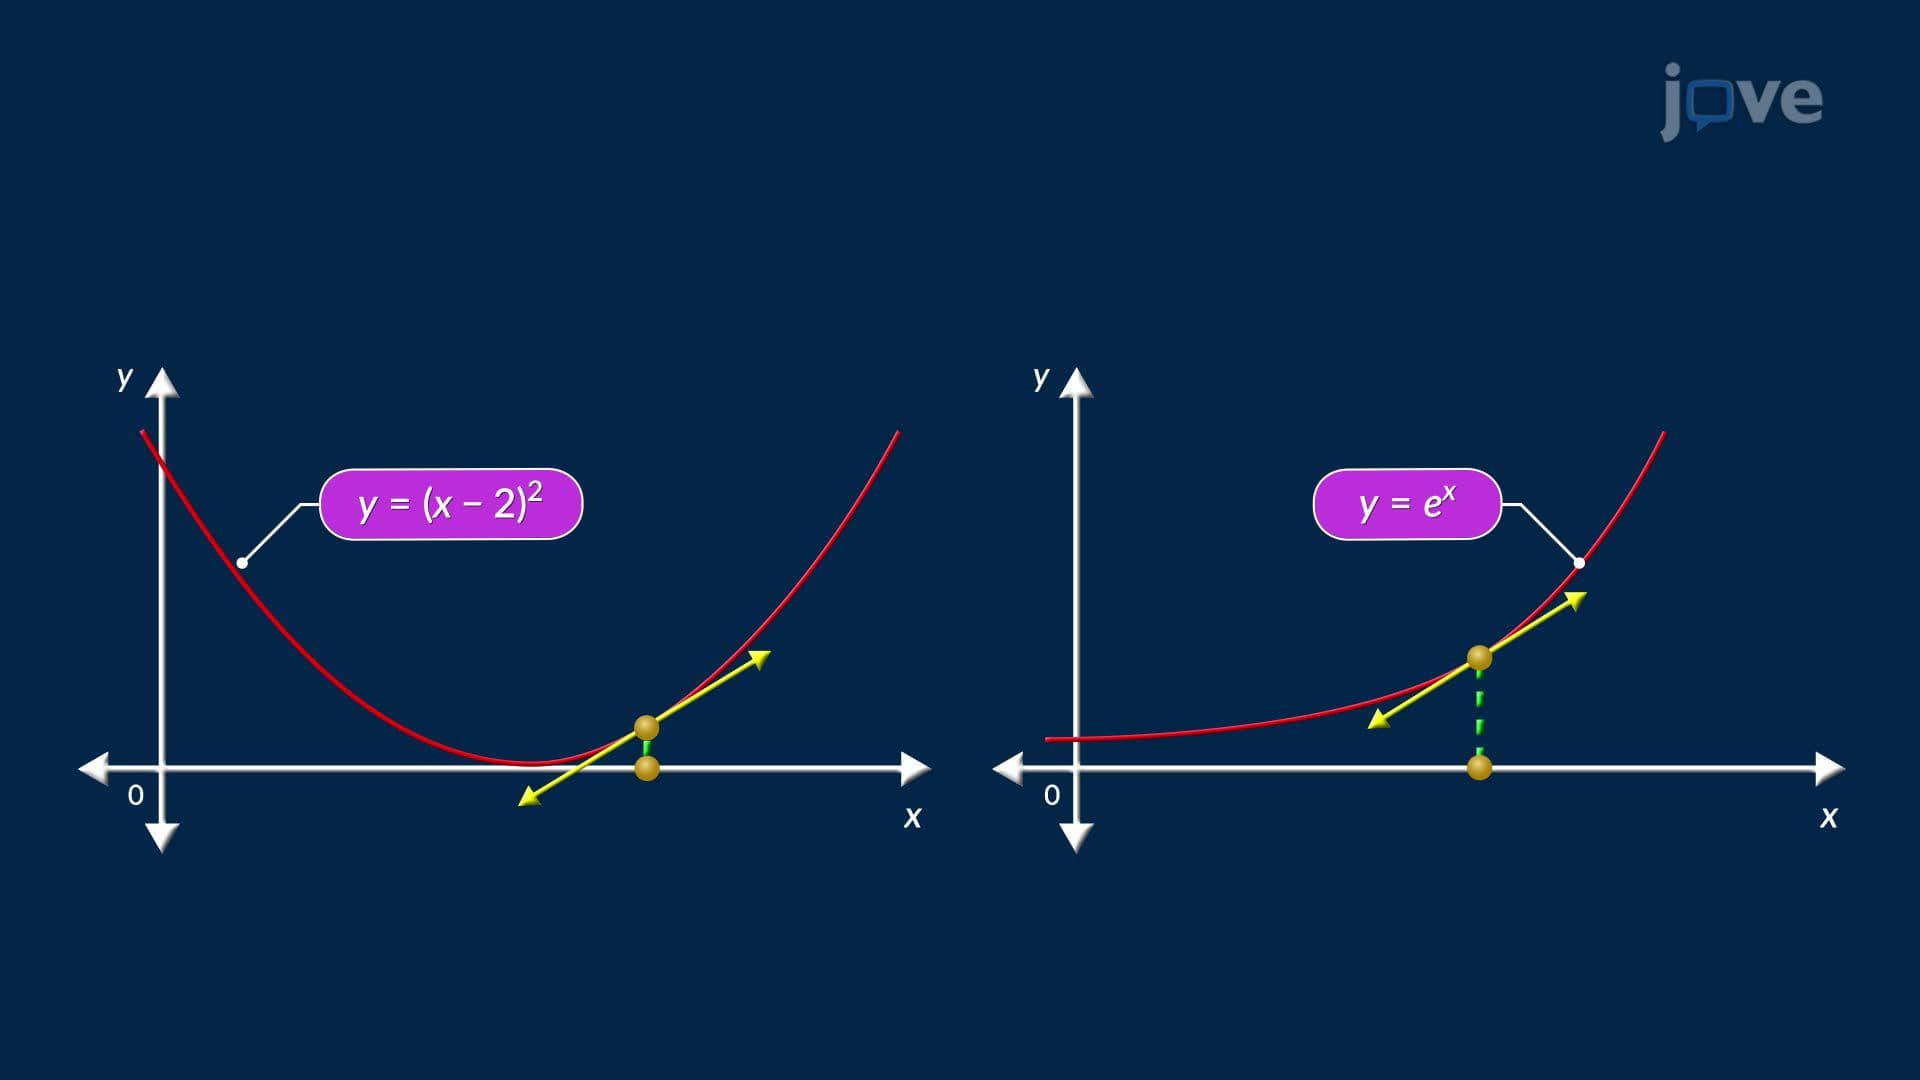
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:26
Linearization and Approximation
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:23
Linear Approximations
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...