Related Experiment Video
Updated: Jun 23, 2026
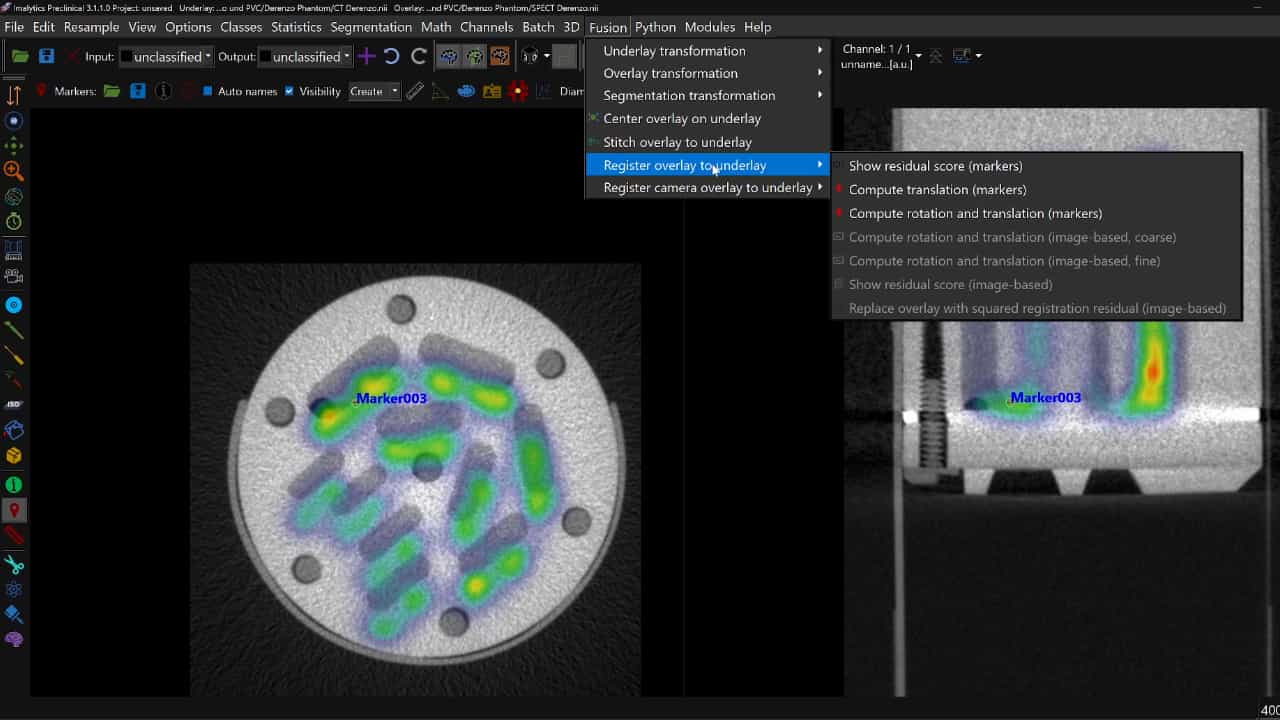

Multimodal Cross-Device and Marker-Free Co-Registration of Preclinical Imaging Modalities
Published on: October 27, 2023
Distribution of target registration error for anisotropic and inhomogeneous fiducial localization error
Mehdi Hedjazi Moghari1, Purang Abolmaesumi
1Department of Electrical and Computer Engineering, Queen's University, Kingston, ON, K7L 3N6 Canada.

Abstract:
In point-based rigid-body registration, target registration error (TRE) is an important measure of the accuracy of the performed registration. The registration's accuracy depends on the fiducial localization error (FLE) which, in turn, is due to the measurement errors in the points (fiducials) used to perform the registration. FLE may have different characteristics and distributions at each point of the registering data sets, and along each orthogonal axis. Previously, the distribution of TRE was estimated based on the assumption that FLE has an independent, identical, and isotropic or anisotropic distribution for each point in the registering data sets. In this article, we present a general solution based on the Maximum Likelihood (ML) algorithm that estimates the distribution of TRE for the cases where FLE has an independent, identical or inhomogeneous, isotropic or anisotropic, distribution at each point in the registering data sets, and when an algorithm is available that is capable of calculating the optimum registration to first order. Mathematically, we show that the proposed algorithm simplifies to the one proposed by Fitzpatrick and West when FLE has an independent, identical, and isotropic distribution in the registering data sets. Furthermore, we use numerical simulations to show that the proposed algorithm accurately estimates the distribution of TRE when FLE has an independent, inhomogeneous, and anisotropic distribution in the registering data sets.
More Related Videos
Related Concept Videos
 01:17
Common Leveling Mistakes and Errors
 01:26
Errors in Global Positioning System