Related Experiment Video
Updated: Jun 23, 2026


An Experimental Platform to Study the Closed-loop Performance of Brain-machine Interfaces
Published on: March 10, 2011
Temporal evolution of "automatic gain-scaling"
J Andrew Pruszynski1, Isaac Kurtzer, Timothy P Lillicrap
1Centre for Neuroscience Studies, Queen's University, Kingston, Ontario K7L 3N6, Canada.

Abstract:
The earliest neural response to a mechanical perturbation, the short-latency stretch response (R1: 20-45 ms), is known to exhibit "automatic gain-scaling" whereby its magnitude is proportional to preperturbation muscle activity. Because gain-scaling likely reflects an intrinsic property of the motoneuron pool (via the size-recruitment principle), counteracting this property poses a fundamental challenge for the nervous system, which must ultimately counter the absolute change in load regardless of the initial muscle activity (i.e., show no gain-scaling). Here we explore the temporal evolution of gain-scaling in a simple behavioral task where subjects stabilize their arm against different background loads and randomly occurring torque perturbations. We quantified gain-scaling in four elbow muscles (brachioradialis, biceps long, triceps lateral, triceps long) over the entire sequence of muscle activity following perturbation onset-the short-latency response, long-latency response (R2: 50-75 ms; R3: 75-105 ms), early voluntary corrections (120-180 ms), and steady-state activity (750-1250 ms). In agreement with previous observations, we found that the short-latency response demonstrated substantial gain-scaling with a threefold increase in background load resulting in an approximately twofold increase in muscle activity for the same perturbation. Following the short-latency response, we found a rapid decrease in gain-scaling starting in the long-latency epoch ( approximately 75-ms postperturbation) such that no significant gain-scaling was observed for the early voluntary corrections or steady-state activity. The rapid decrease in gain-scaling supports our recent suggestion that long-latency responses and voluntary control are inherently linked as part of an evolving sensorimotor control process through similar neural circuitry.
More Related Videos

Related Concept Videos
 01:15
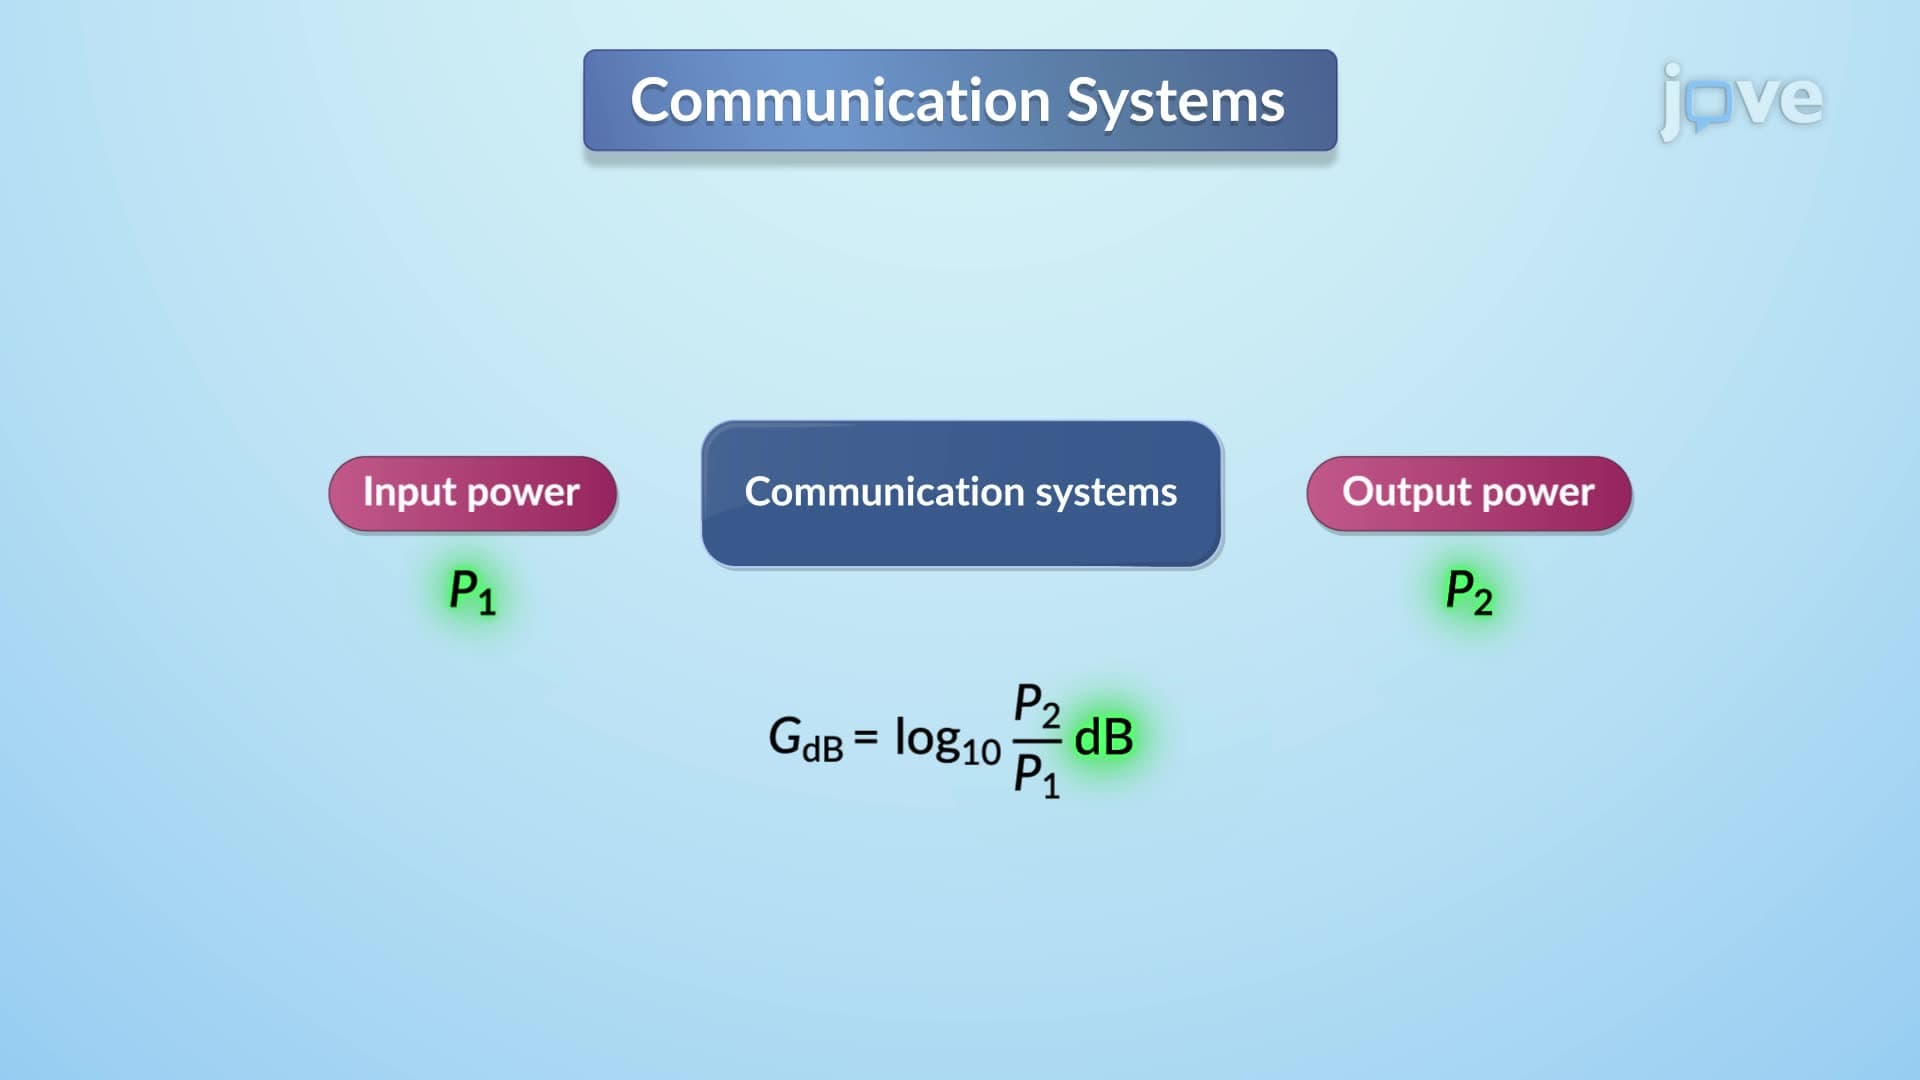
Gain
Gain:
Suppose Vin is the input and Vout is the output signal to a circuit.
 01:26
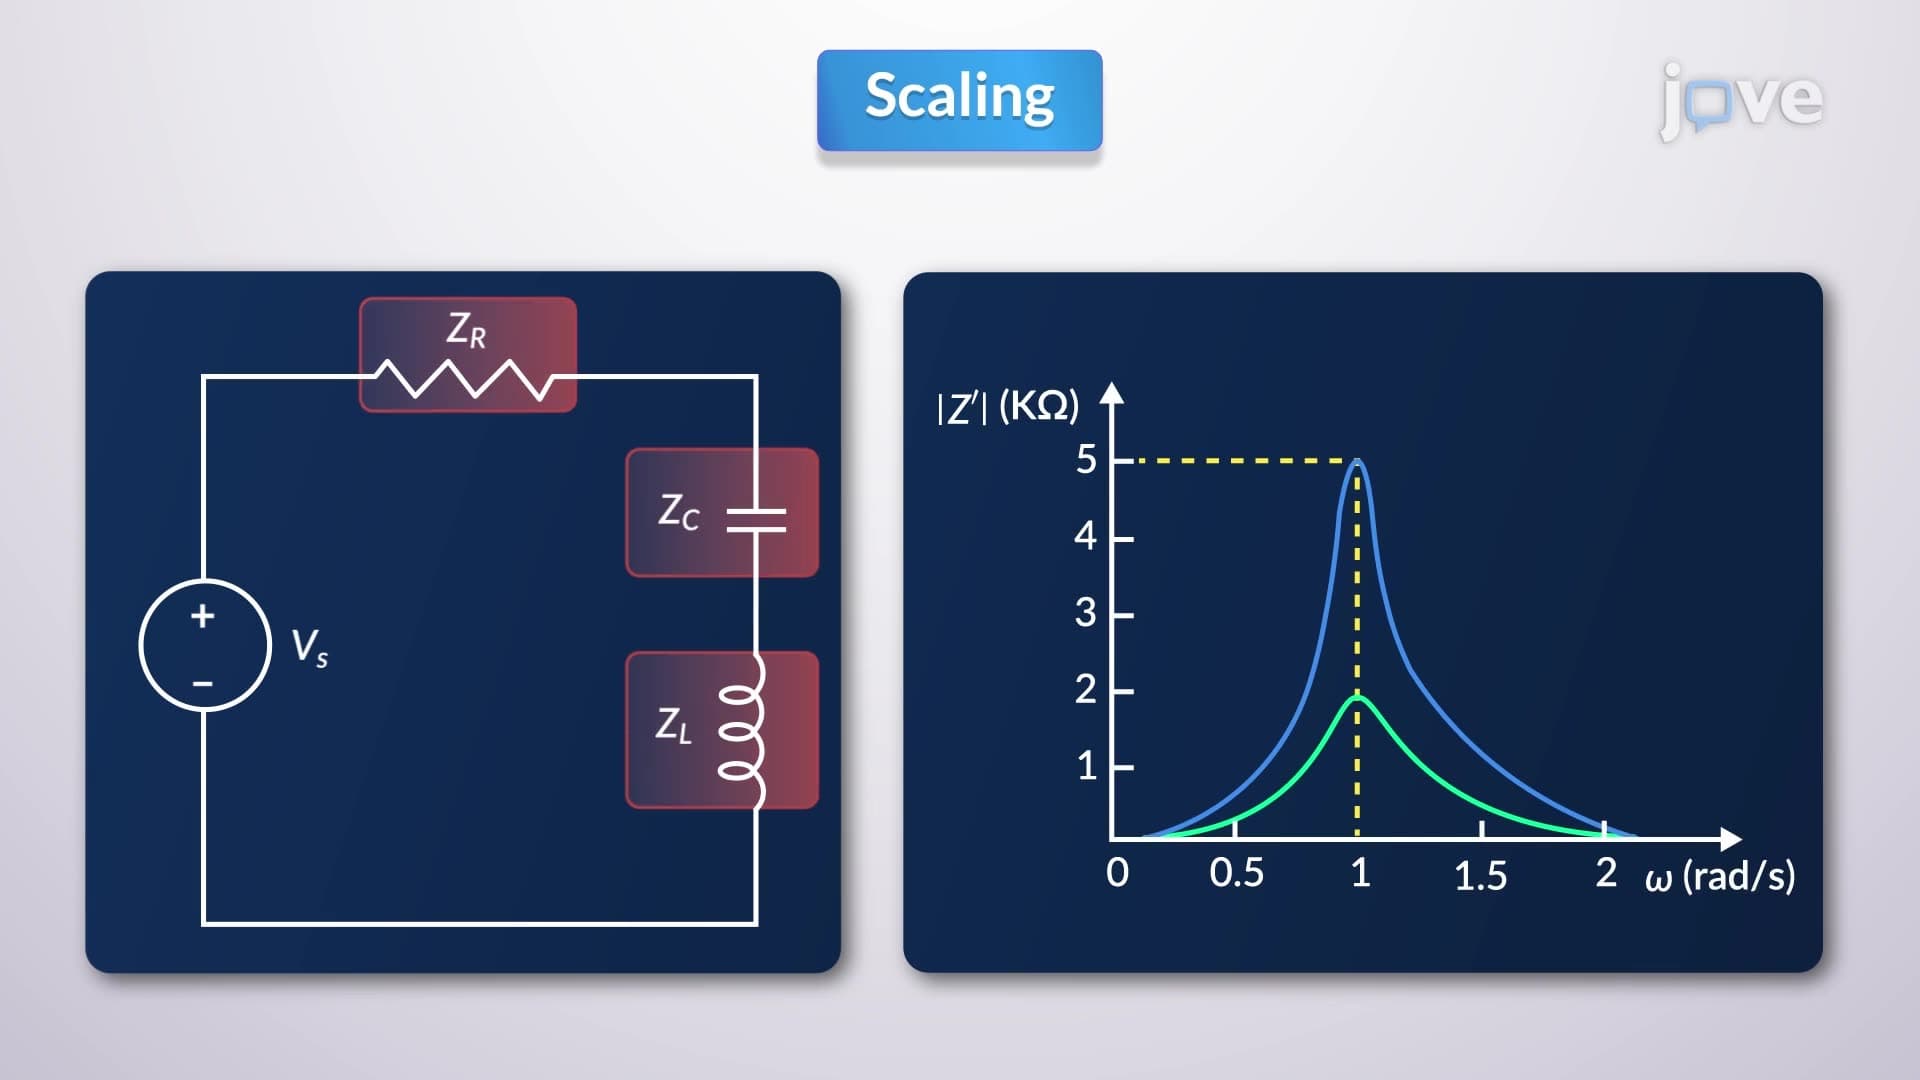
Scaling
 01:22
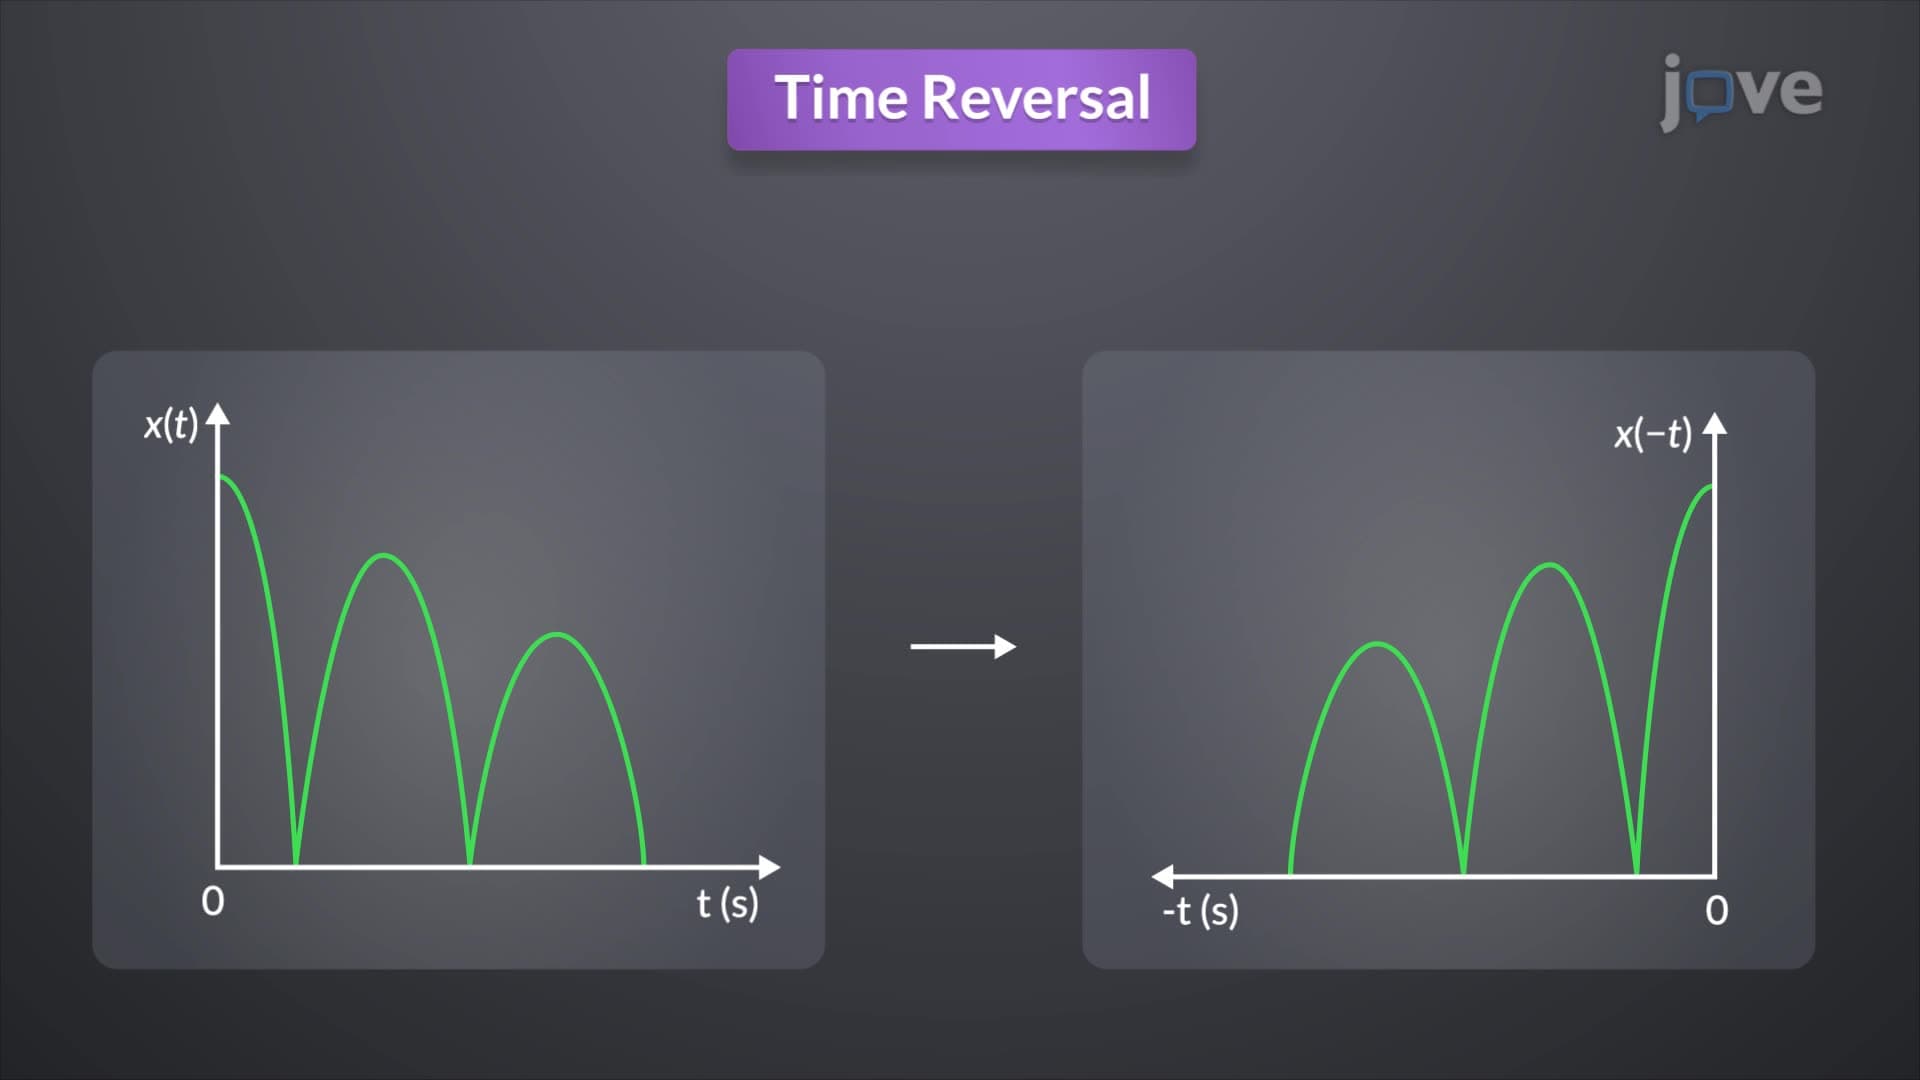
Basic Operations on Signals
Time Reversal mirrors a continuous-time signal about the vertical axis at t=0. This is achieved by substituting t with −t. For example, if a signal x(t) is considered, the time-reversed signal is x(−t). This operation can be graphically represented, showing the mirrored signal.
 01:16
Cascaded Op Amps
In a cascaded system, each op-amp is referred to as a stage. The output of one stage drives the input of the subsequent stage. As the input signal passes through...
 01:21
Introduction to Scalers
Scalar...
 01:23
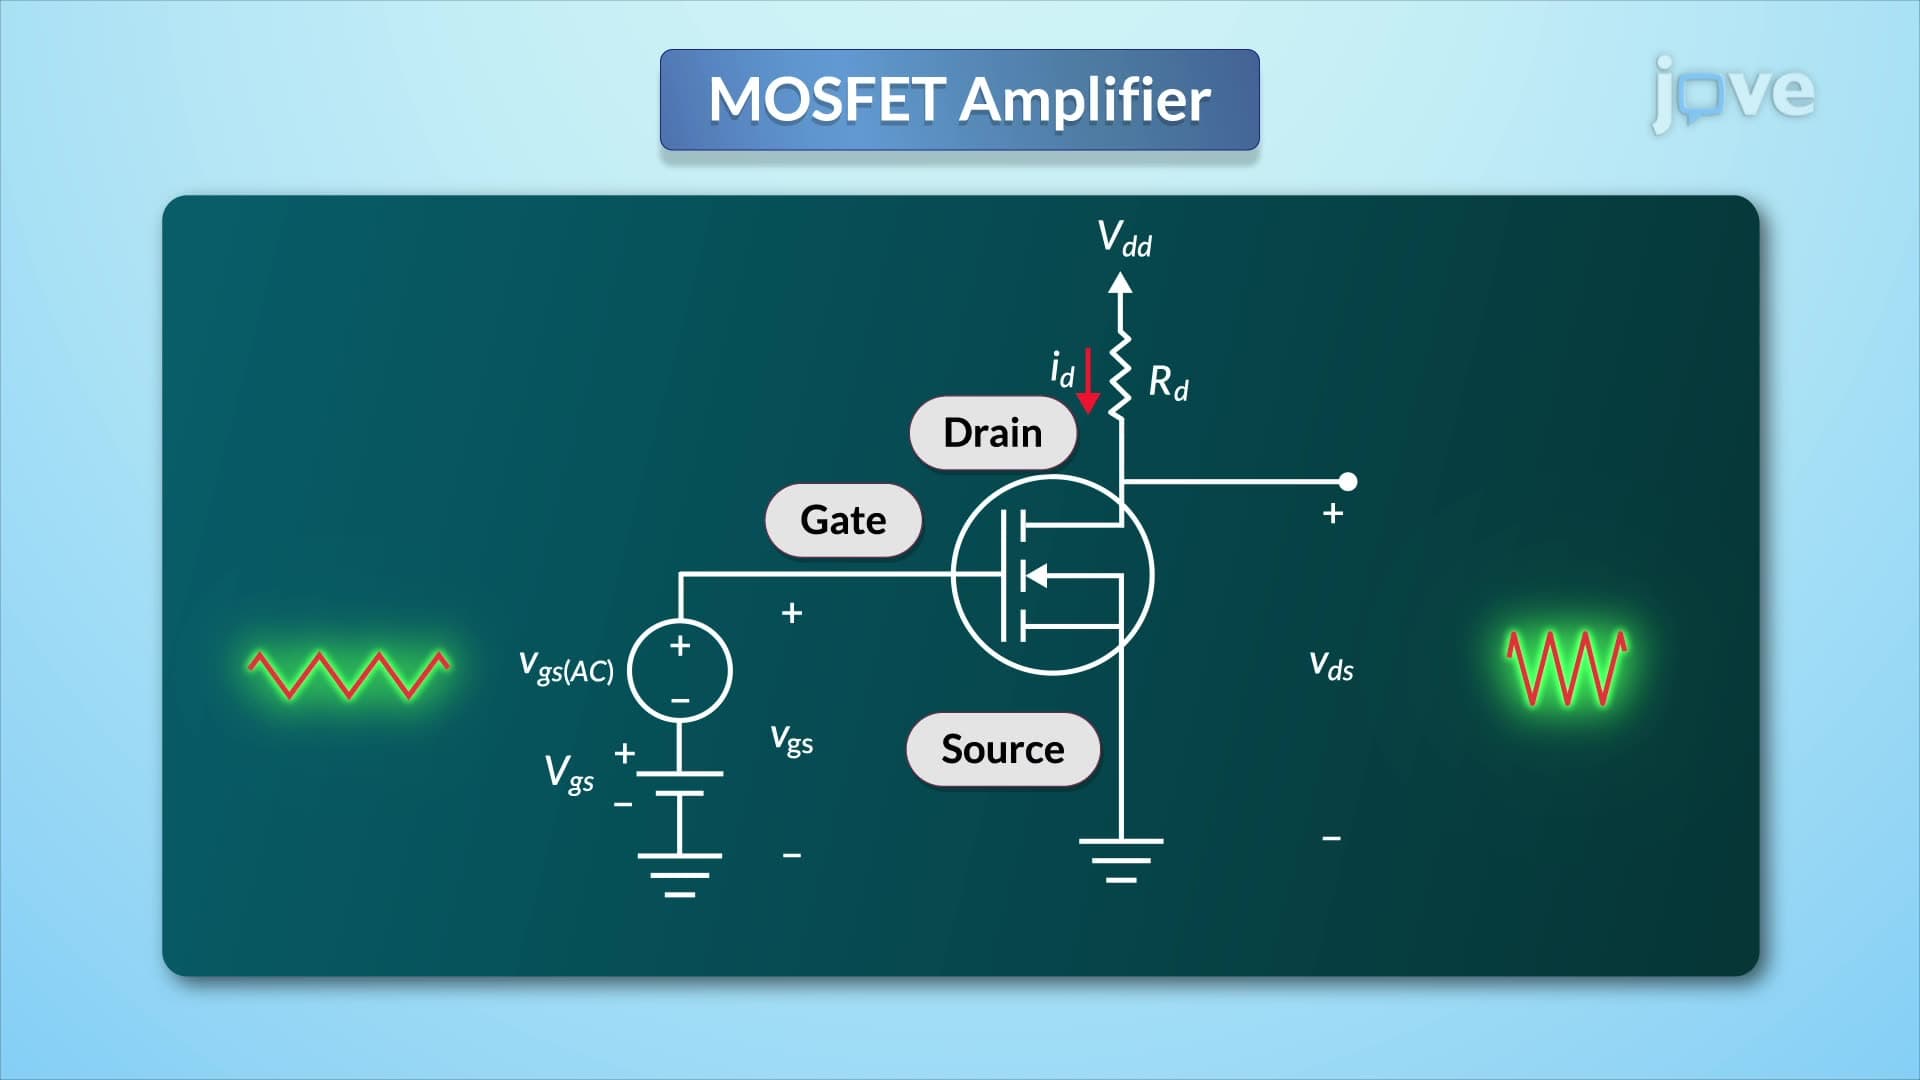
Small-Signal Analysis of MOSFET Amplifiers