Deformable wing kinematics in free-flying hoverflies
Related Experiment Video
Updated: Jun 23, 2026
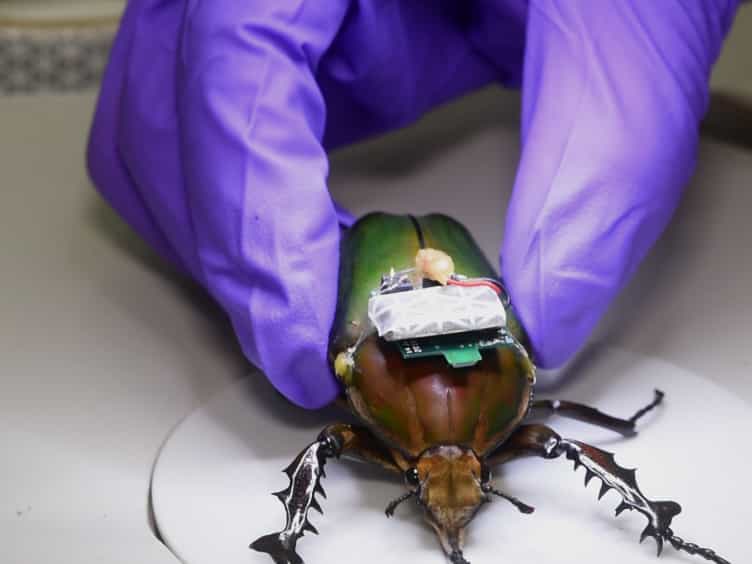
Insect-machine Hybrid System: Remote Radio Control of a Freely Flying Beetle (Mercynorrhina torquata)
Published on: September 2, 2016
Simon M Walker1, Adrian L R Thomas, Graham K Taylor
1Department of Zoology, University of Oxford, South Parks Road, Oxford OX1 3PS, UK.

Abstract:
Here, we present a detailed analysis of the deforming wing kinematics of free-flying hoverflies (Eristalis tenax, Linnaeus) during hovering flight. We used four high-speed digital video cameras to reconstruct the motion of approximately 22 points on each wing using photogrammetric techniques. While the root-flapping motion of the wing is similar in both the downstroke and upstroke, and is well modelled as a simple harmonic motion, other wing kinematic parameters show substantial variation between the downstroke and upstroke. Whereas the magnitude of the angle of incidence varies considerably within and between different hoverflies, the twist distribution along the wing is highly stereotyped. The angle of incidence and camber both show a recoil effect as they change abruptly at stroke reversal. Pronation occurs consistently after stroke reversal, which is perhaps surprising, because this has been found to reduce lift production in modelling studies. We find that the alula, a hinged flap near the base of the wing, operates in two discrete states: either in plane with the wing, or flipped approximately normal to it. We hypothesize that the alula may be acting as a flow-control device.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:23
Lift
 01:05
Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...
01:05Mechanism of Ciliary Motion
The cilia are made up of microtubules in a 9+2 arrangement, with nine microtubule doublet ring bundles, surrounding a pair of central singlet microtubule bundles. The doublet microtubule bundles are...
 01:30
Vector Functions and Motion: Problem Solving
 01:54
Convergent Evolution