Related Experiment Video
Updated: Jun 23, 2026


Design and Implementation of a Bespoke Robotic Manipulator for Extra-corporeal Ultrasound
Published on: January 7, 2019
A modular planar robotic manipulandum with end-point torque control
Ian S Howard1, James N Ingram, Daniel M Wolpert
1Computational and Biological Learning Laboratory, Department of Engineering, University of Cambridge, Trumpington Street, Cambridge CB21PZ, UK. ish22@cam.ac.uk

Abstract:
Robotic manipulanda are extensively used in investigation of the motor control of human arm movements. They permit the application of translational forces to the arm based on its state and can be used to probe issues ranging from mechanisms of neural control to biomechanics. However, most current designs are optimized for studying either motor learning or stiffness. Even fewer include end-point torque control which is important for the simulation of objects and the study of tool use. Here we describe a modular, general purpose, two-dimensional planar manipulandum (vBOT) primarily optimized for dynamic learning paradigms. It employs a carbon fibre arm arranged as a parallelogram which is driven by motors via timing pulleys. The design minimizes the intrinsic dynamics of the manipulandum without active compensation. A novel variant of the design (WristBOT) can apply torques at the handle using an add-on cable drive mechanism. In a second variant (StiffBOT) a more rigid arm can be substituted and zero backlash belts can be used, making the StiffBOT more suitable for the study of stiffness. The three variants can be used with custom built display rigs, mounting, and air tables. We investigated the performance of the vBOT and its variants in terms of effective end-point mass, viscosity and stiffness. Finally we present an object manipulation task using the WristBOT. This demonstrates that subjects can perceive the orientation of the principal axis of an object based on haptic feedback arising from its rotational dynamics.

Related Concept Videos
 01:15
Torque Free Motion
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:13
Angle of Twist: Problem Solving
 01:23
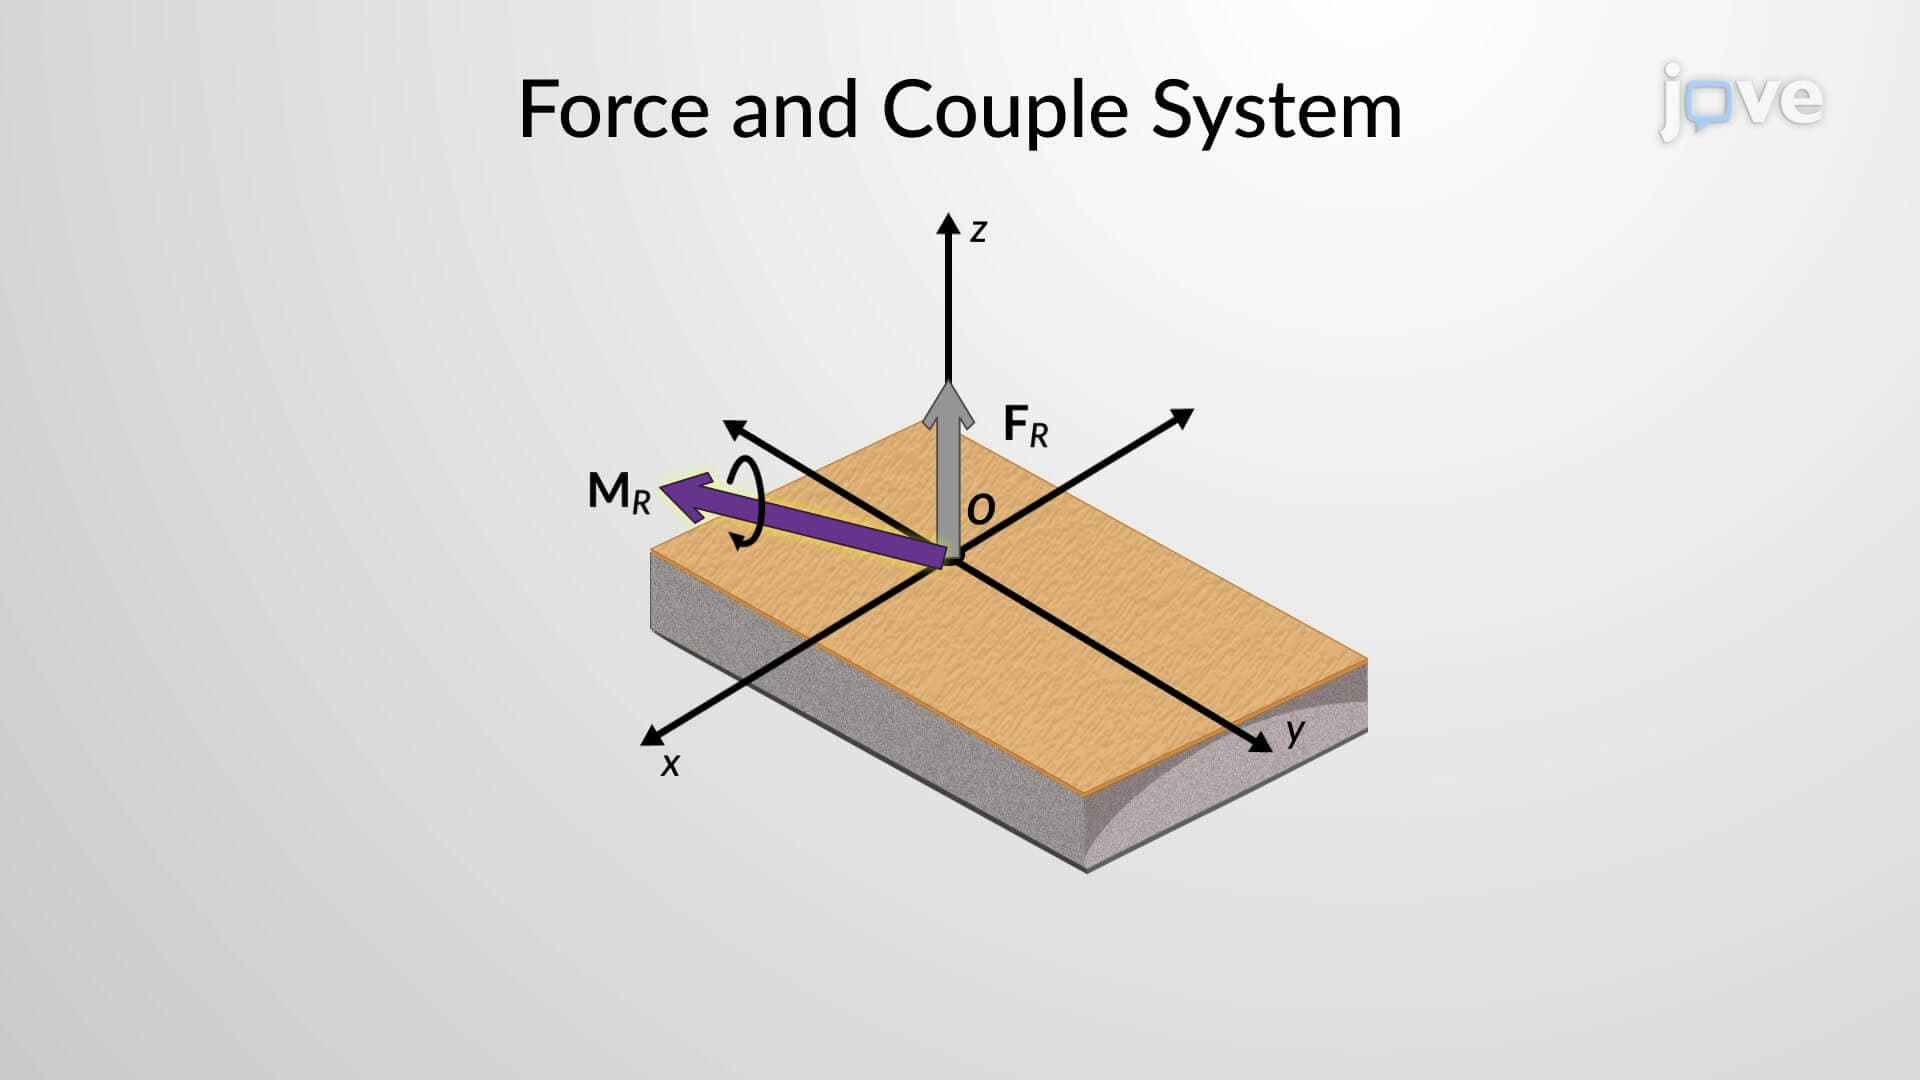
Simplification of a Force and Couple System: II
 01:22
Mechanical Systems