Related Experiment Video
Updated: Jun 22, 2026

Bouncing Ball with a Uniformly Varying Velocity in a Metronome Synchronization Task
Published on: September 21, 2017
Stability and synchronization of discrete-time Markovian jumping neural networks with mixed mode-dependent time
Yurong Liu1, Zidong Wang, Jinling Liang
1Department of Mathematics, Yangzhou University, Yangzhou 225002, China. liuyurong@gmail.com

Abstract:
In this paper, we introduce a new class of discrete-time neural networks (DNNs) with Markovian jumping parameters as well as mode-dependent mixed time delays (both discrete and distributed time delays). Specifically, the parameters of the DNNs are subject to the switching from one to another at different times according to a Markov chain, and the mixed time delays consist of both discrete and distributed delays that are dependent on the Markovian jumping mode. We first deal with the stability analysis problem of the addressed neural networks. A special inequality is developed to account for the mixed time delays in the discrete-time setting, and a novel Lyapunov-Krasovskii functional is put forward to reflect the mode-dependent time delays. Sufficient conditions are established in terms of linear matrix inequalities (LMIs) that guarantee the stochastic stability. We then turn to the synchronization problem among an array of identical coupled Markovian jumping neural networks with mixed mode-dependent time delays. By utilizing the Lyapunov stability theory and the Kronecker product, it is shown that the addressed synchronization problem is solvable if several LMIs are feasible. Hence, different from the commonly used matrix norm theories (such as the M-matrix method), a unified LMI approach is developed to solve the stability analysis and synchronization problems of the class of neural networks under investigation, where the LMIs can be easily solved by using the available Matlab LMI toolbox. Two numerical examples are presented to illustrate the usefulness and effectiveness of the main results obtained.
Related Concept Videos
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system.
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:25
Modeling with Differential Equations
 01:22
Basic Continuous Time Signals
The unit step function, denoted u(t), is zero for negative time values and one for positive time values, exhibiting a discontinuity at t=0. This function often represents abrupt changes, such as the step voltage introduced when turning a car's...
 01:13
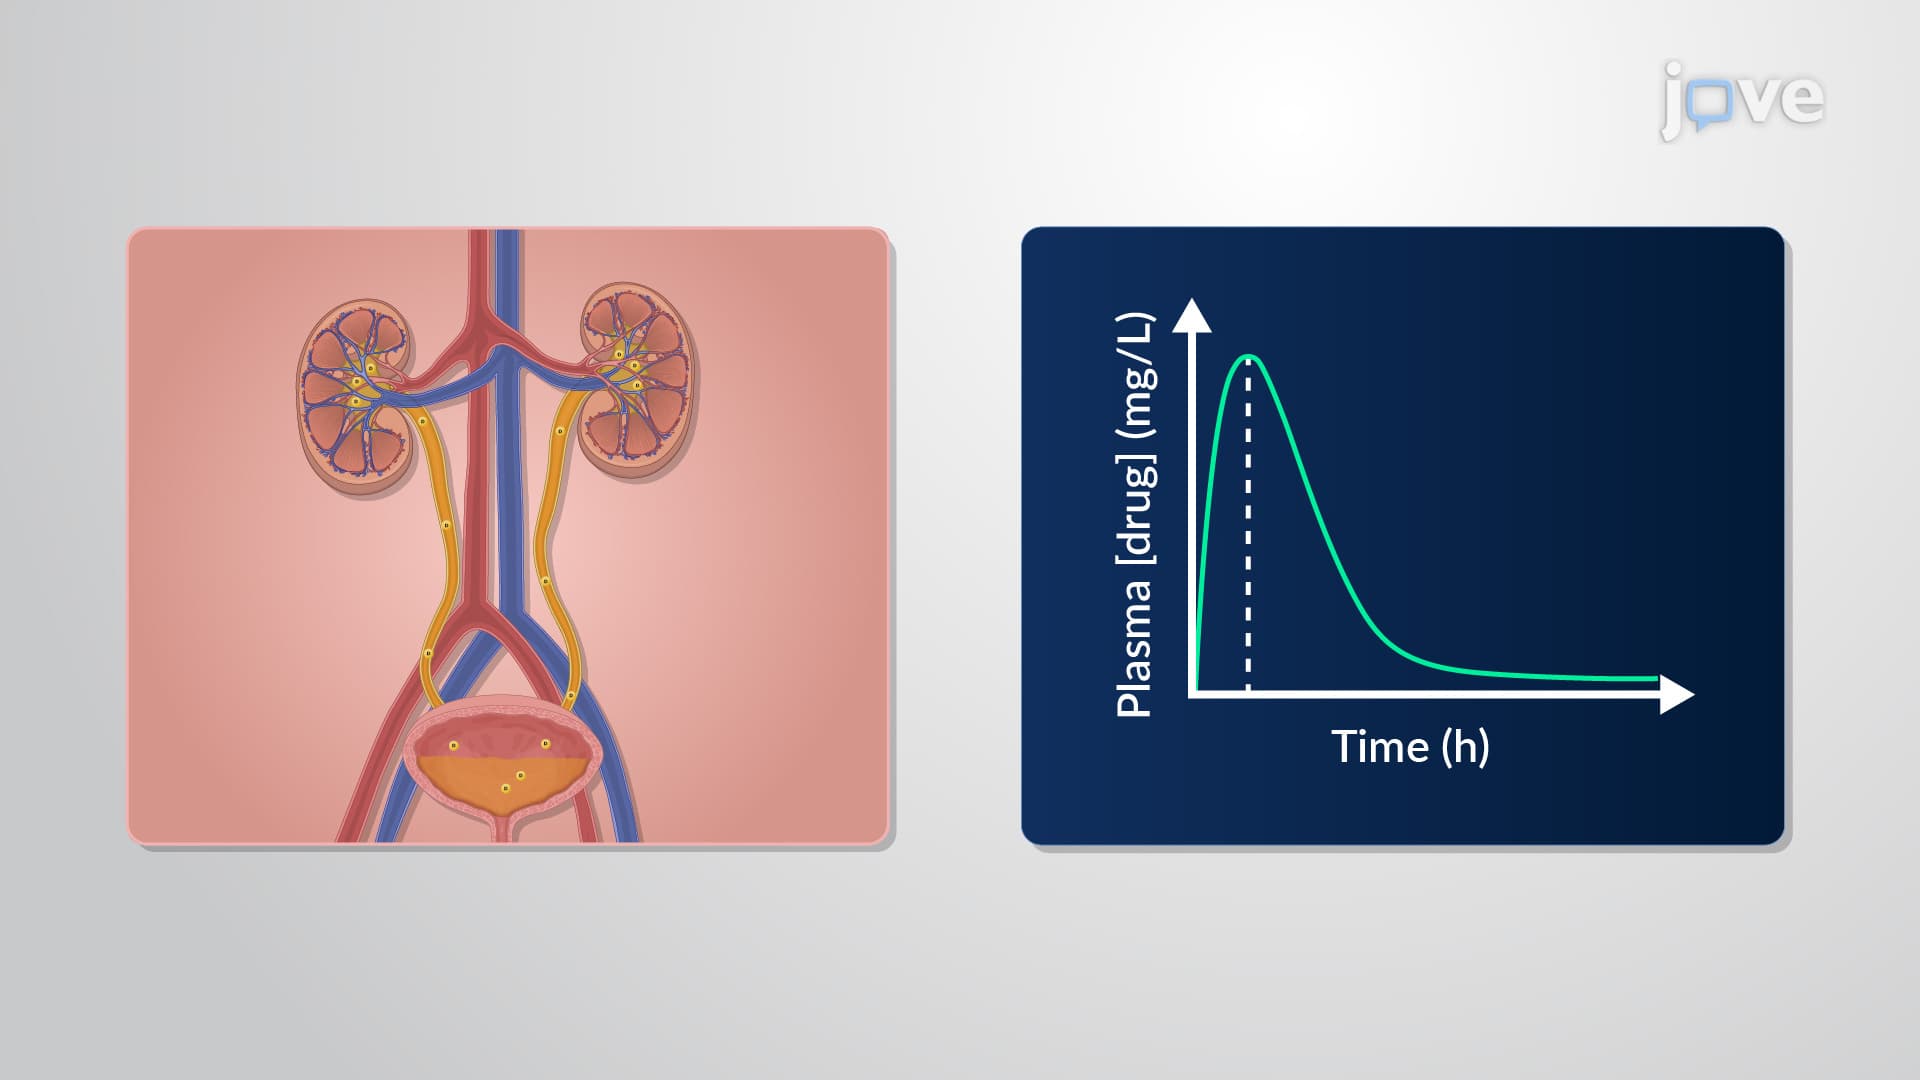
Parameters Affecting Nonlinear Elimination: Zero-Order Input, First-Order Absorption and Two-Compartment Model
When a drug is administered through a constant intravenous infusion and eliminated via nonlinear pharmacokinetics, it follows zero-order input. For example, oral drugs undergo first-order absorption upon administration and are eliminated through nonlinear pharmacokinetics.
In the case of subcutaneously administered drugs,...