An action generation model by using time series prediction and its application to robot navigation
Related Experiment Video
Updated: Feb 7, 2026
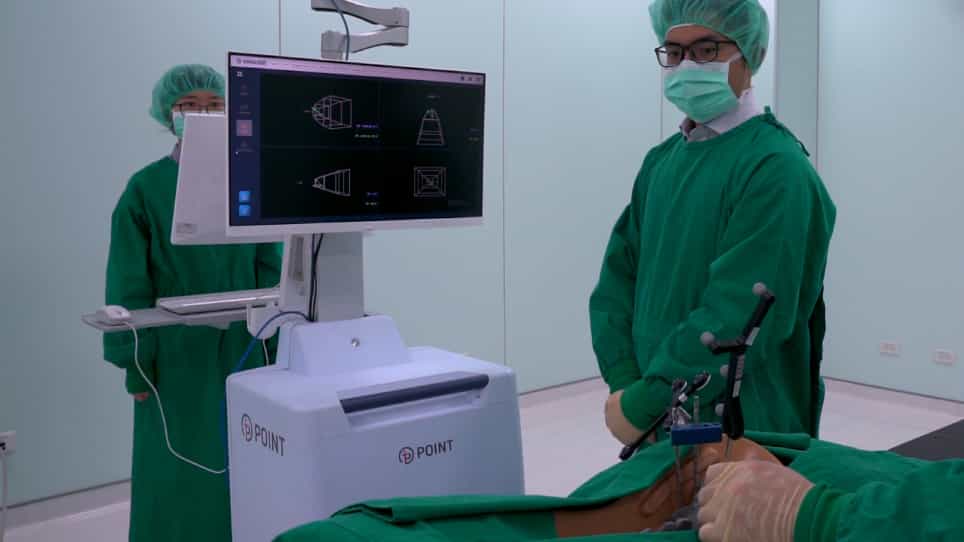
A Spine Robotic-Assisted Navigation System for Pedicle Screw Placement
Published on: May 11, 2020
1Department of Computational Intelligence and Systems Science, Interdisciplinary Graduate School of Science and Engineering, Tokyo Institute of Technology, 4259 Nagatsuta, Midori-ku, Yokohama, 226-8502, Japan. gouko@dis.titech.ac.jp

Abstract:
This paper proposes an action generation model which consists of many motor primitive modules. The motor primitive modules output motor commands based on sensory information. Complicated behavior is generated by sequentially switching the modules. The model also has a prediction unit. This unit predicts which module will be used for current action generation. We have confirmed the effectiveness of the model by applying it to a robot navigation task simulation, and have investigated the influence of the prediction on the action generation.
Related Concept Videos
 01:22
Generation Time
 00:54
Time-Series Graph
 01:20
Discrete-Time Fourier Series
For a discrete-time periodic signal x[n]...
 01:24
Generation of Action Potential in Skeletal Muscles
Like neurons, muscle cells are also regarded as excitable due to their capacity to change in response to stimuli, primarily due to voltage-gated ion channels embedded in their plasma membranes, which get activated by alterations in the...
 02:27
Predicting Molecular Geometry
 01:06
Fixed Action Patterns