Related Experiment Video
Updated: Jun 22, 2026


Closed-loop Neuro-robotic Experiments to Test Computational Properties of Neuronal Networks
Published on: March 2, 2015
Nonlinear system identification based on internal recurrent neural networks
Gheorghe Puscasu1, Bogdan Codres, Alexandru Stancu
1Faculty of Computer Science, "Dunarea de Jos" University of Galaţi, Str. Domneasca No.111, 800211, Romania. gpuscasu@ugal.ro

Abstract:
A novel approach for nonlinear complex system identification based on internal recurrent neural networks (IRNN) is proposed in this paper. The computational complexity of neural identification can be greatly reduced if the whole system is decomposed into several subsystems. This approach employs internal state estimation when no measurements coming from the sensors are available for the system states. A modified backpropagation algorithm is introduced in order to train the IRNN for nonlinear system identification. The performance of the proposed design approach is proven on a car simulator case study.
Related Concept Videos
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:26
Classification of Systems-I
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as:
 01:21
First Order Systems
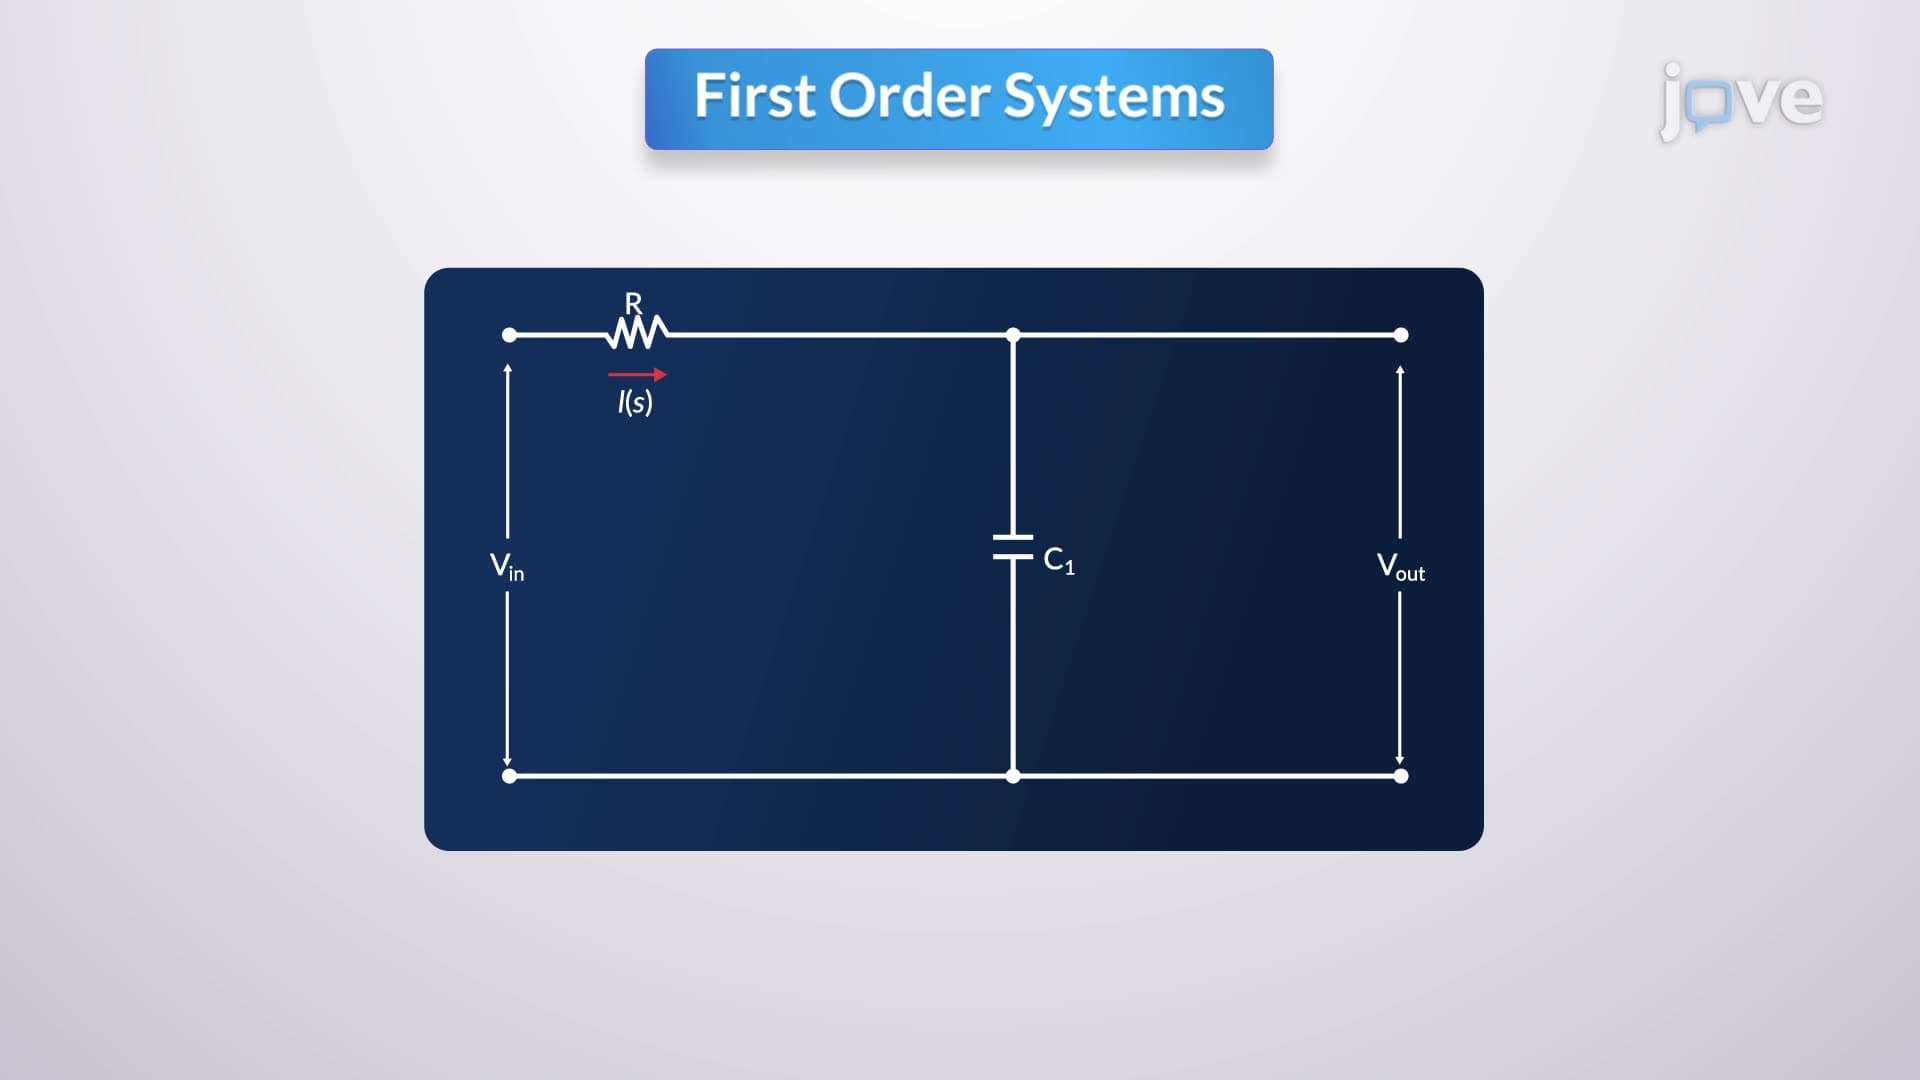
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:31
Classification of Systems-II
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...