Cortical dynamics of navigation and steering in natural scenes: Motion-based object segmentation, heading, and obstacle avoidance
Related Experiment Video
Updated: Jun 22, 2026
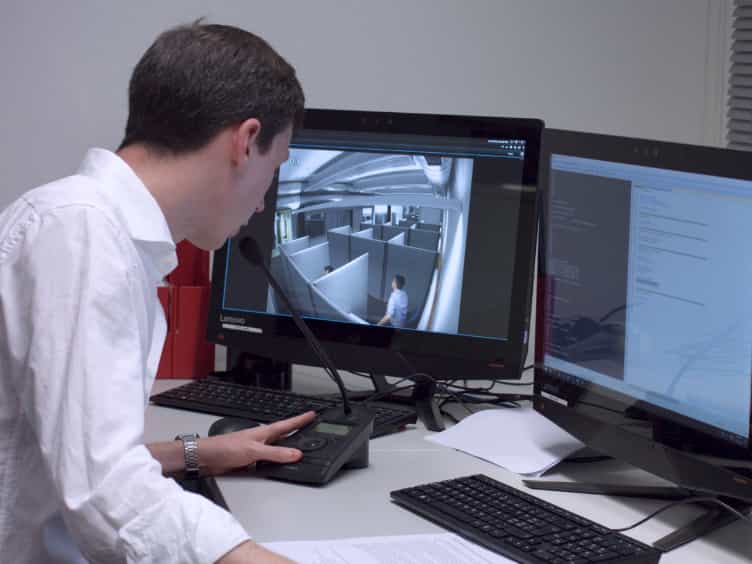
A Networked Desktop Virtual Reality Setup for Decision Science and Navigation Experiments with Multiple Participants
Published on: August 26, 2018
N Andrew Browning1, Stephen Grossberg, Ennio Mingolla
1Department of Cognitive and Neural Systems, Boston University, Boston, MA 02215, USA

Abstract:
Visually guided navigation through a cluttered natural scene is a challenging problem that animals and humans accomplish with ease. The ViSTARS neural model proposes how primates use motion information to segment objects and determine heading for purposes of goal approach and obstacle avoidance in response to video inputs from real and virtual environments. The model produces trajectories similar to those of human navigators. It does so by predicting how computationally complementary processes in cortical areas MT(-)/MSTv and MT(+)/MSTd compute object motion for tracking and self-motion for navigation, respectively. The model's retina responds to transients in the input stream. Model V1 generates a local speed and direction estimate. This local motion estimate is ambiguous due to the neural aperture problem. Model MT(+) interacts with MSTd via an attentive feedback loop to compute accurate heading estimates in MSTd that quantitatively simulate properties of human heading estimation data. Model MT(-) interacts with MSTv via an attentive feedback loop to compute accurate estimates of speed, direction and position of moving objects. This object information is combined with heading information to produce steering decisions wherein goals behave like attractors and obstacles behave like repellers. These steering decisions lead to navigational trajectories that closely match human performance.
Related Concept Videos
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:15
Depth Perception and Spatial Vision
 01:29
Real-World Applications of Space Curves
 01:30
Vector Functions and Motion: Problem Solving
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...