Related Experiment Video
Updated: Jun 22, 2026


Age-dependent Dynamics of Locomotion in Caenorhabditis elegans: A Lyapunov Exponent Analysis
Published on: September 23, 2025
Relativistic invariance of Lyapunov exponents in bounded and unbounded systems
Adilson E Motter1, Alberto Saa
1Department of Physics, Northwestern University, Evanston, Illinois 60208, USA.

Abstract:
The study of chaos in relativistic systems has been hampered by the observer dependence of Lyapunov exponents (LEs) and of conditions, such as orbit boundedness, invoked in the interpretation of LEs as indicators of chaos. Here we establish a general framework that overcomes both difficulties and apply the resulting approach to address three fundamental questions: how LEs transform under Lorentz and Rindler transformations and under transformations to uniformly rotating frames. The answers to the first and third questions show that inertial and uniformly rotating observers agree on a characterization of chaos based on LEs. The second question, on the other hand, is an ill-posed problem due to the event horizons inherent to uniformly accelerated observers.
Related Concept Videos
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system.
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:26
Classification of Systems-I
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as:
 01:28
Stability
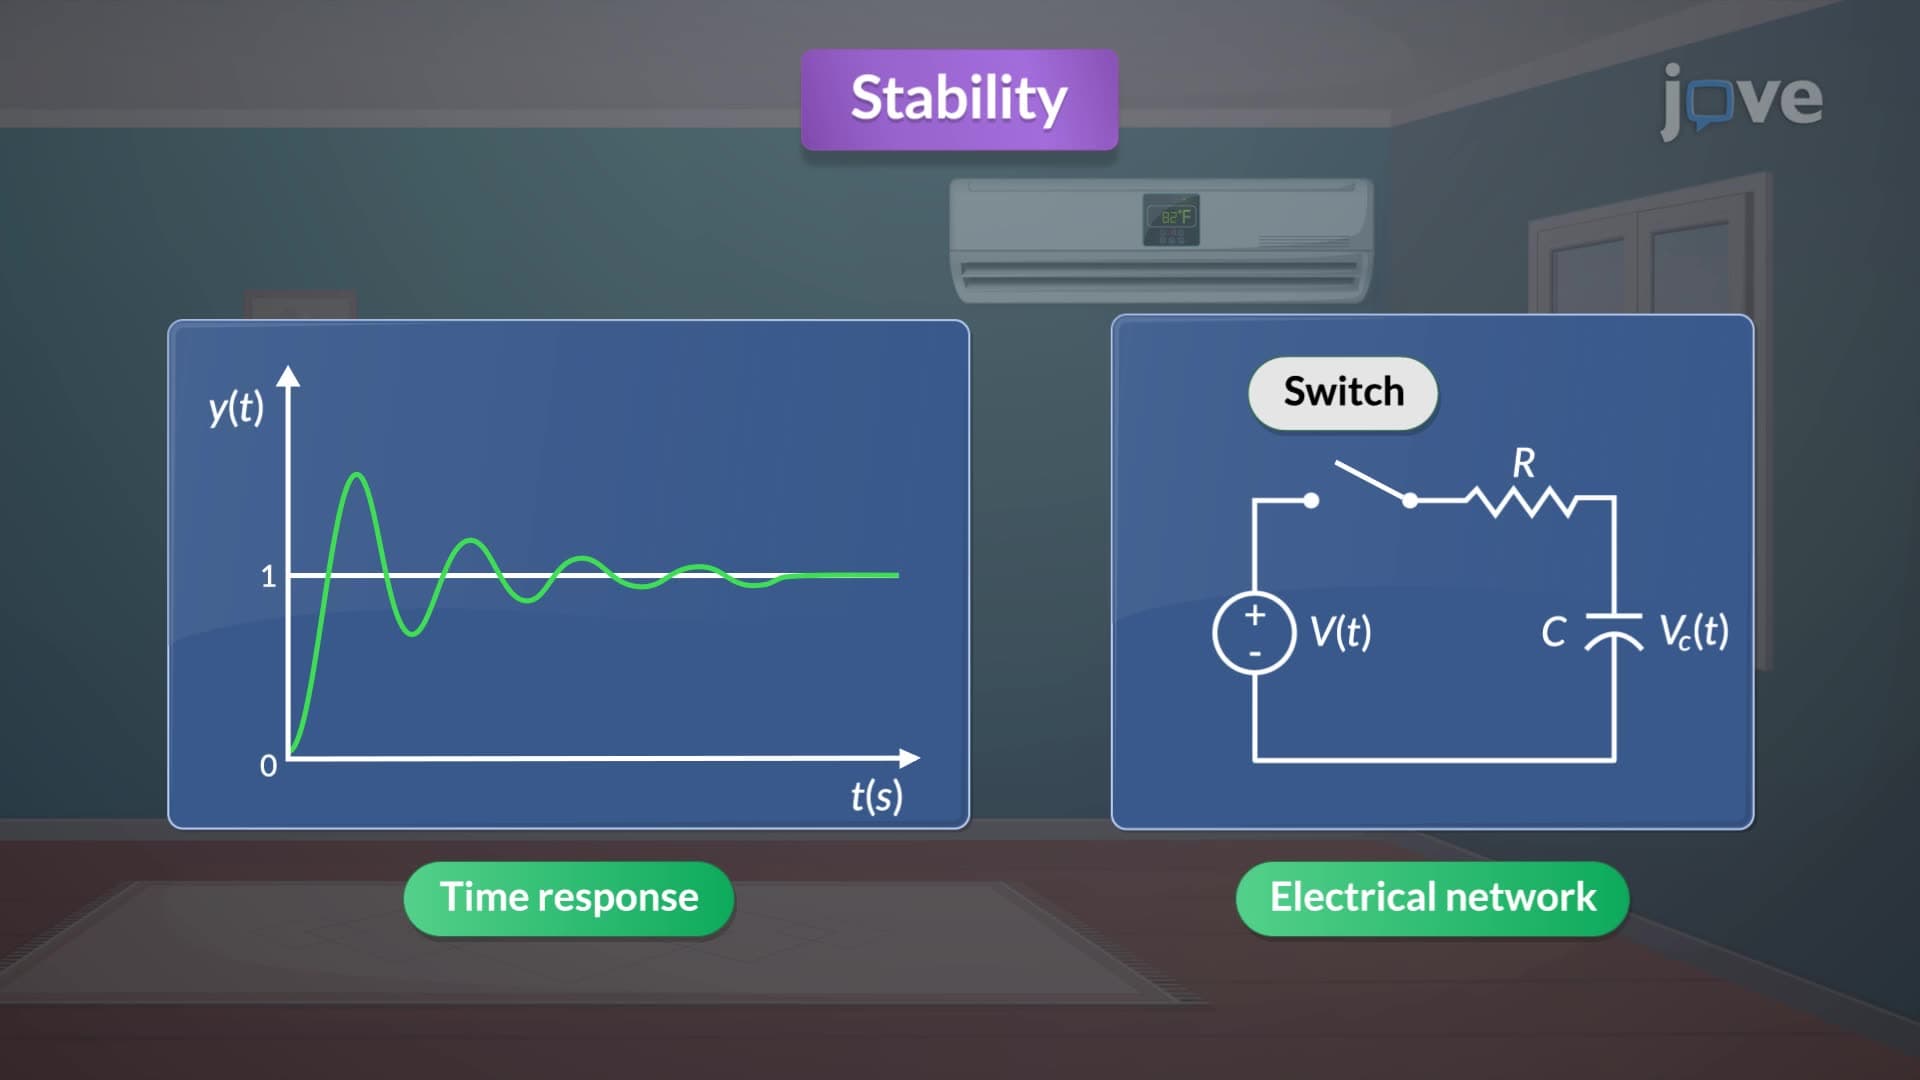
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:31
Classification of Systems-II