Perceiving motion transparency in the absence of component direction differences
Related Experiment Video
Updated: Jun 22, 2026

Motion-Acuity Test for Visual Field Acuity Measurement with Motion-Defined Shapes
Published on: February 23, 2024
Andrew Isaac Meso1, Johannes M Zanker
1Computational Vision Lab, Department of Psychology, Royal Holloway University of London, Egham TW20 0EX, United Kingdom. andrew.meso@mcgill.ca

Abstract:
The simultaneous perception of multiple motion components within the same region in the visual field is a difficult processing task, which can be solved by human observers for a range of transparently moving stimuli. We use transparently moving gratings to study this phenomenon psychophysically, focussing on configurations in which individual components move in the same direction and can only be discriminated by speed differences. We first demonstrate that the stimuli are perceived as transparent and then proceed to quantify how the strength of motion transparency changes while component grating parameters such as fundamental spatial frequency, speed and luminance are varied. The results were consistent with perception resolving a signal detection task of separating two superimposed global motion signals corresponding to each of the components. We also identify the importance of broadband stimuli containing edges, both for perceiving transparency with the same direction stimulus configuration, and for static transparency. The local density of edges has a direct influence on the strength of perceived transparency, suggesting that local motion detection at the edges of the stimuli, which is sensitive to speed differences, may be critical to solve the task. The work suggests that there may be a simultaneous retinotopic representation of the two speeds of motion analogous to that accomplished by the motion direction tuned neurons found across regions of visual cortex.

Related Concept Videos
 01:15
Depth Perception and Spatial Vision
 01:27
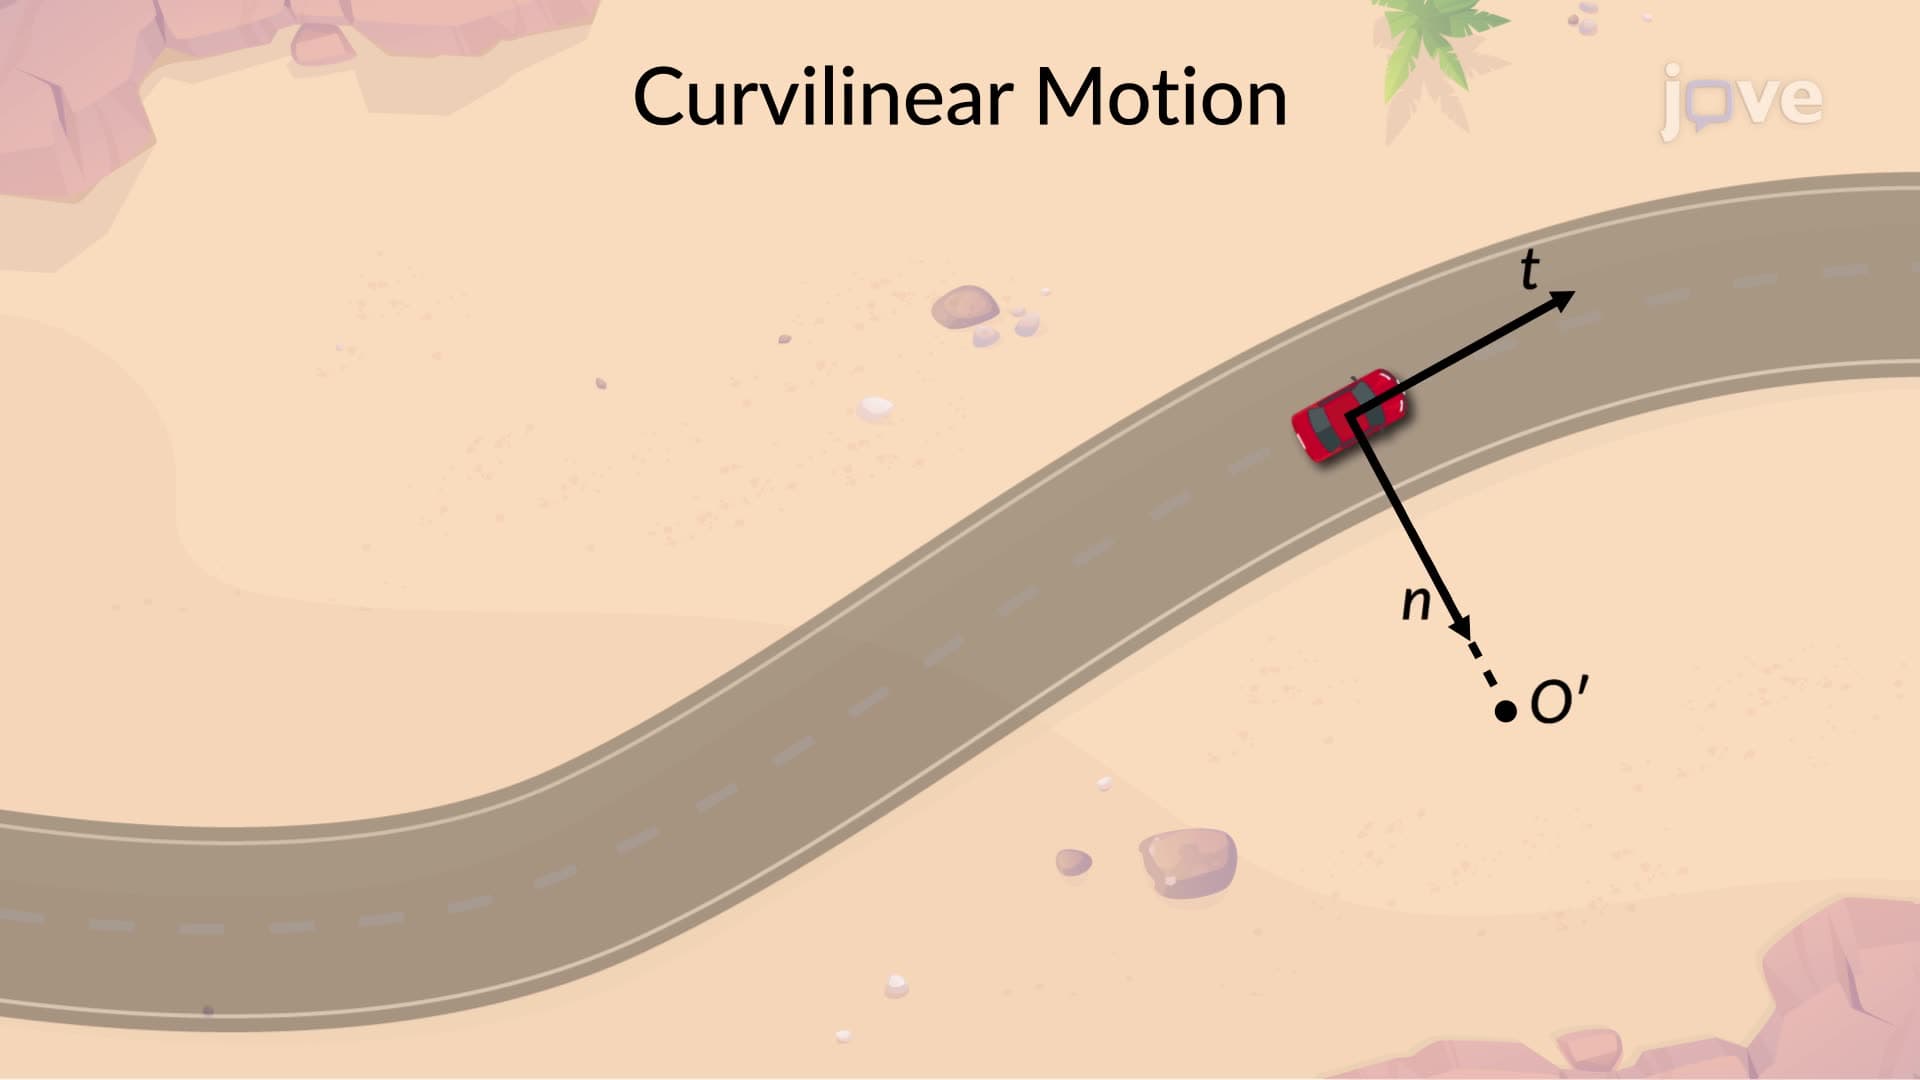
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:24
Relative Motion Analysis - Velocity
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
 01:10
Relative Motion Analysis - Acceleration