Neural-genetic synthesis for state-space controllers based on linear quadratic regulator design for eigenstructure assignment
Related Experiment Video
Updated: Jun 21, 2026

The Modular Design and Production of an Intelligent Robot Based on a Closed-Loop Control Strategy
Published on: October 14, 2017
João Viana da Fonseca Neto1, Ivanildo Silva Abreu, Fábio Nogueira da Silva
1Department of Electrical Engineering and the Postgraduation Program in Electrical Engineering andComputation, Federal University of Maranhão, São Luís, MA 65080-040, Brazil. jviana@dee.ufma.br

Abstract:
Toward the synthesis of state-space controllers, a neural-genetic model based on the linear quadratic regulator design for the eigenstructure assignment of multivariable dynamic systems is presented. The neural-genetic model represents a fusion of a genetic algorithm and a recurrent neural network (RNN) to perform the selection of the weighting matrices and the algebraic Riccati equation solution, respectively. A fourth-order electric circuit model is used to evaluate the convergence of the computational intelligence paradigms and the control design method performance. The genetic search convergence evaluation is performed in terms of the fitness function statistics and the RNN convergence, which is evaluated by landscapes of the energy and norm, as a function of the parameter deviations. The control problem solution is evaluated in the time and frequency domains by the impulse response, singular values, and modal analysis.
Related Concept Videos
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:21
State Space to Transfer Function
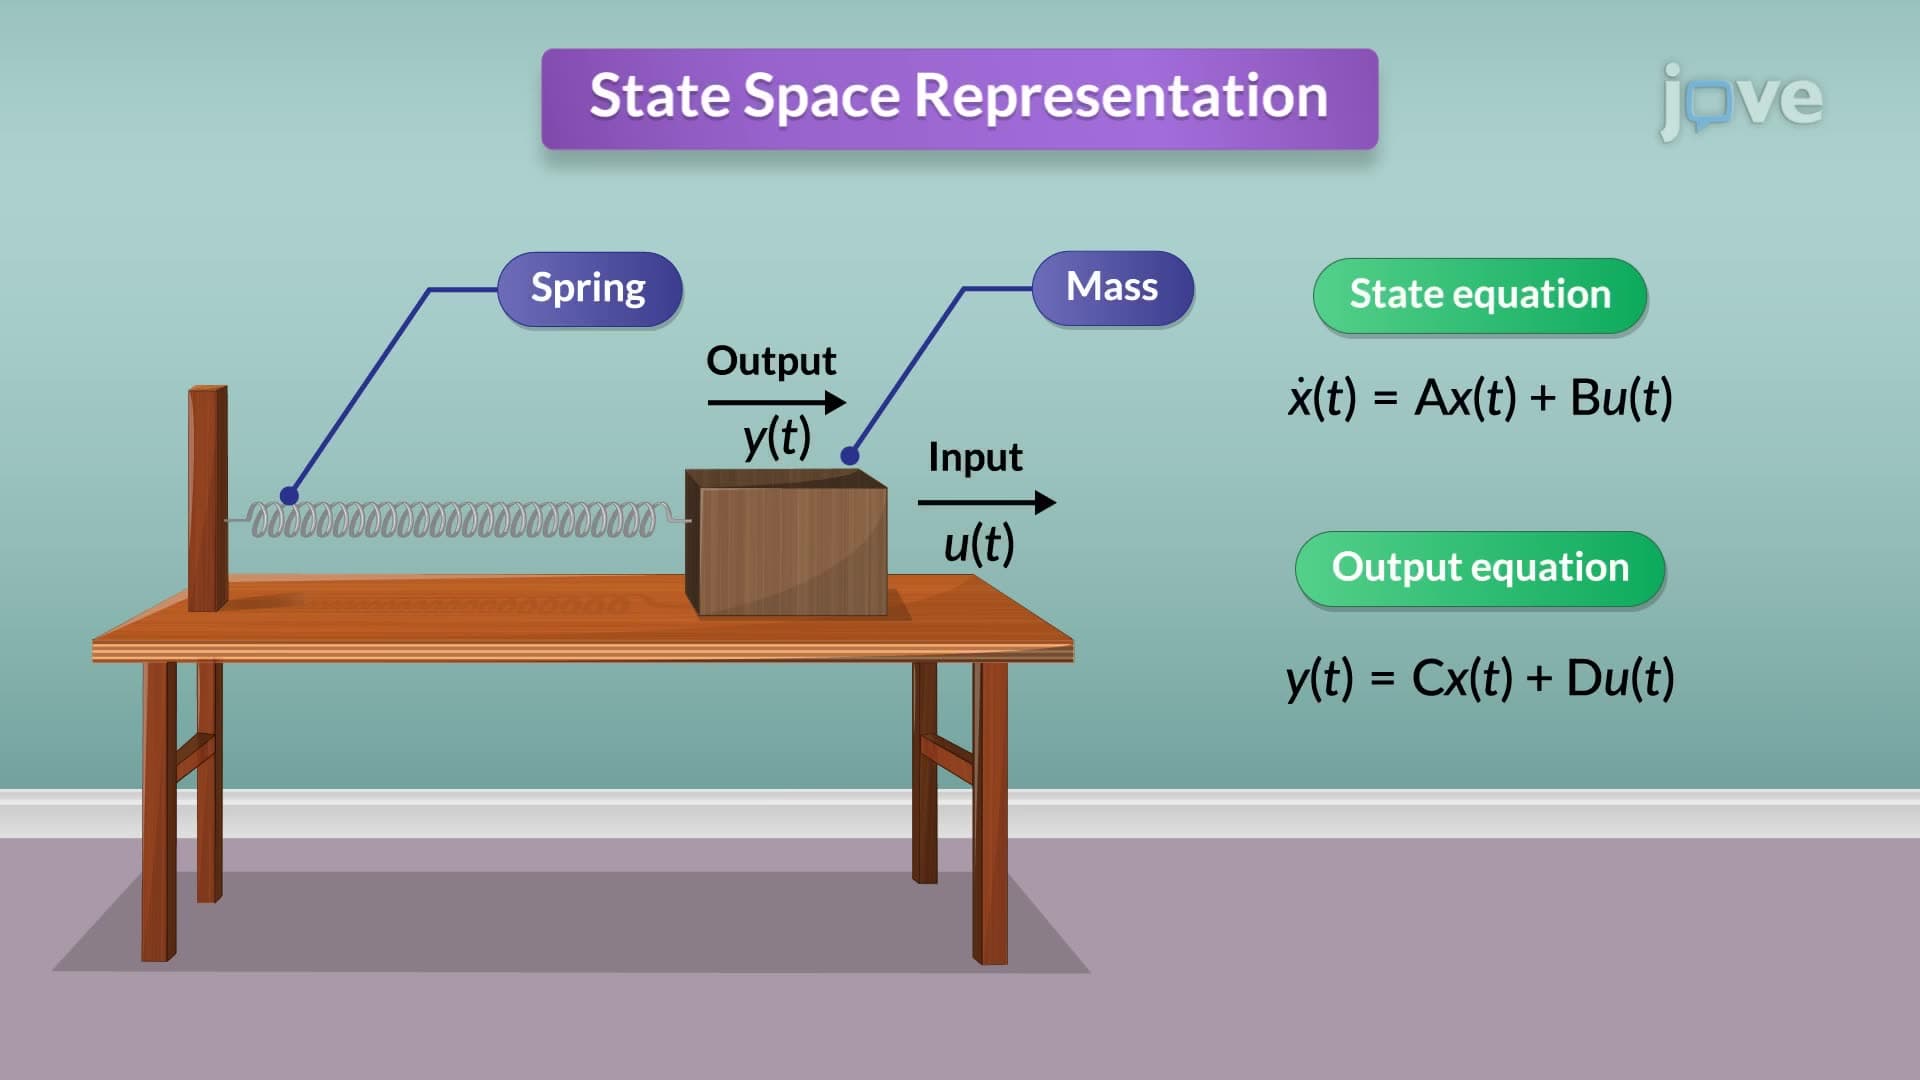
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:23
Transfer Function to State Space
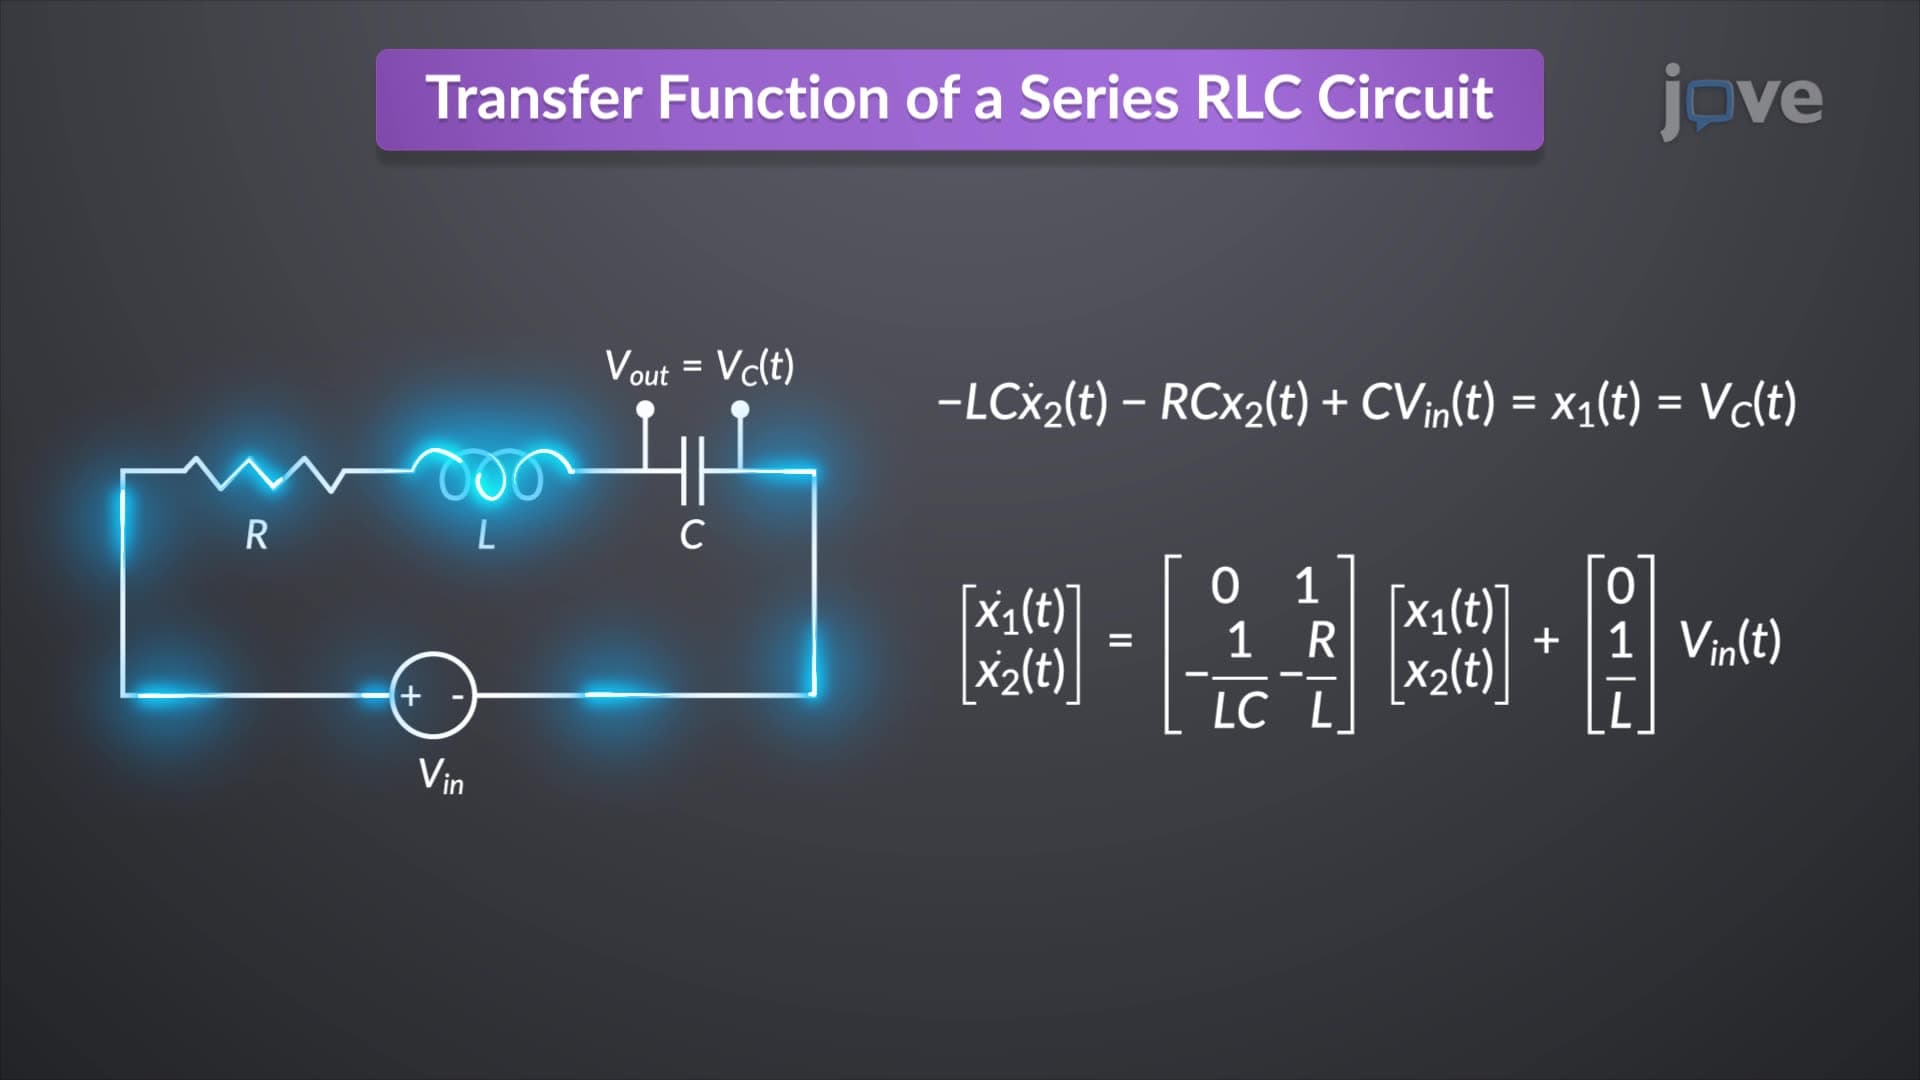
In an RLC...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...