Myoelectric hand prosthesis force control through servo motor current feedback
Related Experiment Video
Updated: Jun 21, 2026
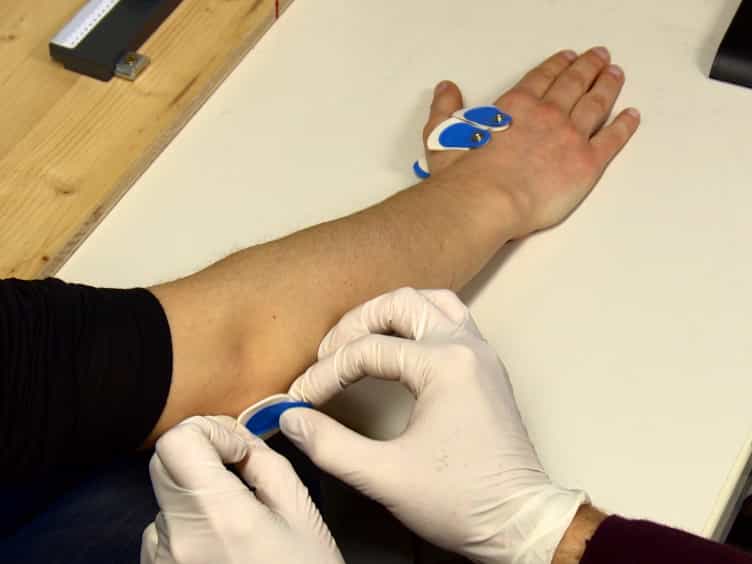
Force and Position Control in Humans - The Role of Augmented Feedback
Published on: June 19, 2016
Tálita Saemi Payossim Sono1, Luciano Luporini Menegaldo
1Mechanical Engineering Department, Federal University of Minas Gerais, Belo Horizonte, MG, Brazil.

Abstract:
This paper presents the prehension force closed-loop control design of a mechanical finger commanded by electromyographic signal (EMG) from a patient's arm. The control scheme was implemented and tested in a mechanical finger prototype with three degrees of freedom and one actuator, driven by arm muscles EMG of normal volunteers. Real-time indirect estimation of prehension force was assessed by measuring the DC servo motor actuator current. A model of the plant comprising finger, motor, and grasped object was proposed. Model parameters were identified experimentally and a classical feedback phase-lead compensator was designed. The controlled mechanical finger was able to provide a more accurate prehension force modulation of a compliant object when compared to open-loop control.

Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:20
Motor Unit Stimulation
The latent period of contraction marks the onset of excitation-contraction coupling, when the action potential propagates across the sarcolemma, preparing the muscle fibers for contraction. As the fibers enter the contraction phase, the...
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
 01:19
PID Controller