Related Experiment Video
Updated: Jun 19, 2026

Age-dependent Dynamics of Locomotion in Caenorhabditis elegans: A Lyapunov Exponent Analysis
Published on: September 23, 2025
Phase space method for identification of driven nonlinear systems
1U.S. Naval Research Laboratory, Washington, DC 20375, USA. thomas.l.carroll@nrl.navy.mil

Abstract:
We seek in this paper to differentiate driven nonlinear systems using only a single output signal from the driven system. We do not have access to the driving signal. We demonstrate the phase space identification techniques with an experimental model of a radio transmitter. We restrict the driving signals to nearly periodic signals, because these types of signals are the most common signals used in real transmitters. We find that by studying our transmitter as a driven nonlinear system, we are able to distinguish one transmitter from another. This work may have consequences for real transmitters.

Related Concept Videos
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:23
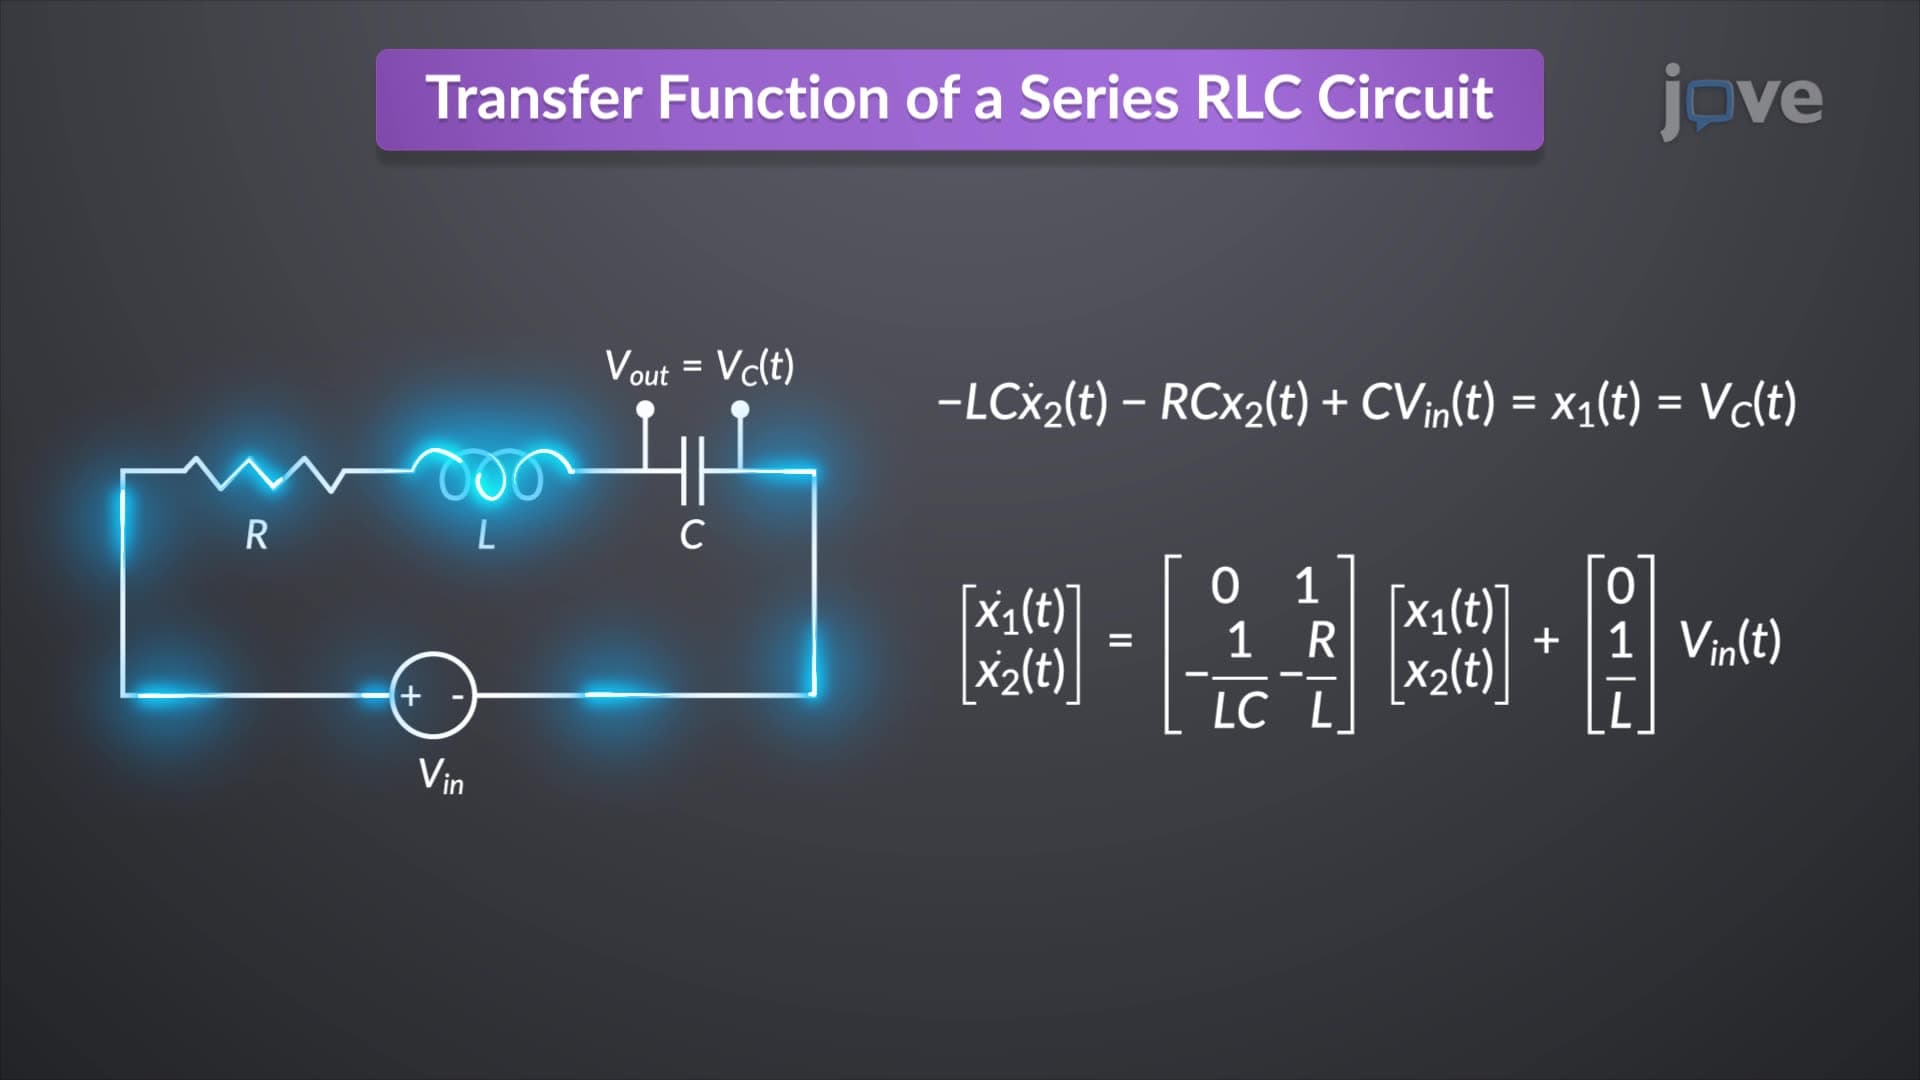
Transfer Function to State Space
In an RLC...
 01:21
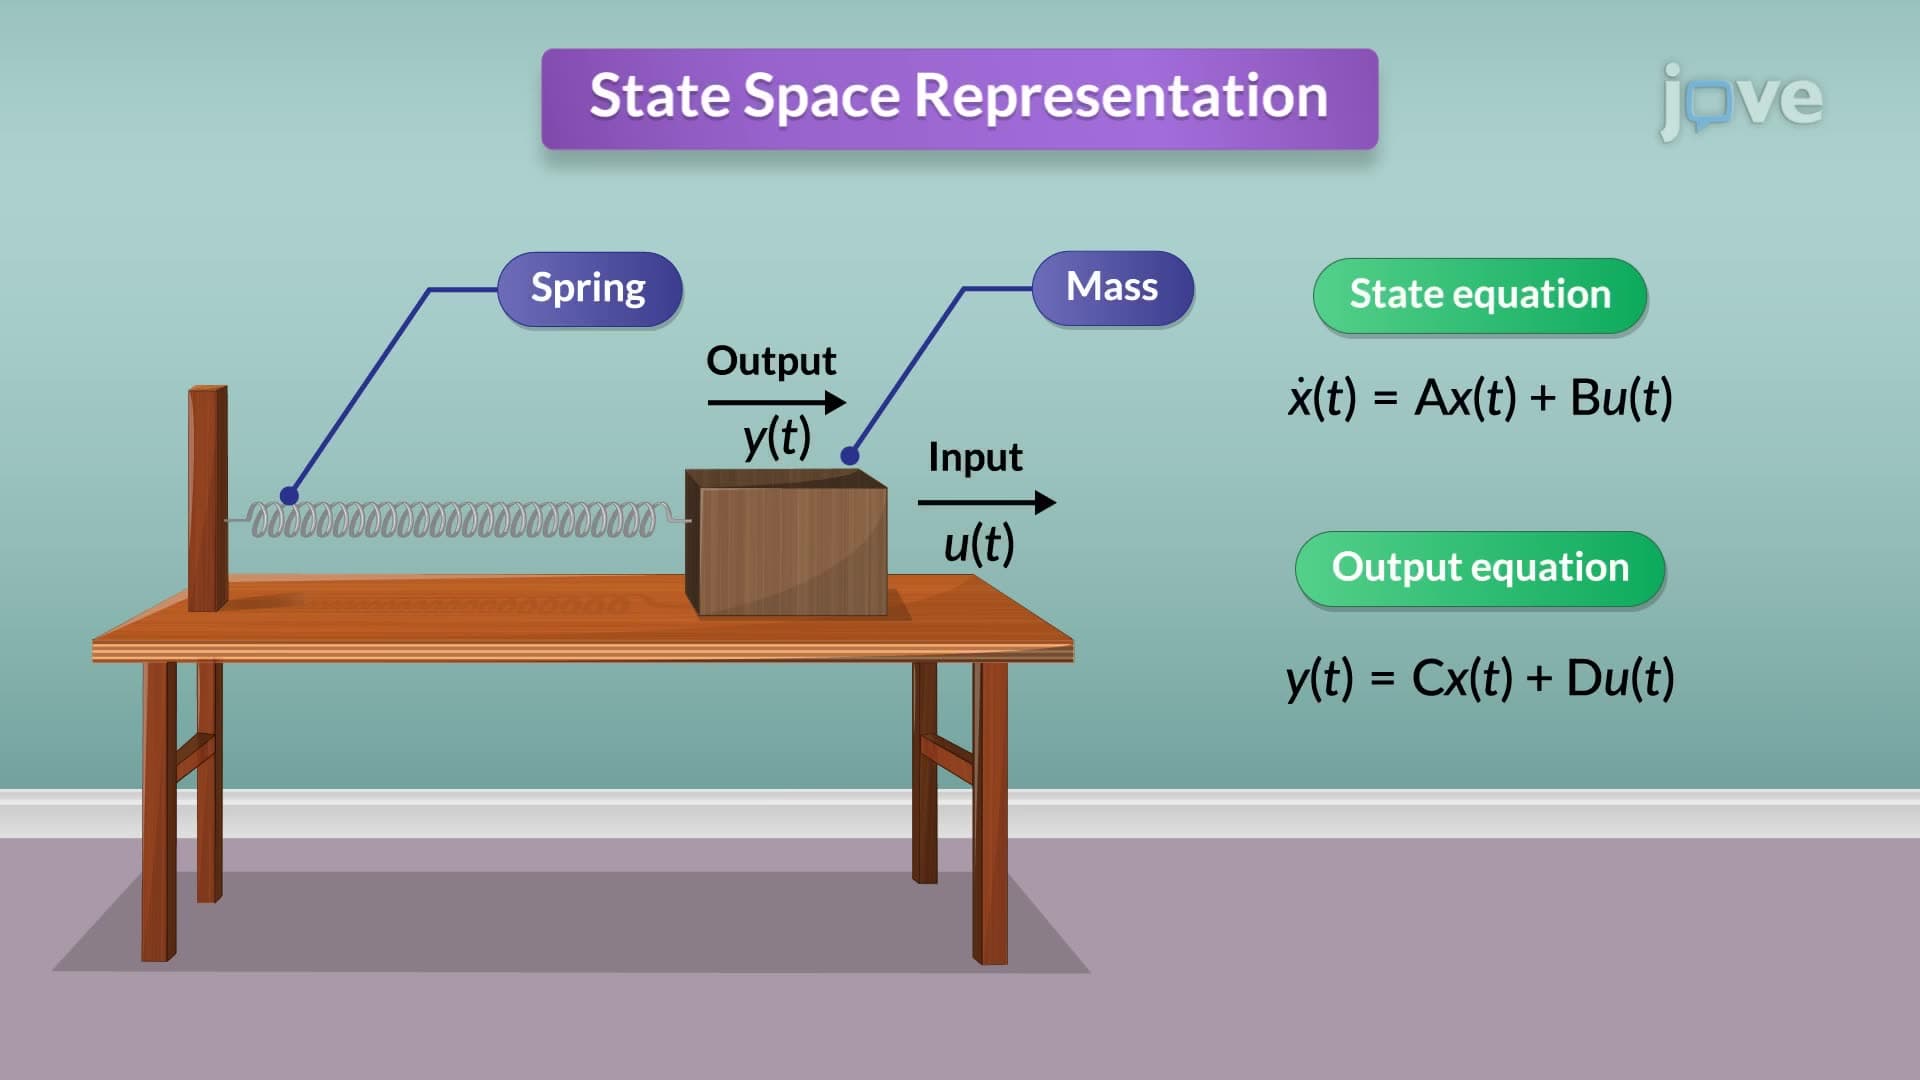
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:21
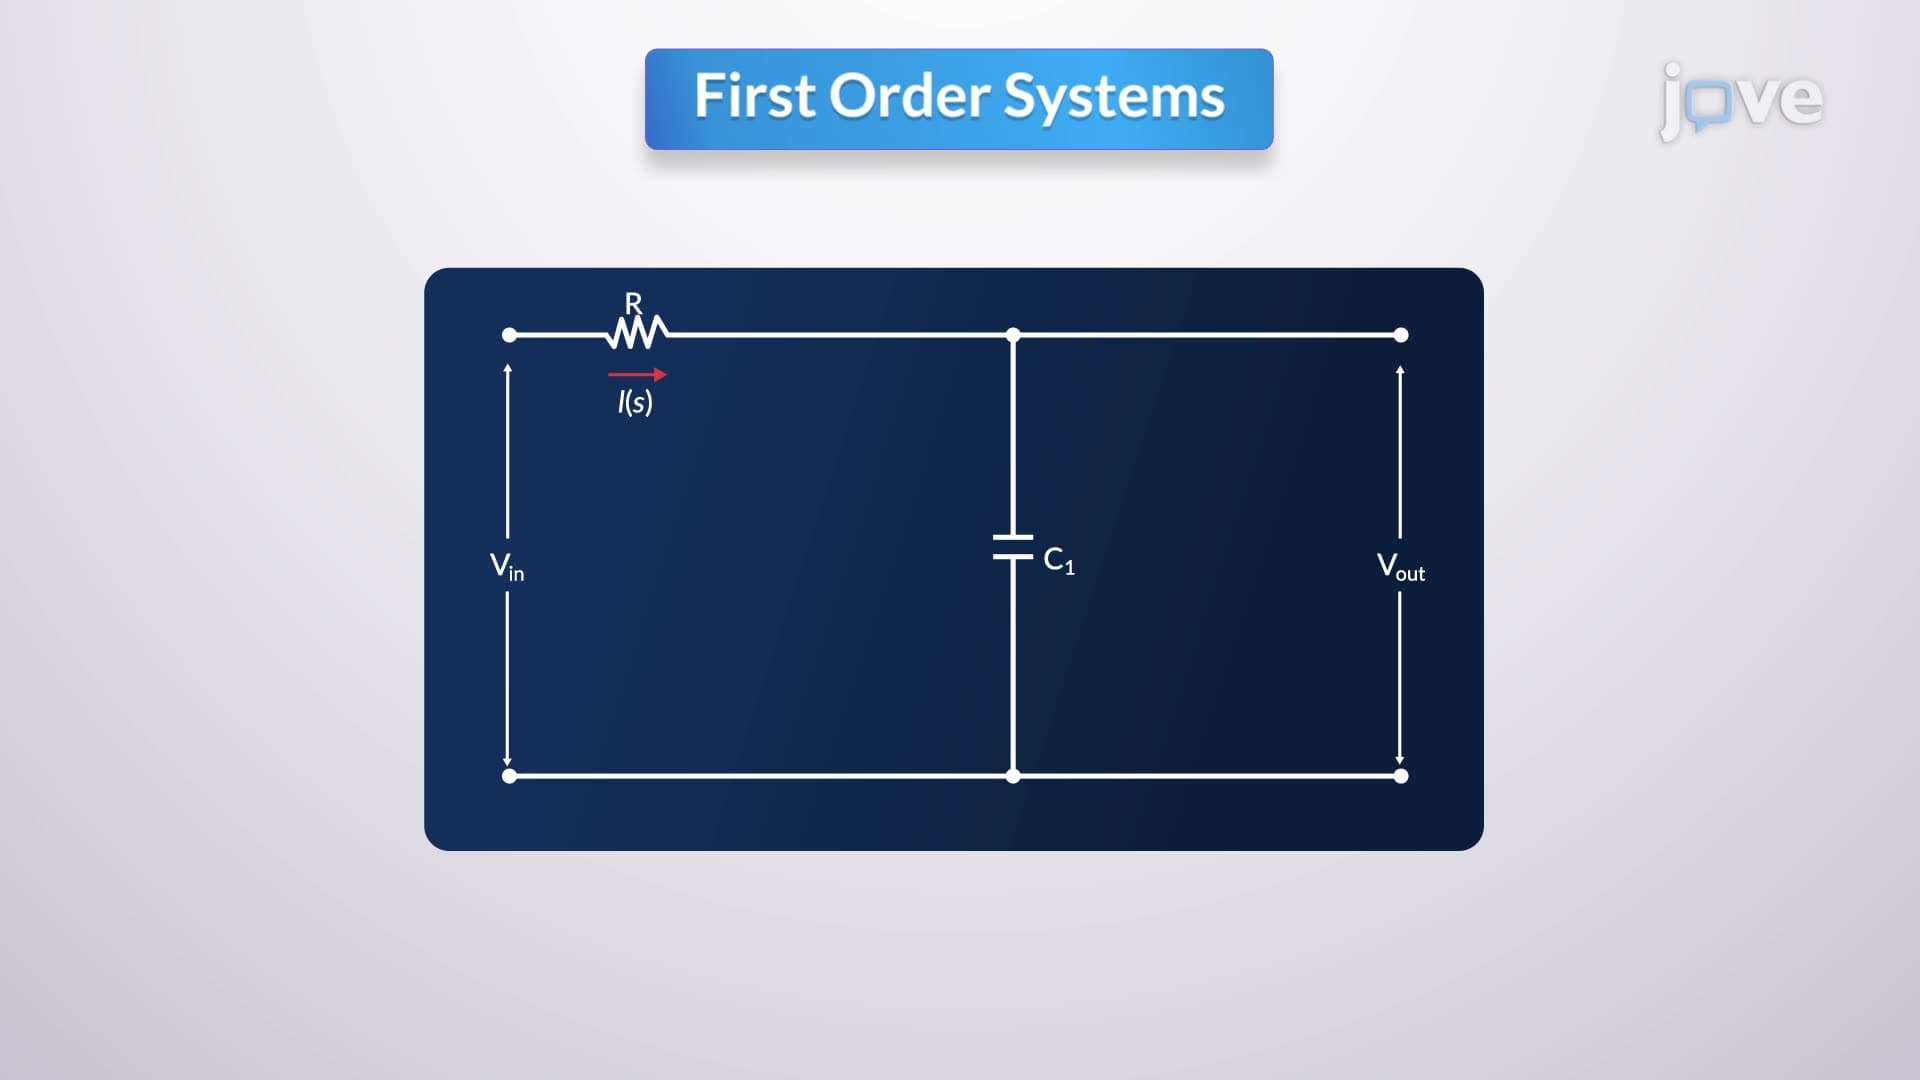
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...