Related Experiment Video
Updated: Jun 19, 2026
06:37

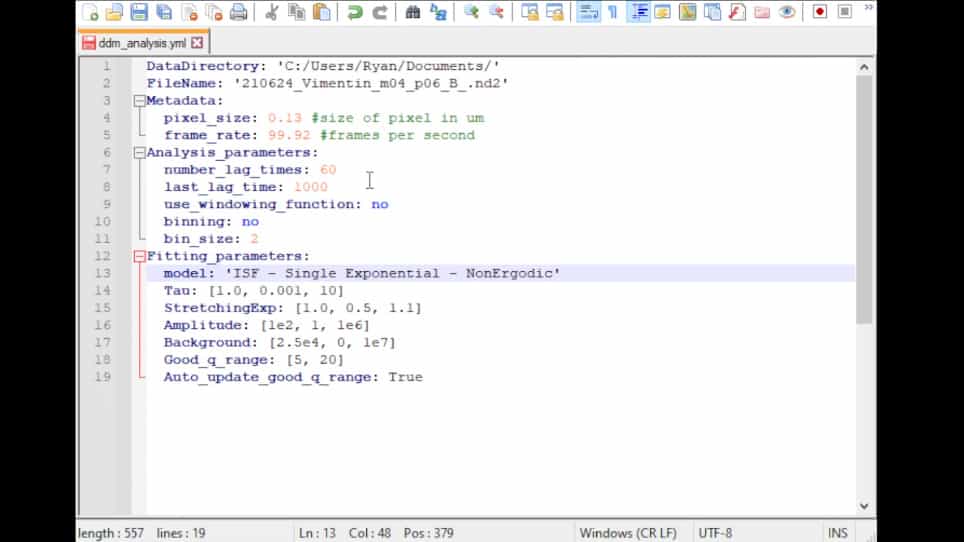
Quantifying Cytoskeleton Dynamics Using Differential Dynamic Microscopy
Published on: June 15, 2022

Abstract:
We demonstrate that, using a hologram, we can convert a spatial x-y image into an x-t image, where one spatial dimension is now transformed into the time domain. In particular, we generate the temporal equivalent of our corporate logo, where every pixel of the image is now represented by a short optical pulse.
Related Concept Videos
 01:11
Continuous -time Fourier Transform
The Fourier series is instrumental in representing periodic functions, offering a powerful method to decompose such functions into a sum of sinusoids. This technique, however, necessitates modification when applied to nonperiodic functions. Consider a pulse-train waveform consisting of a series of rectangular pulses. When these pulses have a finite period, they can be accurately represented by a Fourier series. Yet, as the period approaches infinity, resulting in a single, isolated pulse, the...
 01:24
Properties of DTFT I
In signal processing, Discrete-Time Fourier Transforms (DTFTs) play a critical role in analyzing discrete-time signals in the frequency domain. Various properties of the DTFTs such as linearity, time-shifting, frequency-shifting, time reversal, conjugation, and time scaling help understand and manipulate these signals for different applications.
The linearity property of DTFTs is fundamental. If two discrete-time signals are multiplied by constants a and b respectively, and then combined to...
The linearity property of DTFTs is fundamental. If two discrete-time signals are multiplied by constants a and b respectively, and then combined to...
 01:27
Time and frequency -Domain Interpretation of PI Control
Proportional-Integral (PI) controllers are essential in many control systems to improve stability and performance. They are commonly used in everyday devices like thermostats to enhance system damping and reduce steady-state error. When the zero in the controller's transfer function is optimally placed, the system benefits significantly in terms of stability and accuracy.
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires careful...
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires careful...
 01:07
Time-Domain Interpretation of PD Control
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
 01:26
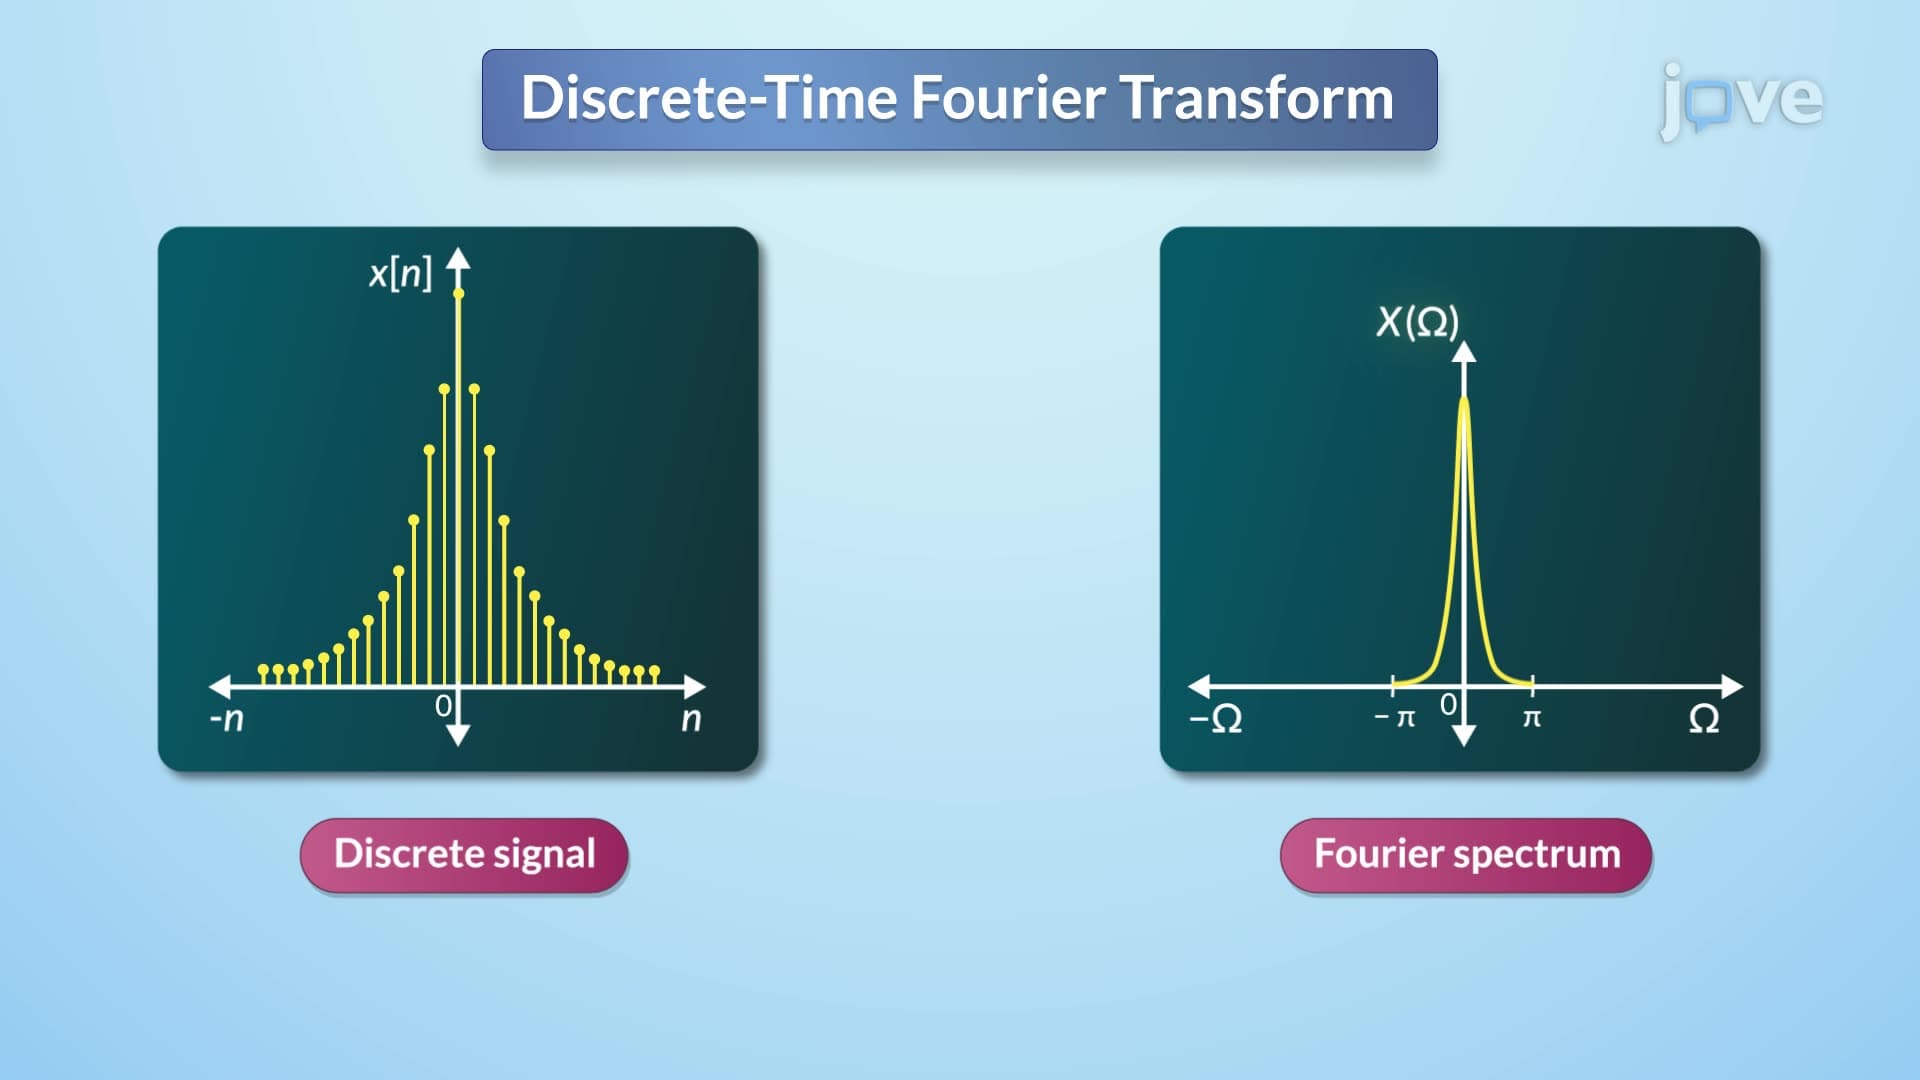
Discrete-time Fourier transform
The Discrete-Time Fourier Transform (DTFT) is an essential mathematical tool for analyzing discrete-time signals, converting them from the time domain to the frequency domain. This transformation allows for examining the frequency components of discrete signals, providing insights into their spectral characteristics. In the DTFT, the continuous integral used in the continuous-time Fourier transform is replaced by a summation to accommodate the discrete nature of the signal.
One of the notable...
One of the notable...
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers are widely used in control systems to improve stability and reduce steady-state errors. A dimmer switch controlling the brightness of a light bulb serves as a practical example of phase-lag control, gradually adjusting the bulb's brightness. Mathematically, phase-lag control or low-pass filtering is represented when the factor 'a' is less than 1.
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any finite,...
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any finite,...