Computational design and multiscale modeling of a nanoactuator using DNA actuation
Related Experiment Video
Updated: Jun 19, 2026
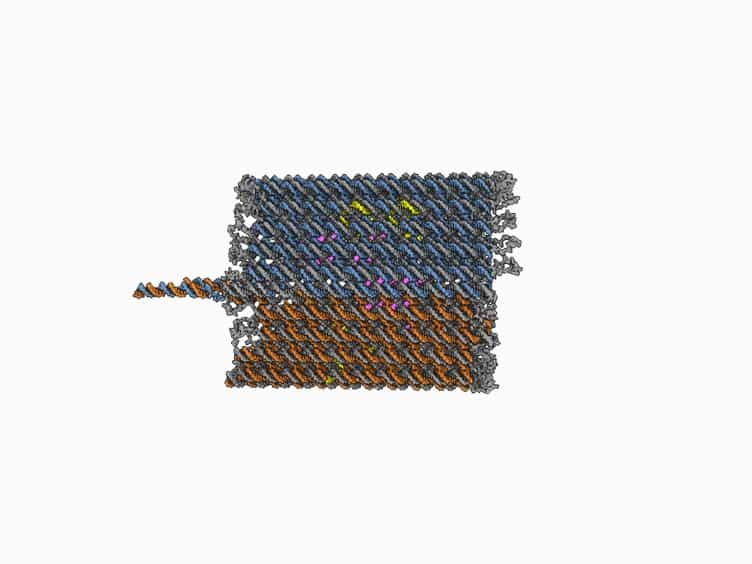
Designing a Bio-responsive Robot from DNA Origami
Published on: July 8, 2013
1INRIA MICMAC, Ecole Nationale des Ponts et Chaussees, 6 and 8 avenue Blaise Pascal, Cite Descartes, Champs-sur-Marne, 77455 Marne La Vallee Cedex 2, France. hamdim@cermics.enpc.fr

Abstract:
Developments in the field of nanobiodevices coupling nanostructures and biological components are of great interest in medical nanorobotics. As the fundamentals of bio/non-bio interaction processes are still poorly understood in the design of these devices, design tools and multiscale dynamics modeling approaches are necessary at the fabrication pre-project stage. This paper proposes a new concept of optimized carbon nanotube based servomotor design for drug delivery and biomolecular transport applications. The design of an encapsulated DNA-multi-walled carbon nanotube actuator is prototyped using multiscale modeling. The system is parametrized by using a quantum level approach and characterized by using a molecular dynamics simulation. Based on the analysis of the simulation results, a servo nanoactuator using ionic current feedback is simulated and analyzed for application as a drug delivery carrier.