Related Experiment Video
Updated: Jun 18, 2026

Single-Port Robotic-assisted Transaxillary Breast-conserving Surgery: A Prospective, Single-arm, Non-randomized Phase IIa Clinical Trial
Published on: August 19, 2025
Three-dimensional ultrasound guidance of autonomous robotic breast biopsy: feasibility study
Kaicheng Liang1, Albert J Rogers, Edward D Light
1Department of Biomedical Engineering, Duke University, Durham, NC, USA. kaicheng.liang@duke.edu

Abstract:
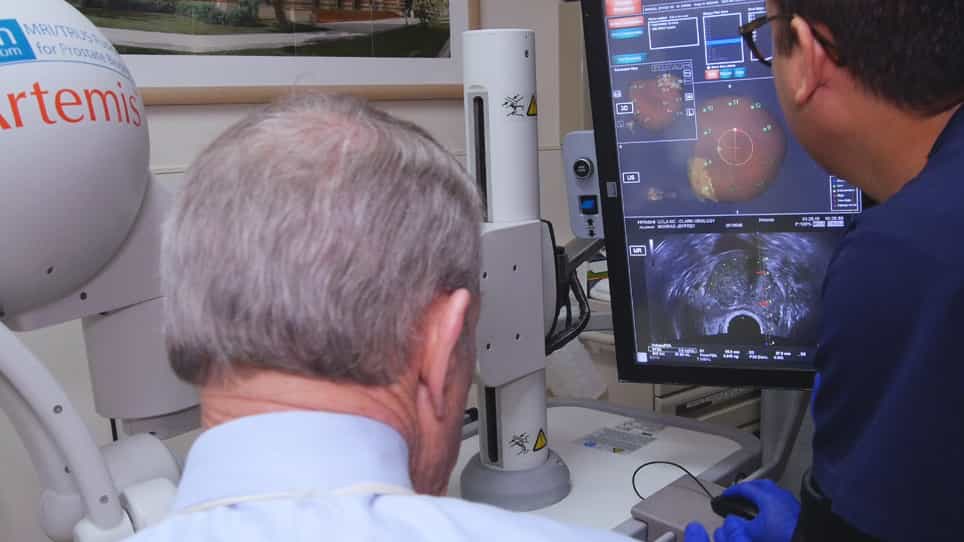
Feasibility studies of autonomous robot biopsies in tissue have been conducted using real-time three-dimensional (3-D) ultrasound combined with simple thresholding algorithms. The robot first autonomously processed 3-D image volumes received from the ultrasound scanner to locate a metal rod target embedded in turkey breast tissue simulating a calcification, and in a separate experiment, the center of a water-filled void in the breast tissue simulating a cyst. In both experiments the robot then directed a needle to the desired target, with no user input required. Separate needle-touch experiments performed by the image-guided robot in a water tank yielded an rms error of 1.15 mm. (E-mail: kaicheng.liang@duke.edu).