The kinematics of load carrying in humans and great apes: implications for the evolution of human bipedalism
J Watson1, R Payne, A Chamberlain
1University of Manchester, Oxford Road, Manchester, UK.

Abstract:
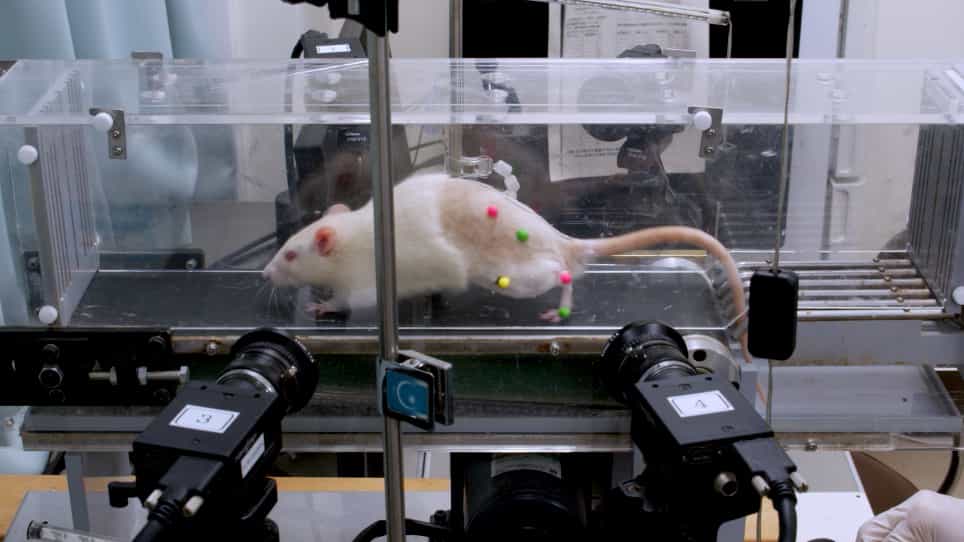
We present a comparison of loaded and unloaded carrying kinematics in humans, common chimpanzees (Pan troglodytes), bonobos (Pan paniscus), western lowland gorillas (Gorilla gorilla gorilla) and Bornean and Sumatran orang-utans (Pongo pygmaeus and Pongo abelii). Human hindlimb joint and segment angles were collected during treadmill locomotion using infrared motion analysis cameras. Non-human primate fore- and hindlimb joint and segment angles were collected at zoos during free-ranging locomotion using a standard video camera. In quadrupedal locomotion there were small but potentially important changes associated with load carriage leading to a more upright trunk and a shift in shoulder excursion. These changes were exacerbated as locomotion shifts from quadrupedal to tripedal and bipedal gaits when carrying more awkward loads suggesting a possible adaptive sequence. However, food carrying may favour a highly flexed bent-hip bent-knee bipedal gait since it allows simultaneous foraging and hoarding. In bipedal humans no changes in limb kinematics were seen associated with type of load, although asymmetric loads may lead to lateral postural shifts. Carrying may therefore be an important component of the evolutionary shift to habitual bipedalism, although further work is needed to understand the full biomechanical implications.
Related Concept Videos
 01:16
Bones of the Lower Limb: Femur and Patella
 00:58
Introduction to Joints
 01:29
Load along a Single Axis
Consider a beam of length L subjected to a varying load, which is a combination of parabolic and trapezoidal load distribution along the x-axis. In this case, it is essential to determine the resultant loads, their locations, and...
 01:10
Relative Motion Analysis - Acceleration