Related Experiment Videos
Fast algorithm for Walsh Hadamard Transform on sliding windows
1Department of Electronic Engineering, The Chinese University of Hong Kong, Ho Sin Hang Engineering Building, Hong Kong, Shatin, NT, Hong Kong. wlouyang@ee.cuhk.edu.hk
IEEE Transactions on Pattern Analysis and Machine Intelligence
|November 21, 2009

Abstract:
This paper proposes a fast algorithm for Walsh Hadamard Transform on sliding windows which can be used to implement pattern matching most efficiently. The computational requirement of the proposed algorithm is about 1.5 additions per projection vector per sample, which is the lowest among existing fast algorithms for Walsh Hadamard Transform on sliding windows.
Related Concept Videos
 01:17
Wald-Wolfowitz Runs Test I
The Wald-Wolfowitz test, also known as the runs test, is a nonparametric statistical test used to assess the randomness of a sequence of two different types of elements (e.g., positive/negative values, successes/failures). It examines whether the order of the elements in a sequence is random or if there is a pattern or trend present. This nonparametric test applies to any ordered data despite the population and sample data distribution, even if a higher sample size is available.
The test works...
The test works...
 01:10
Fast Fourier Transform
The Fast Fourier Transform (FFT) is a computational algorithm designed to compute the Discrete Fourier Transform (DFT) efficiently. By breaking down the calculations into smaller, manageable sections, the FFT significantly reduces the computational complexity involved. Direct computation of an N-point DFT requires N2 complex multiplications, whereas the FFT algorithm needs only (N/2)log2N multiplications, offering a much faster performance.
The computational efficiency of the FFT becomes...
The computational efficiency of the FFT becomes...
 01:21
Linear Approximation in Time Domain
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:20
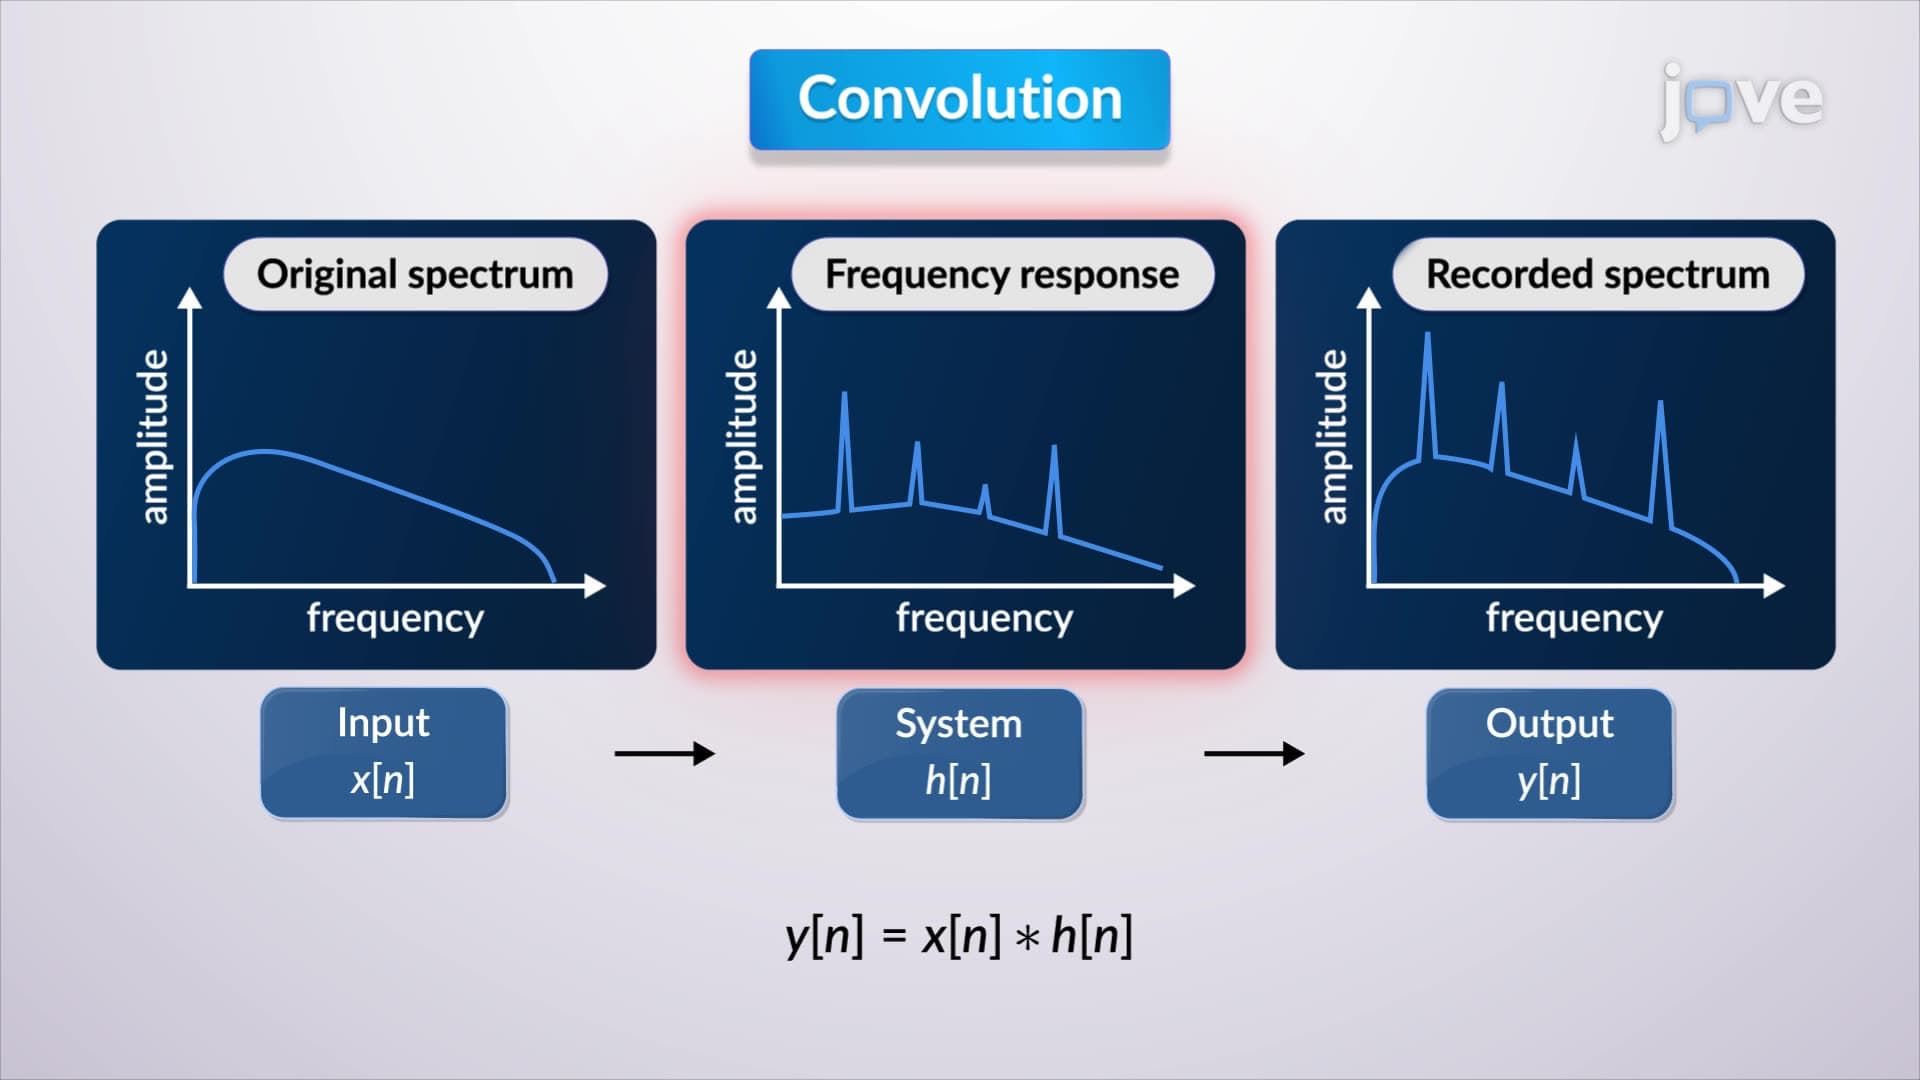
Deconvolution
Deconvolution, also known as inverse filtering, is the process of extracting the impulse response from known input and output signals. This technique is vital in scenarios where the system's characteristics are unknown, and they must be inferred from the observable signals.
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
 01:26
Linear Approximation in Frequency Domain
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear.
 01:24
Convolution: Math, Graphics, and Discrete Signals
In any LTI (Linear Time-Invariant) system, the convolution of two signals is denoted using a convolution operator, assuming all initial conditions are zero. The convolution integral can be divided into two parts: the zero-input or natural response and the zero-state or forced response, with t0 indicating the initial time.
To simplify the convolution integral, it is assumed that both the input signal and impulse response are zero for negative time values. The graphical convolution process...
To simplify the convolution integral, it is assumed that both the input signal and impulse response are zero for negative time values. The graphical convolution process...