Related Experiment Video
Updated: Jun 18, 2026


Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
Use of the fast orthogonal search method to estimate optimal joint angle for upper limb Hill-muscle models
Katherine Mountjoy1, Evelyn Morin, Keyvan Hashtrudi-Zaad
1Department of Electrical and Computer Engineering, Queen's University, Kingston, ON K7L 3N6, Canada. 6kcm@queensu.ca

Abstract:
An important aspect of accurate representation of human movement is the ability to account for differences between individuals. The following paper proposes a methodology using Hill-based candidate functions in the fast orthogonal search (FOS) method to predict translational force at the wrist from flexion and extension torque at the elbow. Within this force-prediction framework, it is possible to implicitly estimate subject-specific physiological parameters of Hill-based models of upper arm muscles. Surface electromyography data from three muscles of the upper arm (biceps brachii, brachioradialis, and triceps brachii) were recorded from ten subjects, as they performed isometric contractions at varying elbow joint angles. Estimated muscle activation level and joint angle were utilized as inputs to the FOS model. Subject-specific estimates of optimal joint angles for the three muscles were determined via frequency analysis of the selected FOS candidate functions.
Related Concept Videos
 01:15
Bones of the Upper Limb: Ulna
 01:19
Bones of the Upper Limb: Humerus
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:15
Kinematic Equations: Problem Solving
 01:15
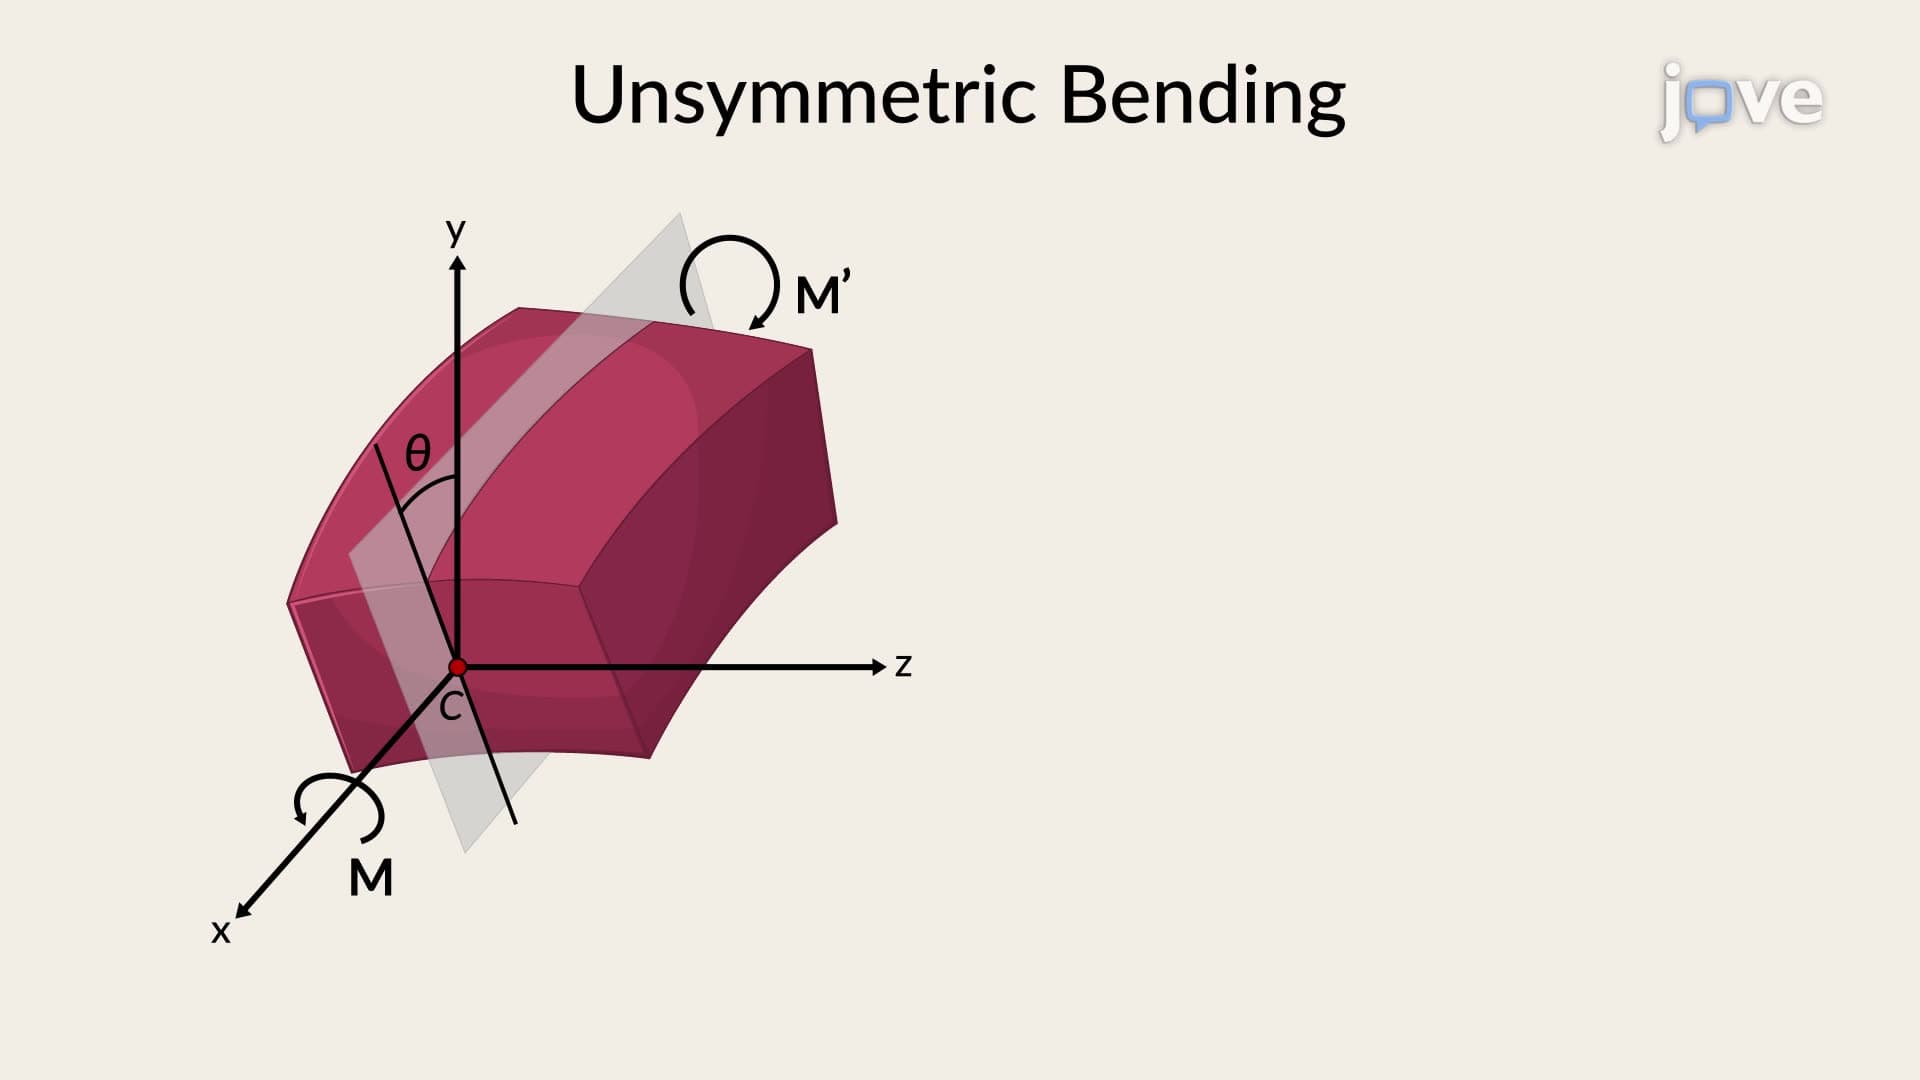
Unsymmetric Bending - Angle of Neutral Axis
When a bending moment is applied at an angle θ concerning the vertical axis of a symmetrical member, it can be resolved into components along the member's principal centroidal axes. The...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...