Related Experiment Video
Updated: Jun 18, 2026
Motor Imagery Performance Through Embodied Digital Twins in a Virtual Reality-Enabled Brain-Computer Interface Environment
Published on: May 10, 2024
Single-input-dual-output modeling of image-based input function estimation
1Department of Radiology, Washington University School of Medicine, 510 South Kingshighway Boulevard, Campus Box 8225, St. Louis, MO 63110, USA.

Purpose:
Quantification of small-animal positron emission tomography (PET) images necessitates knowledge of the plasma input function (PIF). We propose and validate a simplified hybrid single-input-dual-output (HSIDO) algorithm to estimate the PIF.
Procedures:
The HSIDO algorithm integrates the peak of the input function from two region-of-interest time-activity curves with a tail segment expressed by a sum of two exponentials. Partial volume parameters are optimized simultaneously. The algorithm is validated using both simulated and real small-animal PET images. In addition, the algorithm is compared to existing techniques in terms of area under curve (AUC) error, bias, and precision of compartmental model micro-parameters.
Results:
In general, the HSIDO method generated PIF with significantly (P < 0.05) less AUC error, lower bias, and improved precision of kinetic estimates in comparison to the reference method.
Conclusions:
HSIDO is an improved modeling-based PIF estimation method. This method can be applied for quantitative analysis of small-animal dynamic PET studies.
Related Concept Videos
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:13
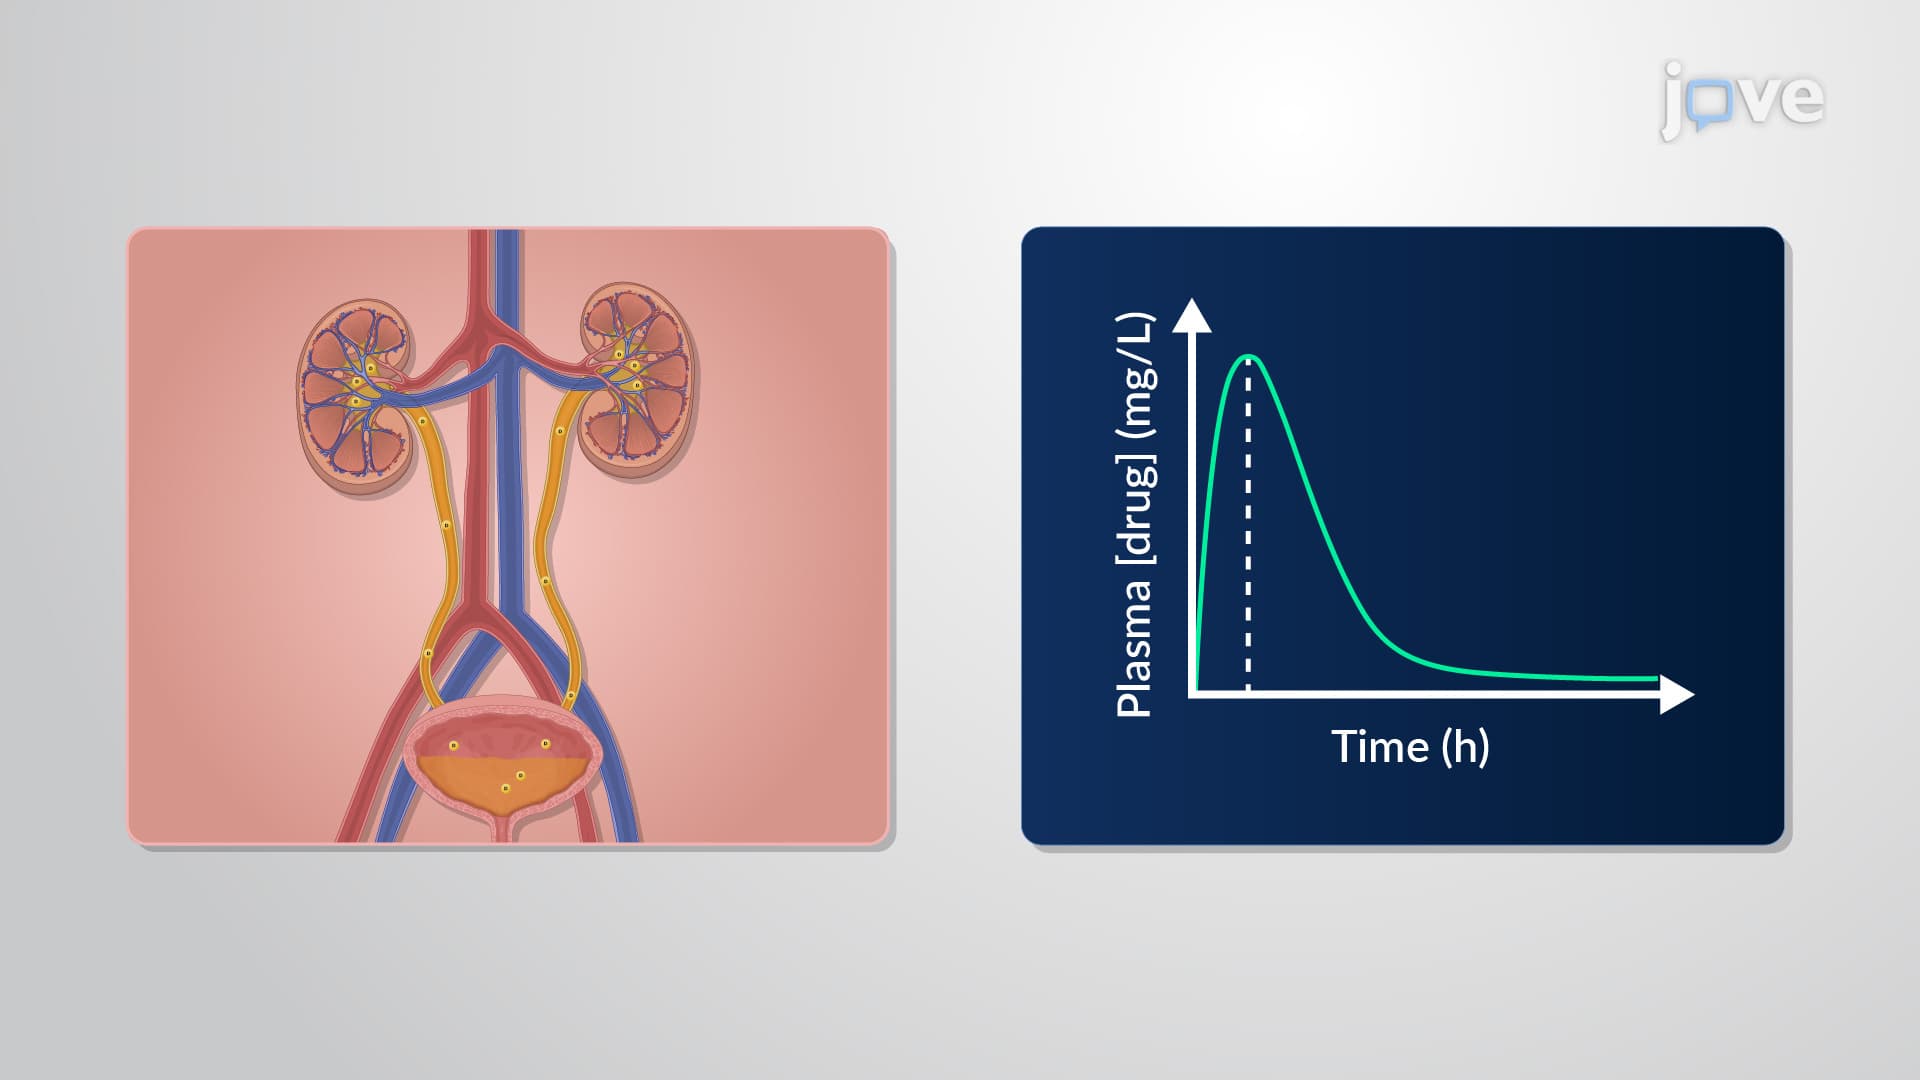
Parameters Affecting Nonlinear Elimination: Zero-Order Input, First-Order Absorption and Two-Compartment Model
When a drug is administered through a constant intravenous infusion and eliminated via nonlinear pharmacokinetics, it follows zero-order input. For example, oral drugs undergo first-order absorption upon administration and are eliminated through nonlinear pharmacokinetics.
In the case of subcutaneously administered drugs,...
 01:20
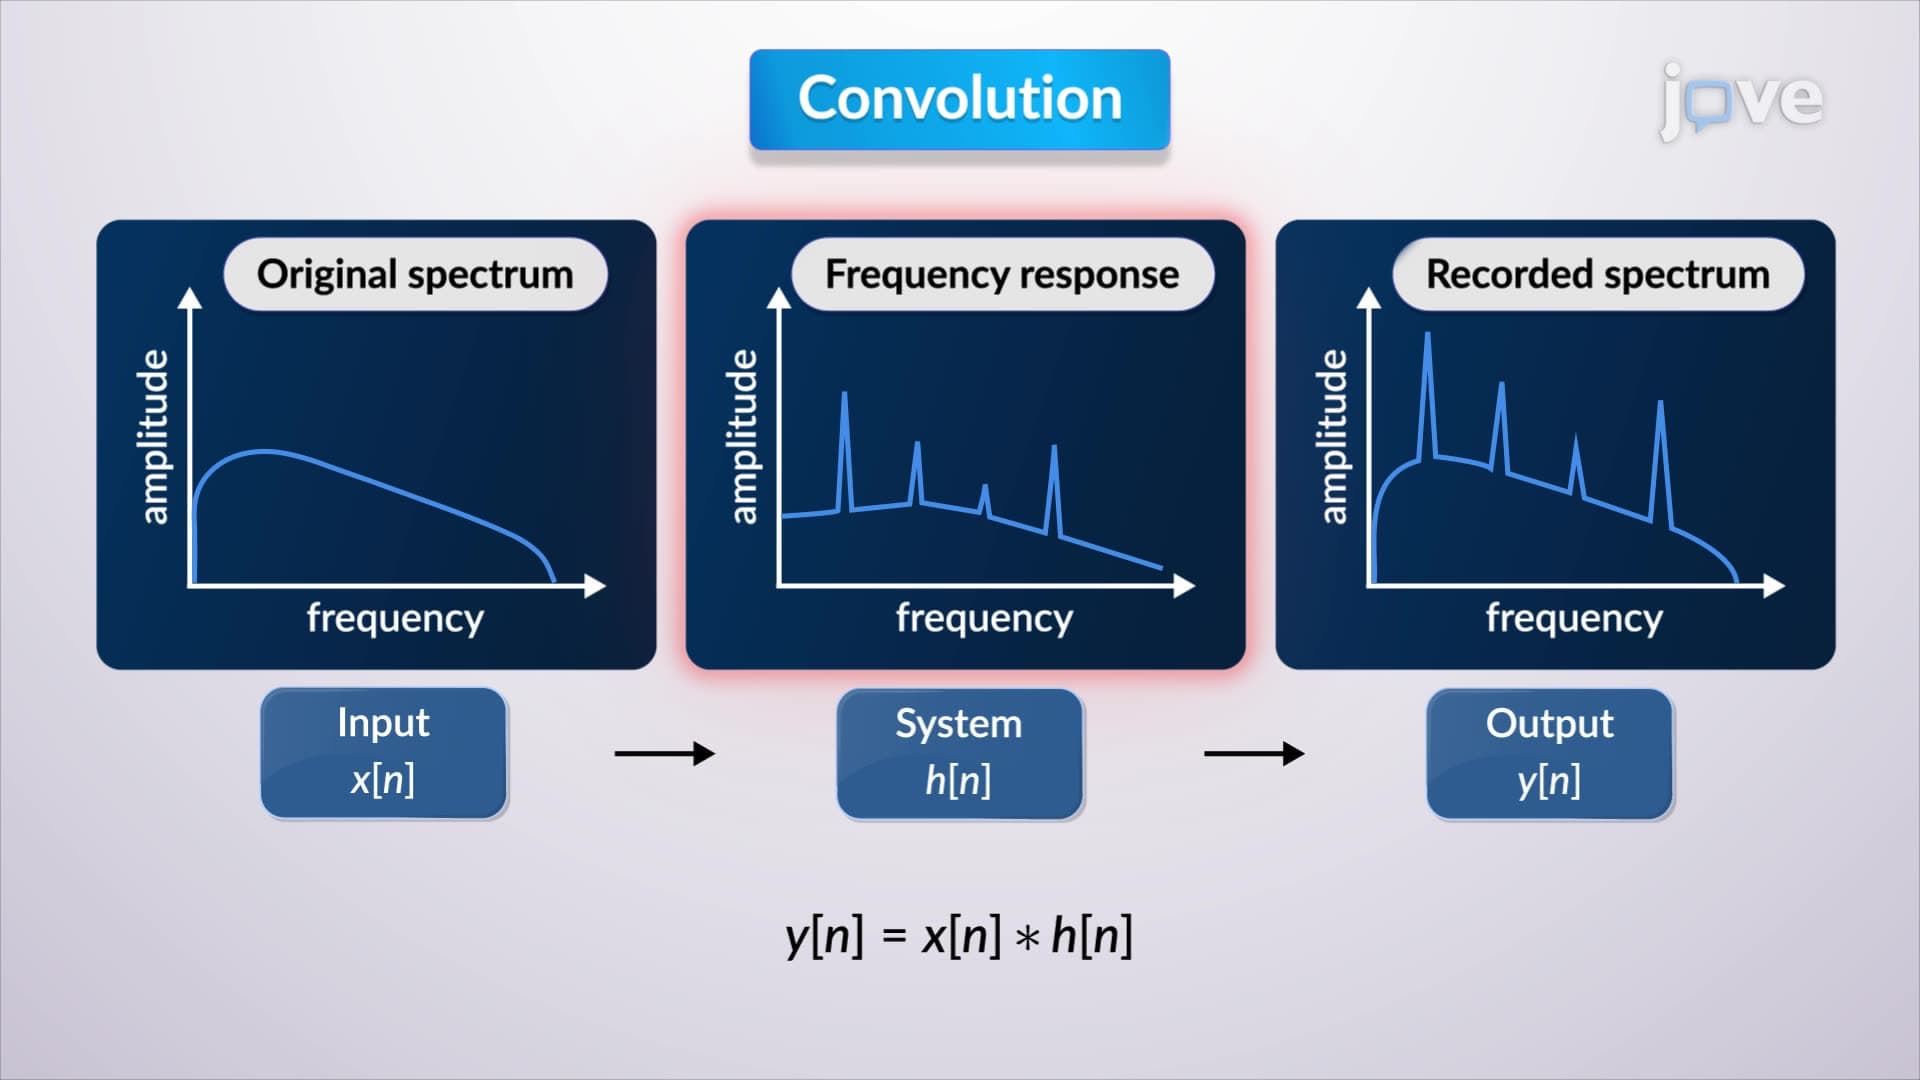
Deconvolution
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
 01:18
Second Order systems II
If ζ...
 01:25
Modeling with Differential Equations
 01:24
One-Compartment Open Model: Wagner-Nelson and Loo Riegelman Method for ka Estimation
On...