Related Experiment Video
Updated: Jun 18, 2026
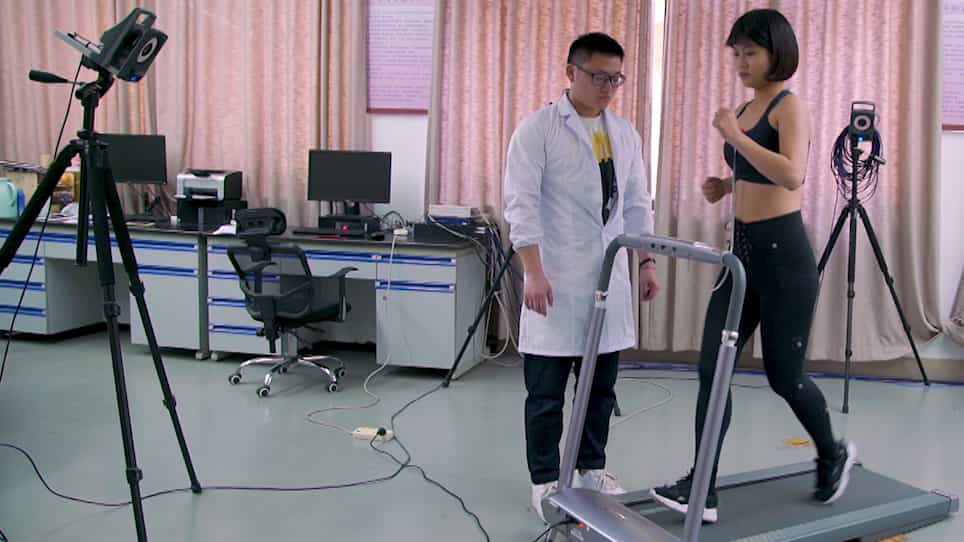

Comparative Analysis of Lower Limb Kinematics between the Initial and Terminal Phase of 5km Treadmill Running
Published on: July 17, 2020
Kinematic walking analysis on a new vehicle "Tread-Walk" with active velocity control of treadmill belt
Takeshi Ando1, Misato Nihei, Eiichi Ohki
1Faculty of Science and Engineering, Waseda University, Tokyo, Japan. ando@aoni.waseda.jp

Abstract:
The importance on walking for health is growing in elder dominated society. We have been developing a new mobility "Tread-Walk 1 (TW-1)" controlled by walking movement. The device uses active treadmill velocity control, which allows the user to walk on the treadmill at any desired velocity. In this paper, the walking movements on the TW-1 were kinematically analyzed and compared with the walking movements on a traditional constant-velocity treadmill and on flat ground. The results showed that the walking pattern on the TW-1 was somewhat similar to that on a constant-velocity treadmill and on flat ground; however, the flexion angle of the hip joint and the dorsiflexion and plantaflexion angles of the ankle joint during TW-1 walking were larger. It also was shown that the foot applied a stronger kicking force to the belt at toe-off and the foot clearance on the TW-1 was larger than that on the constant-velocity treadmill and on flat ground. Therefore, the walking patterns in the swing and stance phase on the TW-1 are little different. However, the walking movements based on the TW-1 active belt control are valuable from the viewpoints of motion training.
Related Concept Videos
 01:18
Actin Treadmilling
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...