Related Experiment Video
Updated: Jun 18, 2026
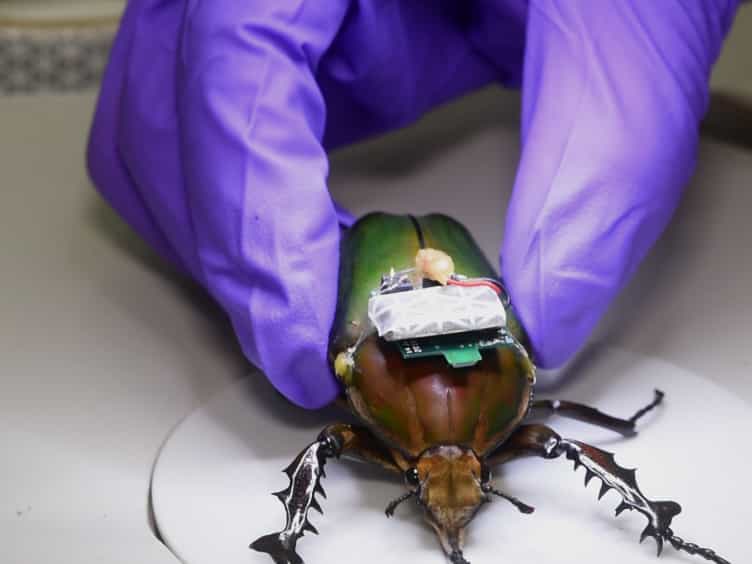
Insect-machine Hybrid System: Remote Radio Control of a Freely Flying Beetle (Mercynorrhina torquata)
Published on: September 2, 2016
Aerial and terrestrial locomotion control of lift assisted insect biobots
Alper Bozkurt1, Amit Lal, Robert Gilmour
1School of Electrical and Computer Engineering, Cornell University, Ithaca, NY 14853 USA. ayb3@cornell.edu

Abstract:
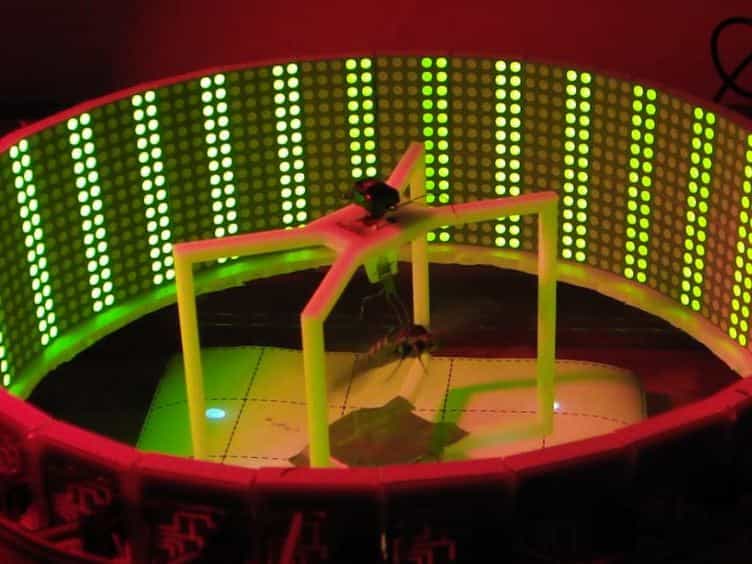
This paper presents results on remote control navigation of moths implanted with neuromuscular probes. We have previously demonstrated that the technique of metamorphosis based surgical insertions enables the concept of "insect-based" centimeter scale biobots. Here, we demonstrate for the first time, the control of gait with a radio controlled, balloon-suspended, electrode-instrumented Manduca sexta by altering the direction of turn through applied neuromuscular pulses. We also present sustained flight control in Manduca sexta with demonstration of take-off, controlled yaw, and controlled landing. The assist of the helium balloon for lifting payloads allows for a wide-range of application space where insect biobots can be deployed.

Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:23
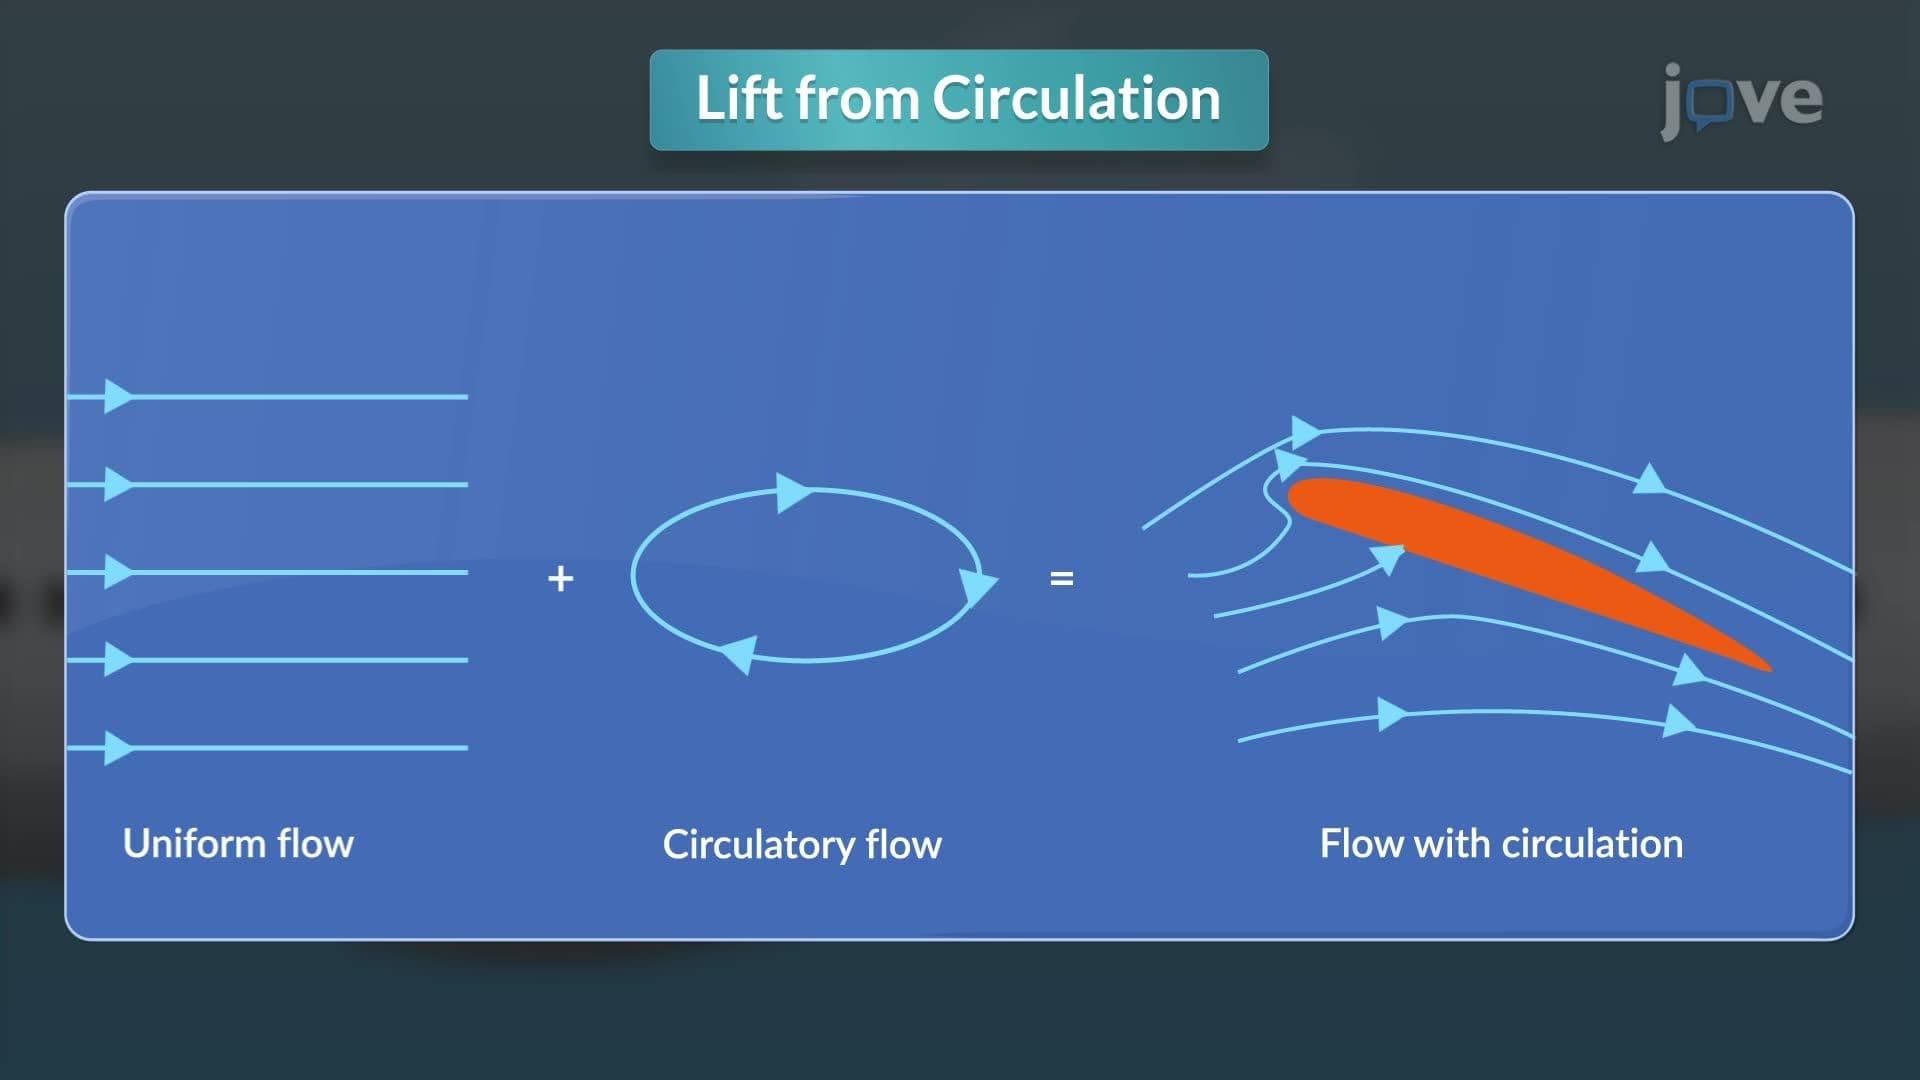
Lift