State estimation using interval analysis and belief-function theory: application to dynamic vehicle localization
Related Experiment Video
Updated: Jun 17, 2026
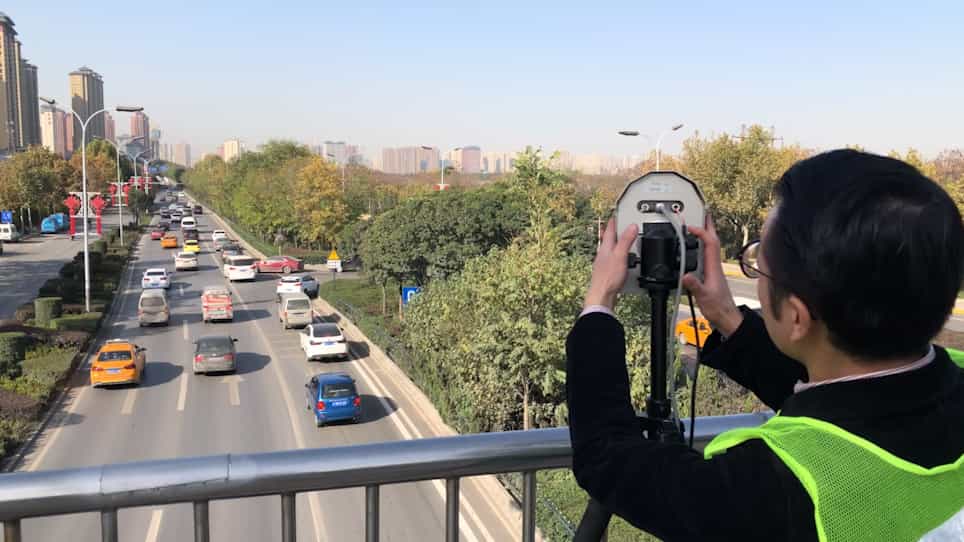
Evaluation of an Exclusive Spur Dike U-Turn Design with Radar-Collected Data and Simulation
Published on: February 1, 2020
Ghalia Nassreddine1, Fahed Abdallah, Thierry Denoux
1UMR CNRS 6599 HEUDIASYC, Université de Technologie de Compiègne, 60205 Compiègne Cedex, France. gnassred@hds.utc.fr

Abstract:
A new approach to nonlinear state estimation based on belief-function theory and interval analysis is presented. This method uses belief structures composed of a finite number of axis-aligned boxes with associated masses. Such belief structures can represent partial information on model and measurement uncertainties more accurately than can the bounded-error approach alone. Focal sets are propagated in system equations using interval arithmetics and constraint-satisfaction techniques, thus generalizing pure interval analysis. This model was used to locate a land vehicle using a dynamic fusion of Global Positioning System measurements with dead reckoning sensors. The method has been shown to provide more accurate estimates of vehicle position than does the bounded-error method while retaining what is essential: providing guaranteed computations. The performances of our method were also slightly better than those of a particle filter, with comparable running time. These results suggest that our method is a viable alternative to both bounded-error and probabilistic Monte Carlo approaches for vehicle-localization applications.
Related Concept Videos
 01:03
Prediction Intervals
However, the point estimate is most likely not the exact value of the population parameter, but close to it. After calculating point estimates, we construct interval estimates, called confidence intervals or prediction intervals. This prediction interval comprises a range of values unlike the point estimate and is a better predictor of the observed sample value, y.
The...
 01:29
Evaluating Limits by Direct Substitution
 01:29
Distance Problem
 01:29
Application of Linearization and Approximation
 01:30
Vector Functions and Motion: Problem Solving
 01:19
Root-Locus Method
This system can be represented by a block diagram,...