Related Experiment Video
Updated: Jun 17, 2026

Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Interpersonal postural coordination on rigid and non-rigid surfaces
Thomas A Stoffregen1, M Russell Giveans, Sebastien Villard
1Dept. of Kinesiology, University of Minnesota, Minneapolis, MN, USA.

Abstract:
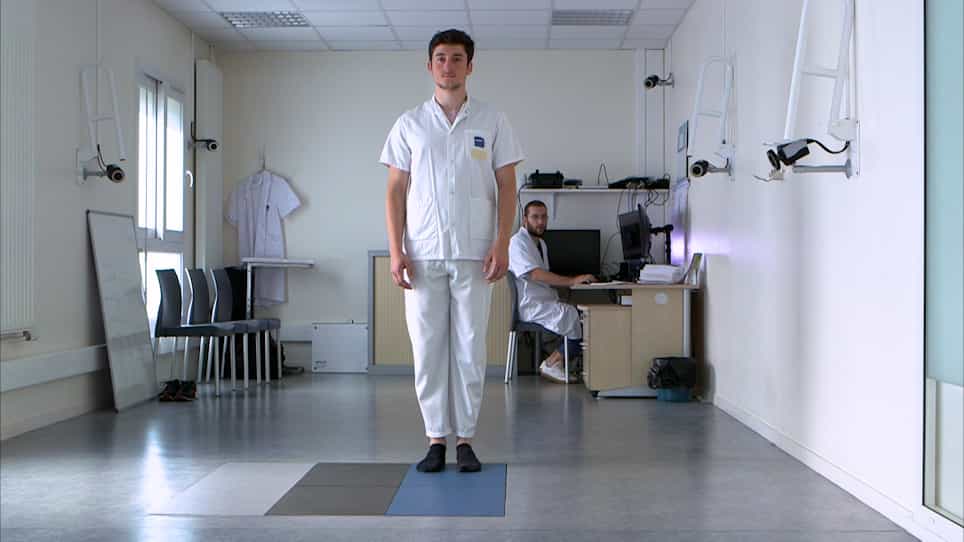
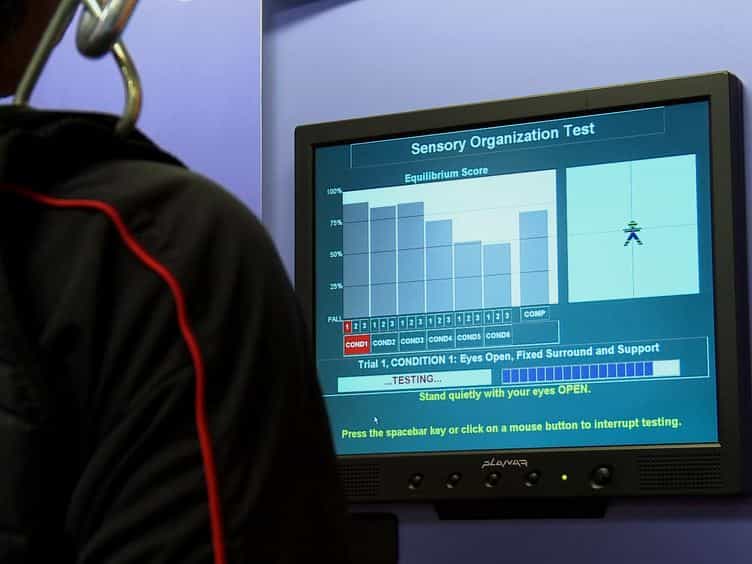
When two standing people converse with each other there is an increase in their shared postural activity, relative to conversation with different partners. We asked pairs of participants to converse with each other or with experimental confederates while standing on rigid and nonrigid surfaces. On the rigid surface, shared postural activity was greater when participants conversed with each other than when they conversed with confederates. In addition, the strength of interpersonal coupling increased across trials, but only when members of a dyad conversed with each other. On the nonrigid surface, postural sway variability increased, but we found no evidence that shared postural activity was different when participants conversed with each other, as opposed to conversing with confederates. We consider several possible interpretations of these results.
Related Concept Videos
 01:21
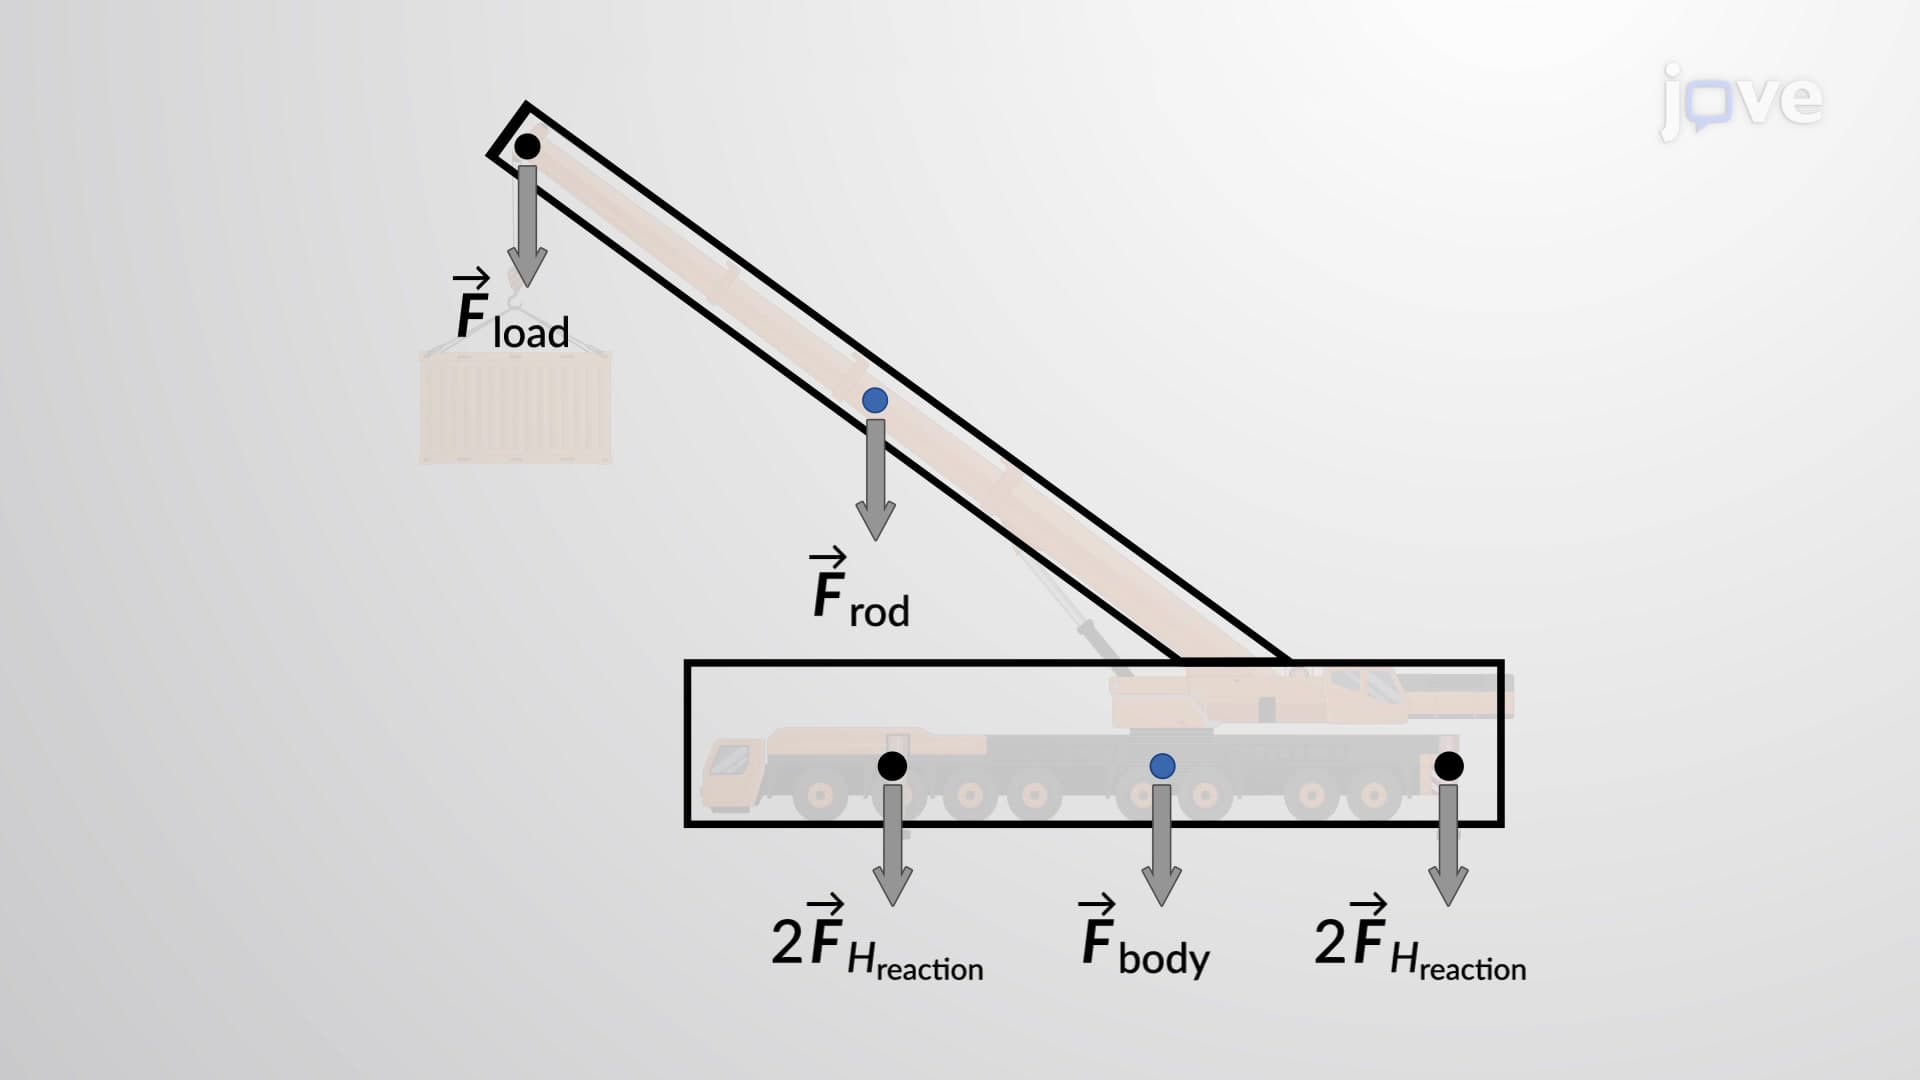
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 00:49
Rigid Body Equilibrium Problems - I
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:25
Coplanar Forces
 01:27
Movement Joints in Buildings
The simplest type of movement joints, working joints, are...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...