Rank one chaos in a class of planar systems with heteroclinic cycle

Fengjuan Chen1, Maoan Han

  • 1Department of Mathematics, Shanghai Normal University, Shanghai 200234, People's Republic of China. fjchen@zjnu.cn

Chaos (Woodbury, N.Y.)
|January 12, 2010
PubMed

Related Concept Videos

One-Degree-of-Freedom System01:24

One-Degree-of-Freedom System

In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...

Second Order systems I01:20

Second Order systems I

A servo system exemplifies a second-order system, featuring a proportional controller and load elements that ensure the output position aligns with the input position. The relationship between these components is described by a second-order differential equation. Applying the Laplace transform under zero initial conditions yields the transfer function, showing how inputs are converted to outputs in the system.
By reinterpreting the system, one can derive the closed-loop transfer function, which...
Second Order systems II01:18

Second Order systems II

In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
If  ζ...
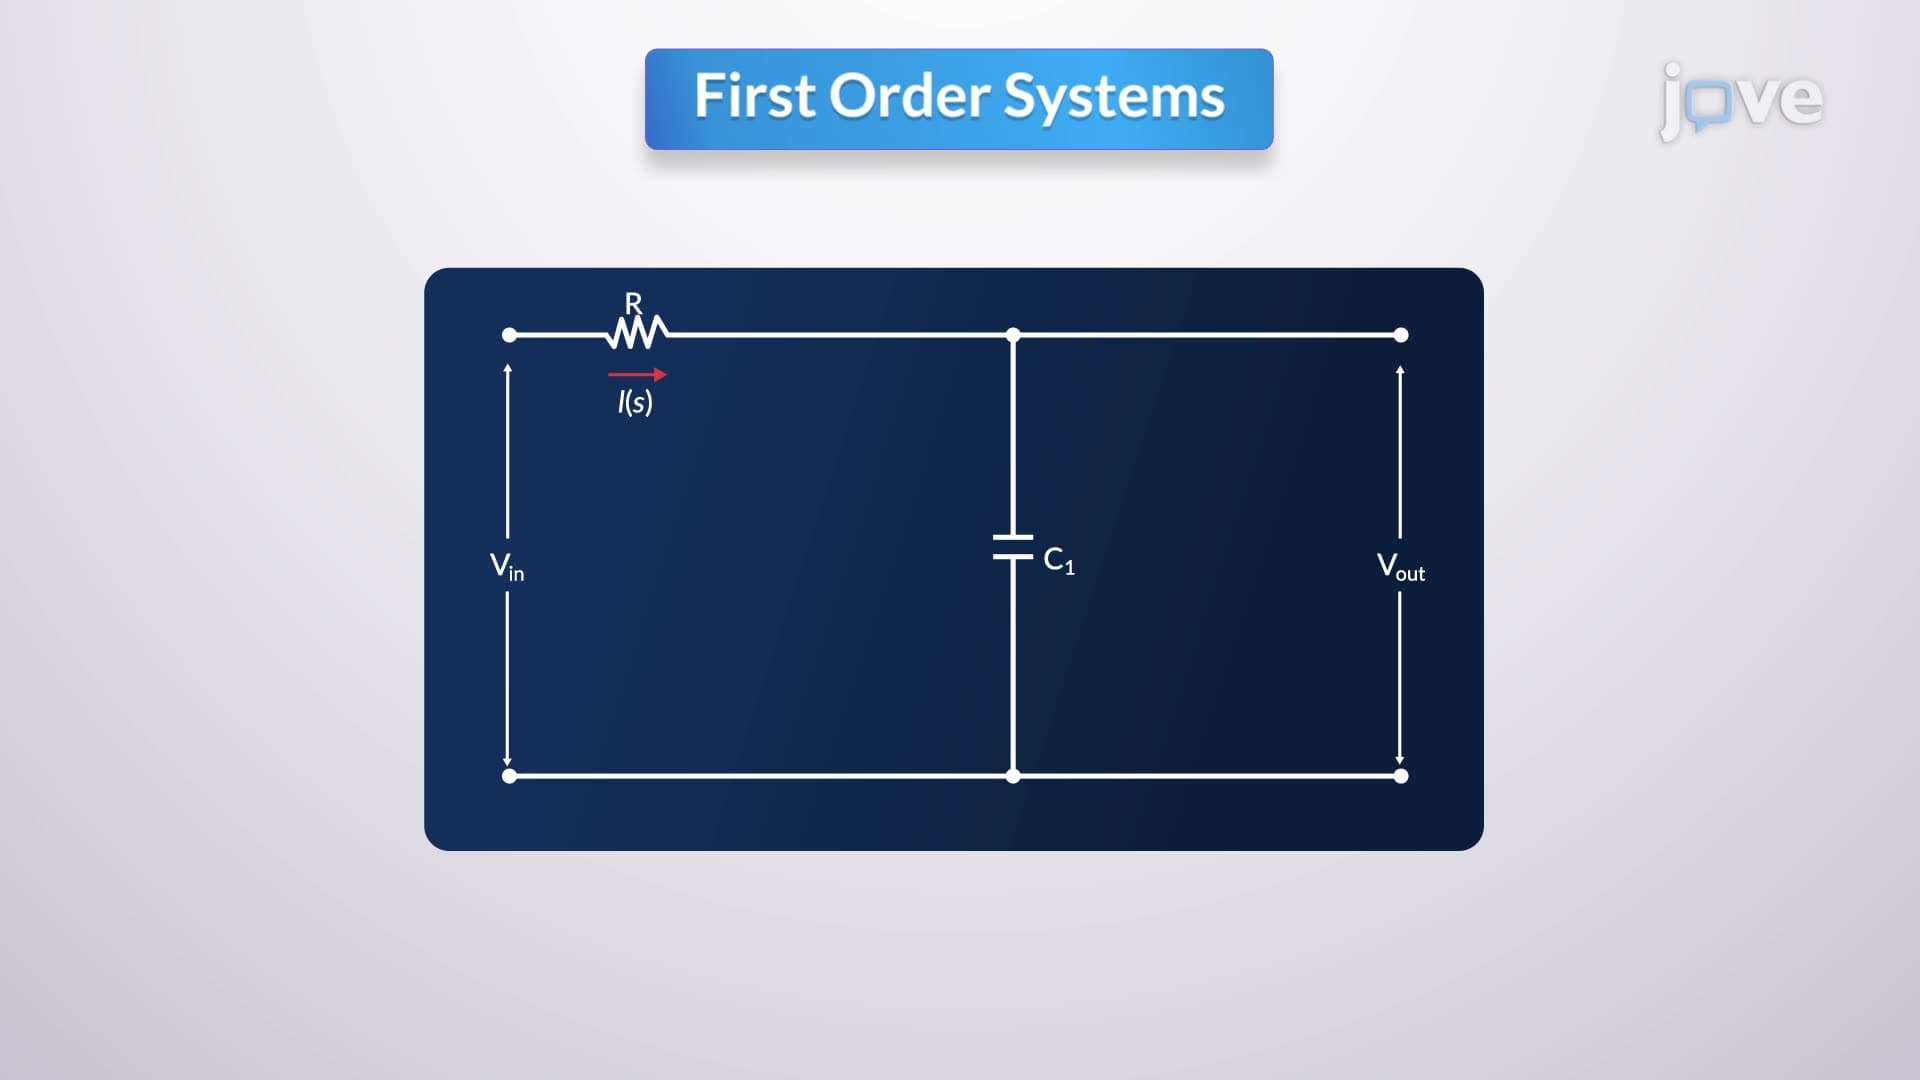
First Order Systems01:21

First Order Systems

First-order systems, such as RC circuits, are foundational in understanding dynamic systems due to their straightforward input-output relationship. Analyzing their responses to different input functions under zero initial conditions reveals significant insights into system behavior.
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
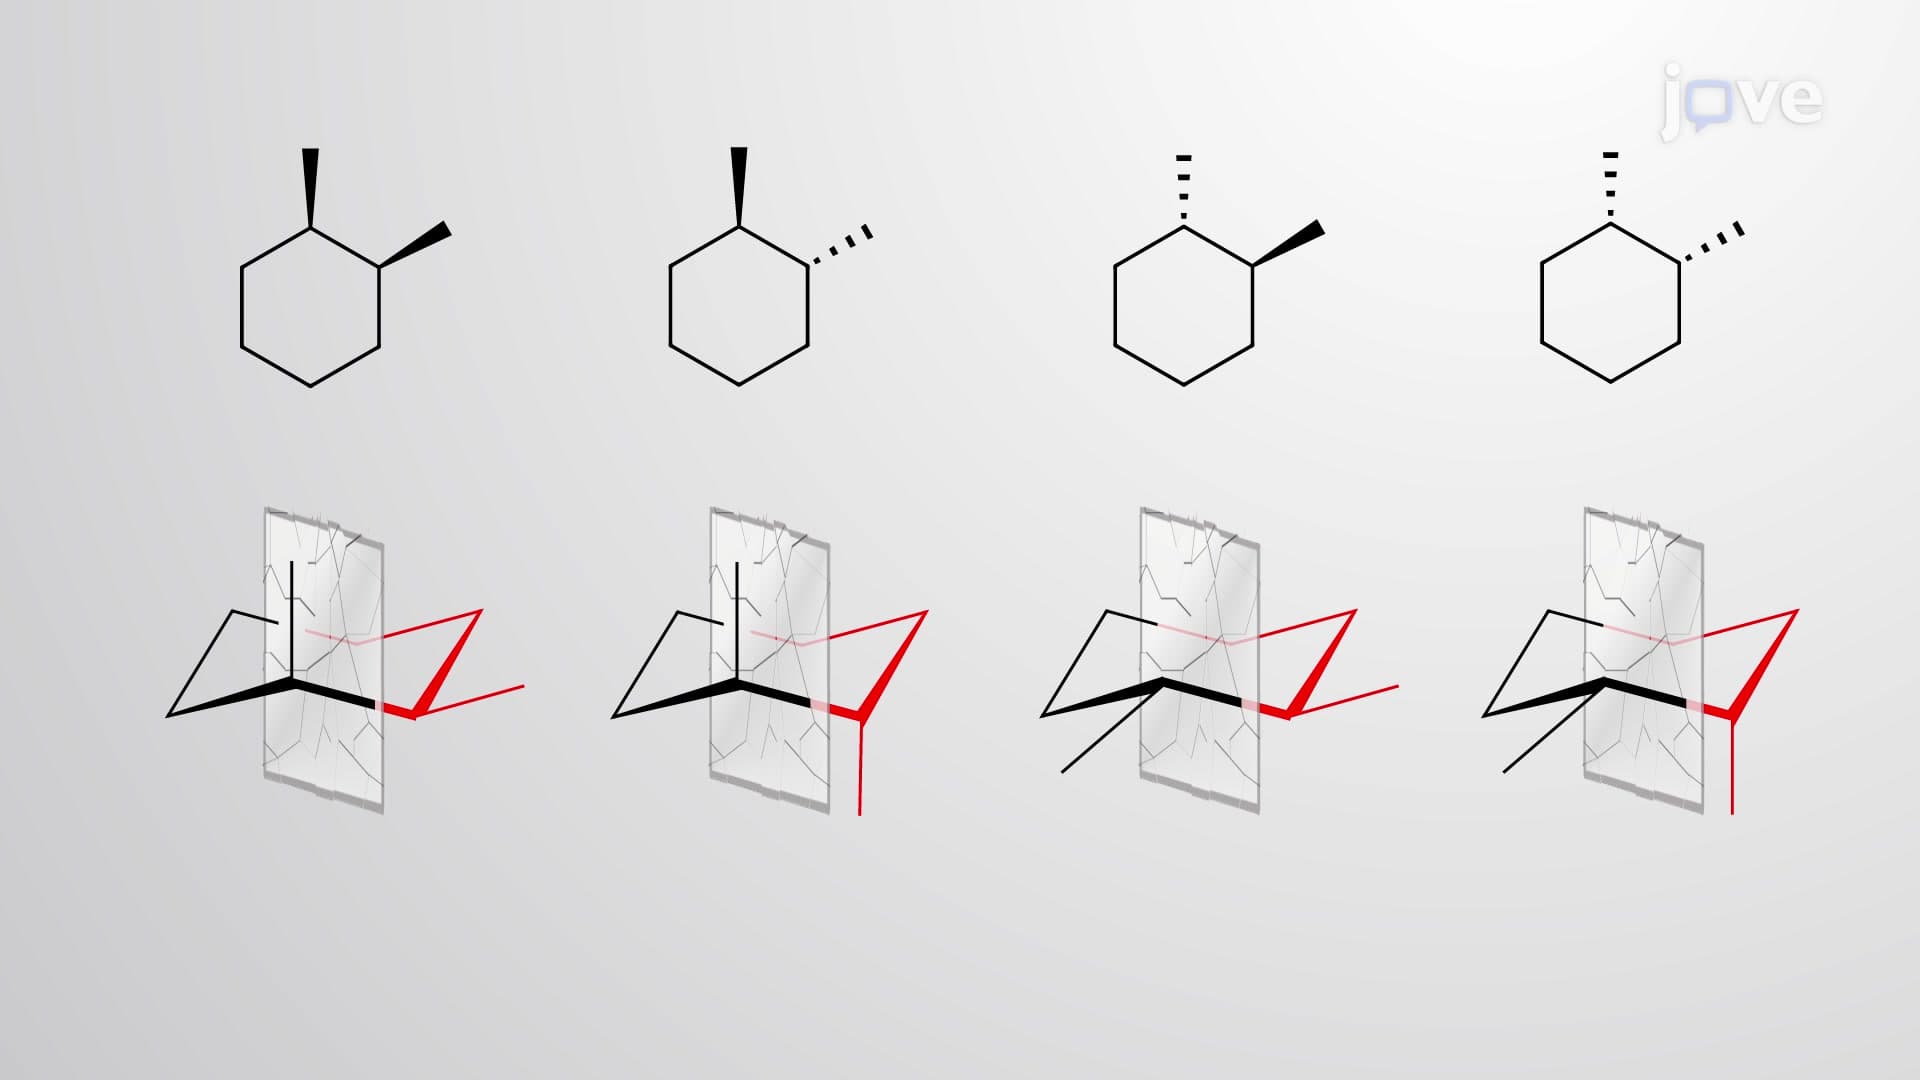
Stereoisomerism of Cyclic Compounds02:33

Stereoisomerism of Cyclic Compounds
In this lesson, we delve into the role of ring conformation and its stability, which determines the spatial arrangement and, consequently, the molecular symmetry and stereoisomerism of cyclic compounds. 1,2-Dimethylcyclohexane is used as a case study to evaluate the possible number of stereoisomers. Here, given the multiple (n = 2) chiral centers, there are 2n = 4 possible configurations that lack a plane of symmetry, as the ring skeleton exists in a non-planar chair conformation. In addition,...
First Law: Particles in One-dimensional Equilibrium01:10

First Law: Particles in One-dimensional Equilibrium

Newton's first law of motion states that a body at rest remains at rest, or if in motion, remains in motion at constant velocity, unless acted on by a net external force. It also states that there must be a cause for any change in velocity (a change in either magnitude or direction) to occur. This cause is a net external force. For example, consider what happens to an object sliding along a rough horizontal surface. The object quickly grinds to a halt, due to the net force of friction. If we...