Related Experiment Video
Updated: Jun 17, 2026


MPI CyberMotion Simulator: Implementation of a Novel Motion Simulator to Investigate Multisensory Path Integration in Three Dimensions
Published on: May 10, 2012
A model of plaid motion perception based on recursive Bayesian integration of the 1-D and 2-D motions of plaid
Kameliya D Dimova1, Michael J Denham
1Centre for Theoretical and Computational Neuroscience, University of Plymouth, Plymouth PL4 8AA, UK.

Abstract:
We describe a theoretical and computational model of the perception of plaid pattern motion which fully accounts for the majority of cases in which misperception of the direction of motion of Type II plaids has been observed [Yo, C., & Wilson, H. (1992). Perceived direction of moving two-dimensional patterns depends on duration, contrast, and eccentricity. Vision Research 32, 135-147]. The model consists of two stages: in the first stage local motion detectors signal both the one-dimensional (1-D) and two-dimensional (2-D) motion of the high luminance features (blobs) in the plaid pattern; in the second stage these local motion signals are combined using a recursive Bayesian least squares estimation process. We demonstrate both theoretically and using simulations of the computational model that the estimated direction of the plaid motion for Type II plaids is initially dominated by the 1-D motion of the longer edges of the elongated blobs, which is in a direction close to the vector sum direction of the component gratings. The recursive estimation process which combines the local motion signals in the second stage of the model results in a dynamic shift in the estimated plaid direction towards the direction of the 2-D motion of the blobs, which corresponds to the veridical plaid direction.
Related Concept Videos
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:22
Planar Rigid-Body Motion
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the drone...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:27
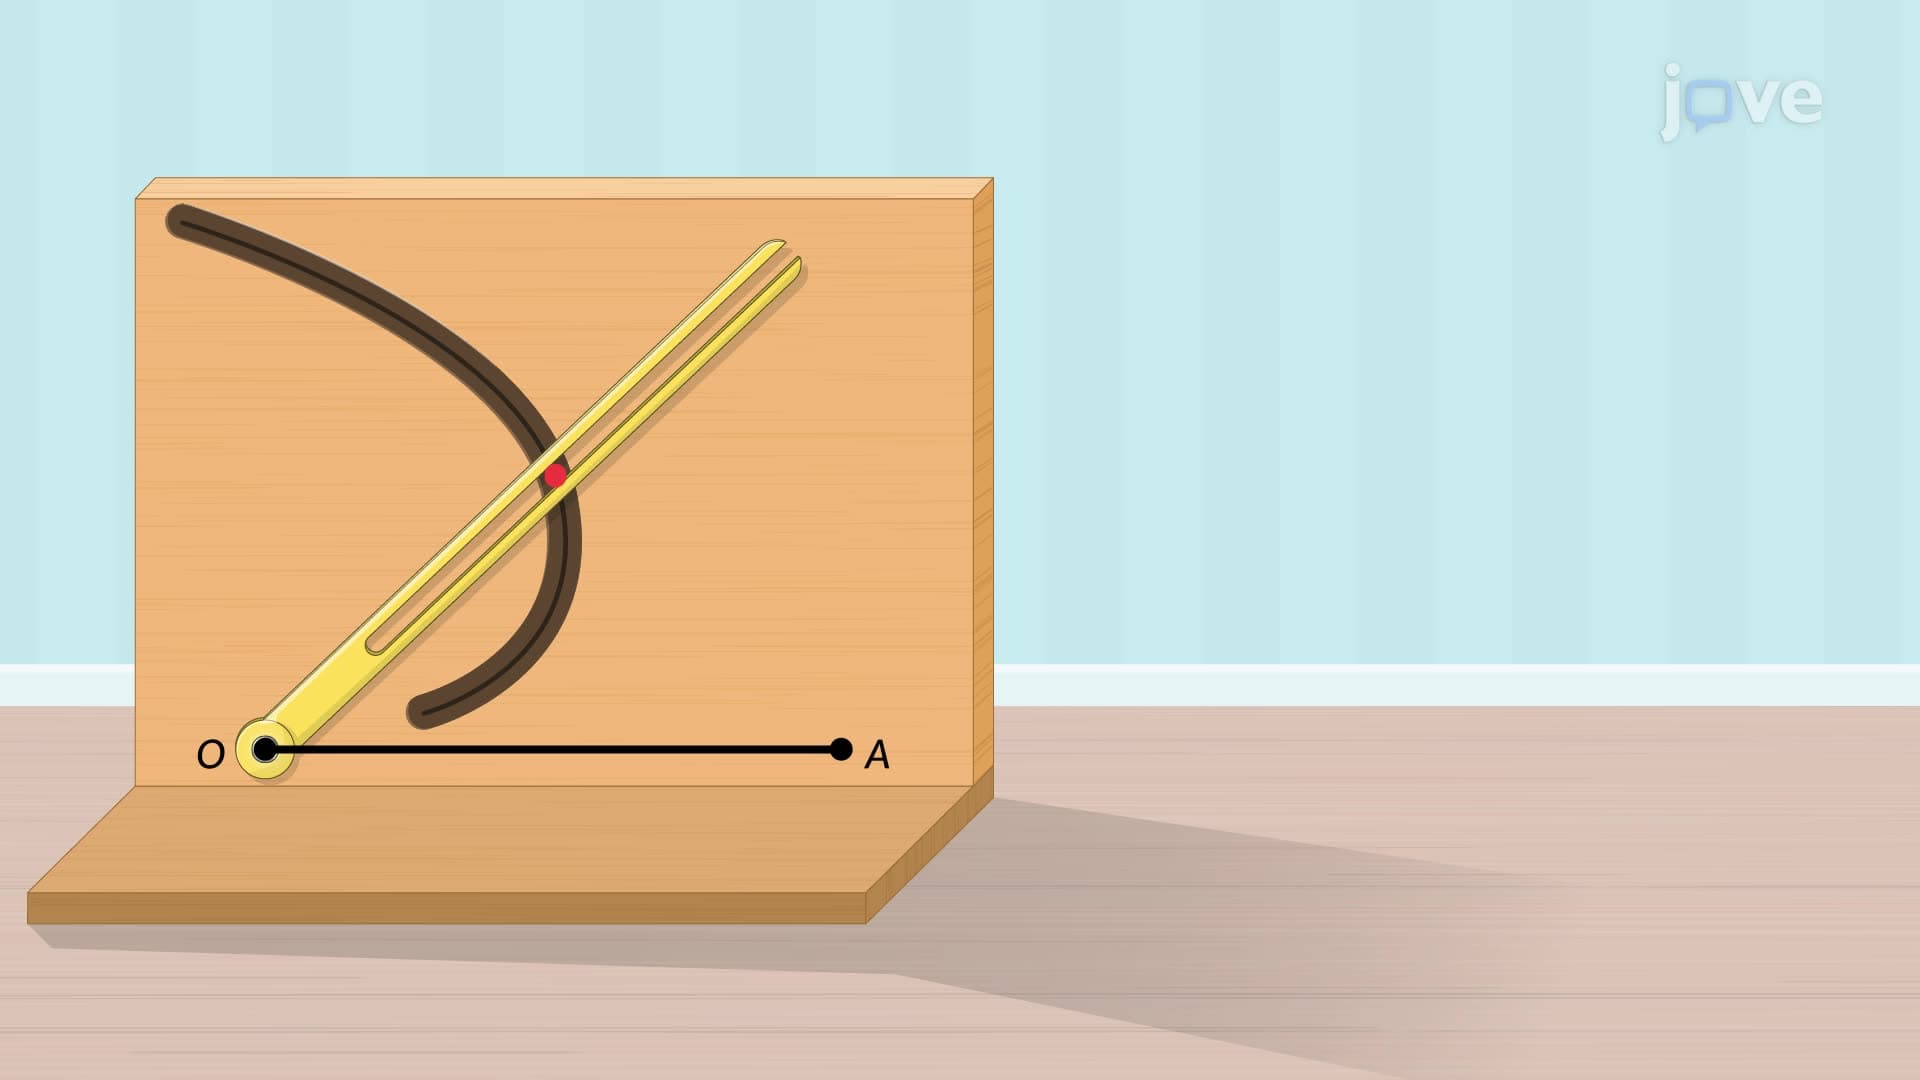
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position with respect to time...
 01:15
Depth Perception and Spatial Vision