Related Experiment Videos
Discrete-time reduced order neural observers for uncertain nonlinear systems
Alma Y Alanis1, Edgar N Sanchez, Luis J Ricalde
1CUCEI, Universidad de Guadalajara, Apartado Postal 51-71, Col. Las Aguilas, C.P. 45080, Zapopan, Jalisco, Mexico. almayalanis@gmail.com

Abstract:
This paper focusses on a novel discrete-time reduced order neural observer for nonlinear systems, which model is assumed to be unknown. This neural observer is robust in presence of external and internal uncertainties. The proposed scheme is based on a discrete-time recurrent high order neural network (RHONN) trained with an extended Kalman filter (EKF)-based algorithm, using a parallel configuration. This work includes the stability proof of the estimation error on the basis of the Lyapunov approach; to illustrate the applicability, simulation results for a nonlinear oscillator are included.
Related Concept Videos
 01:18
Second Order systems II
If ζ...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length, the...
 01:31
Classification of Systems-II
 01:21
First Order Systems
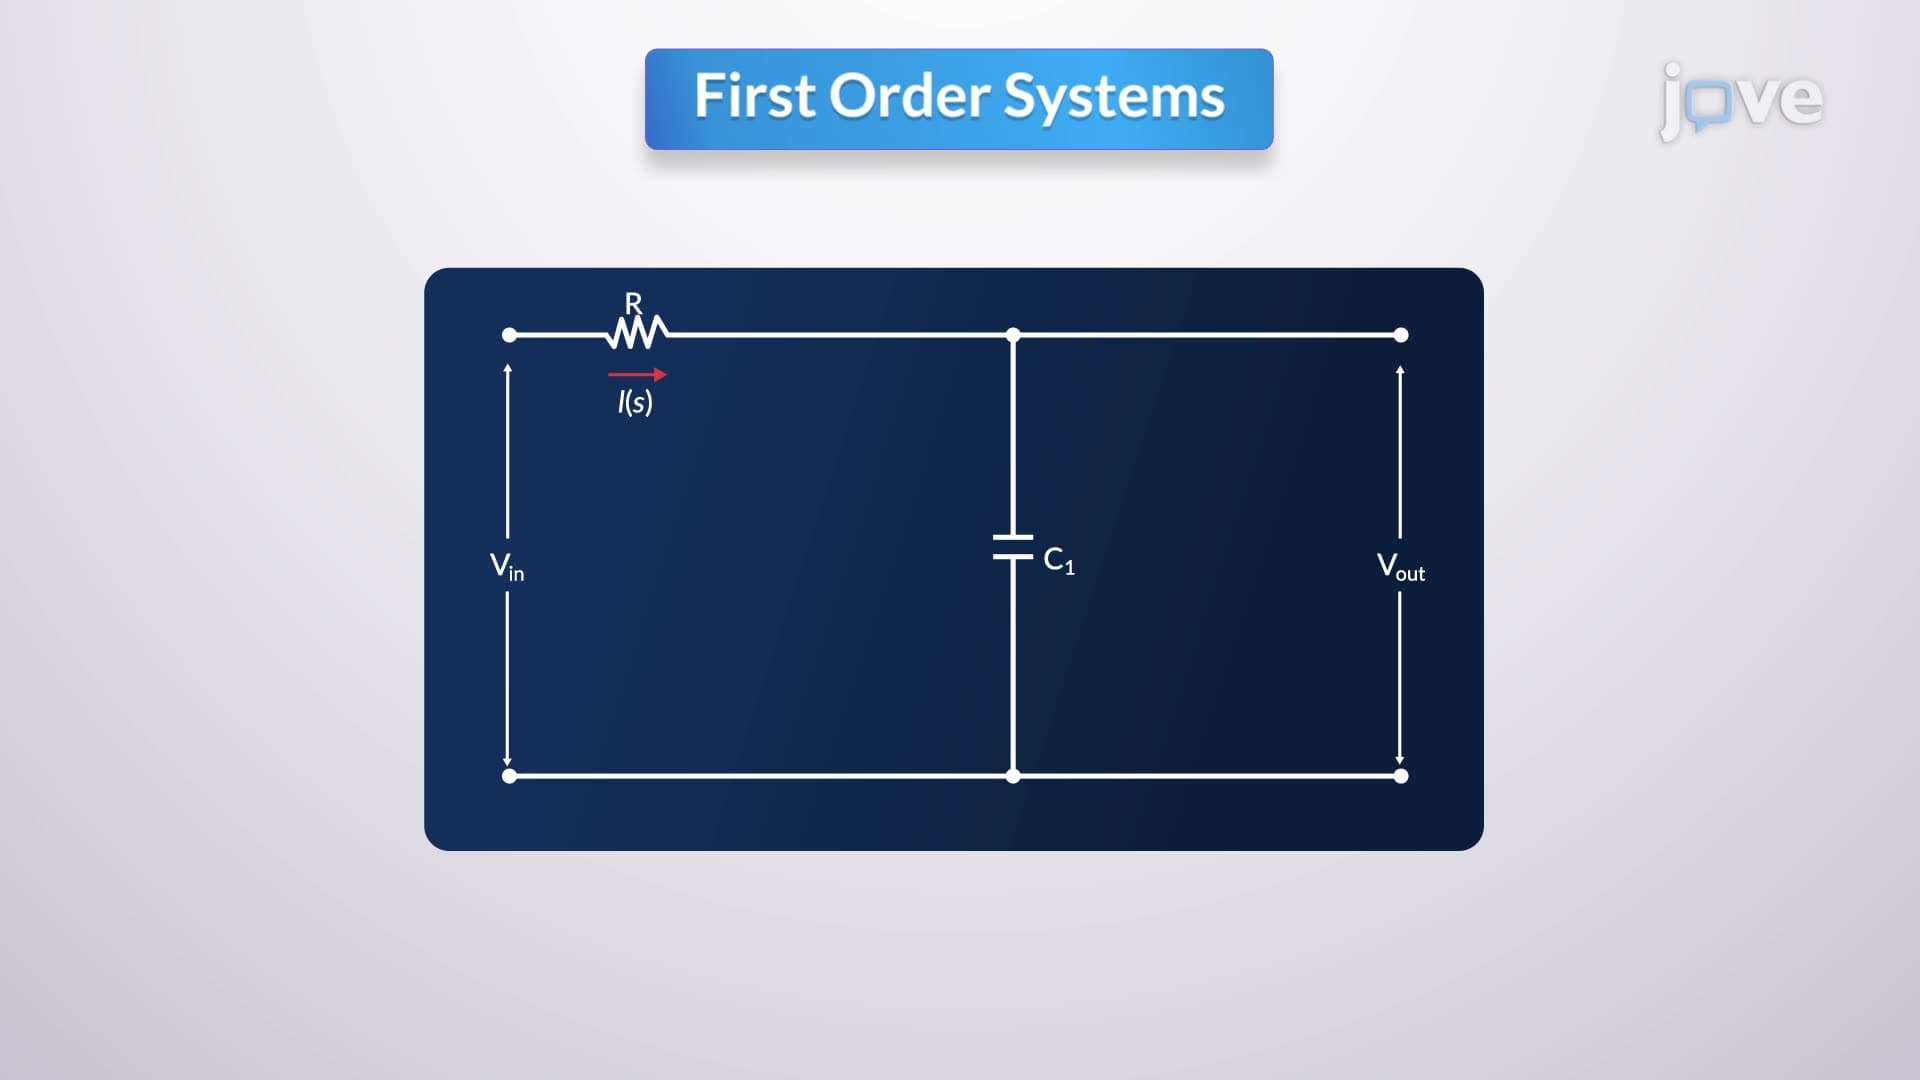
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system.