Related Experiment Video
Updated: Jun 14, 2026
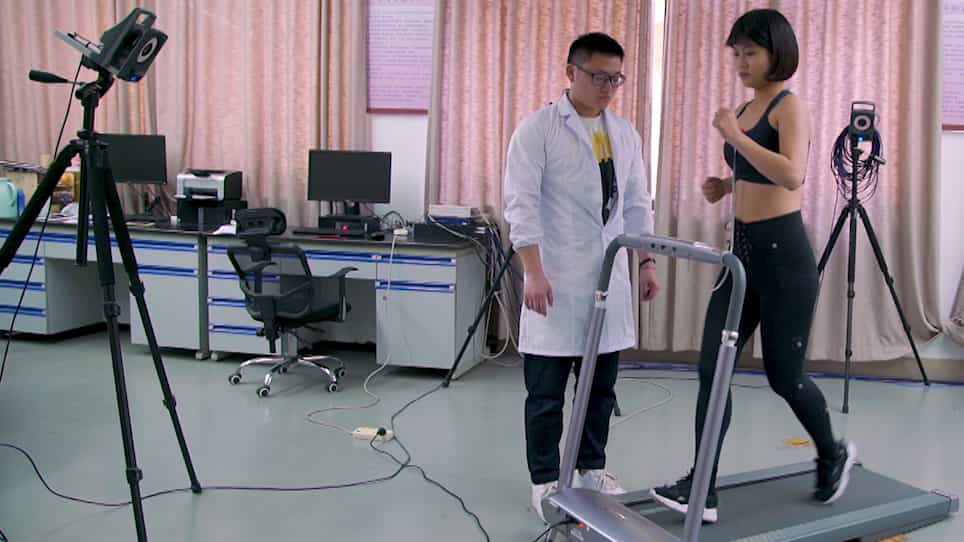

Comparative Analysis of Lower Limb Kinematics between the Initial and Terminal Phase of 5km Treadmill Running
Published on: July 17, 2020
Two explanations for the compliant running paradox: reduced work of bouncing viscera and increased stability in
Monica A Daley1, James R Usherwood
1Structure and Motion Laboratory, Royal Veterinary College, Hawkshead Lane, Hatfield, Hertfordshire AL9 7TA, UK. mdaley@rvc.ac.uk

Abstract:
Economy is a central principle for understanding animal locomotion. Yet, compared with theoretical predictions concerning economy, animals run with compliant legs that are energetically costly. Here, we address this apparent paradox, highlighting two factors that predict benefits for compliant gaits: (i) minimizing cost of work associated with bouncing viscera; and (ii) leg control for robust stability in uneven terrain. We show that consideration of the effects of bouncing viscera predicts an energetic optimum for relatively compliant legs. To compare stability in uneven terrain, we introduce the normalized maximum drop (NMD), a measure based on simple kinematics, which predicts that compliant legs allow negotiation of relatively larger terrain perturbations without failure. Our model also suggests an inherent trade-off in control of leg retraction velocity (omega) for stability: low omega allows higher NMD, reducing fall risk, whereas high omega minimizes peak forces with terrain drops, reducing injury risk. Optimization for one of these factors explicitly limits the other; however, compliant legs relax this trade-off, allowing greater stability by both measures. Our models suggest compromises in leg control for economy and stability that might explain why animals run with compliant legs.
More Related Videos
 06:35
Using Gold-standard Gait Analysis Methods to Assess Experience Effects on Lower-limb Mechanics During Moderate High-heeled Jogging and Running
Published on: September 14, 2017
 10:28
Kinematics and Ground Reaction Force Determination: A Demonstration Quantifying Locomotor Abilities of Young Adult, Middle-aged, and Geriatric Rats
Published on: February 22, 2011
Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:15
Elastic Collisions: Case Study
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 00:58
Introduction to Joints
 00:49
Rigid Body Equilibrium Problems - I
 01:00
Elastic Collisions: Introduction