Related Experiment Video
Updated: Jun 14, 2026
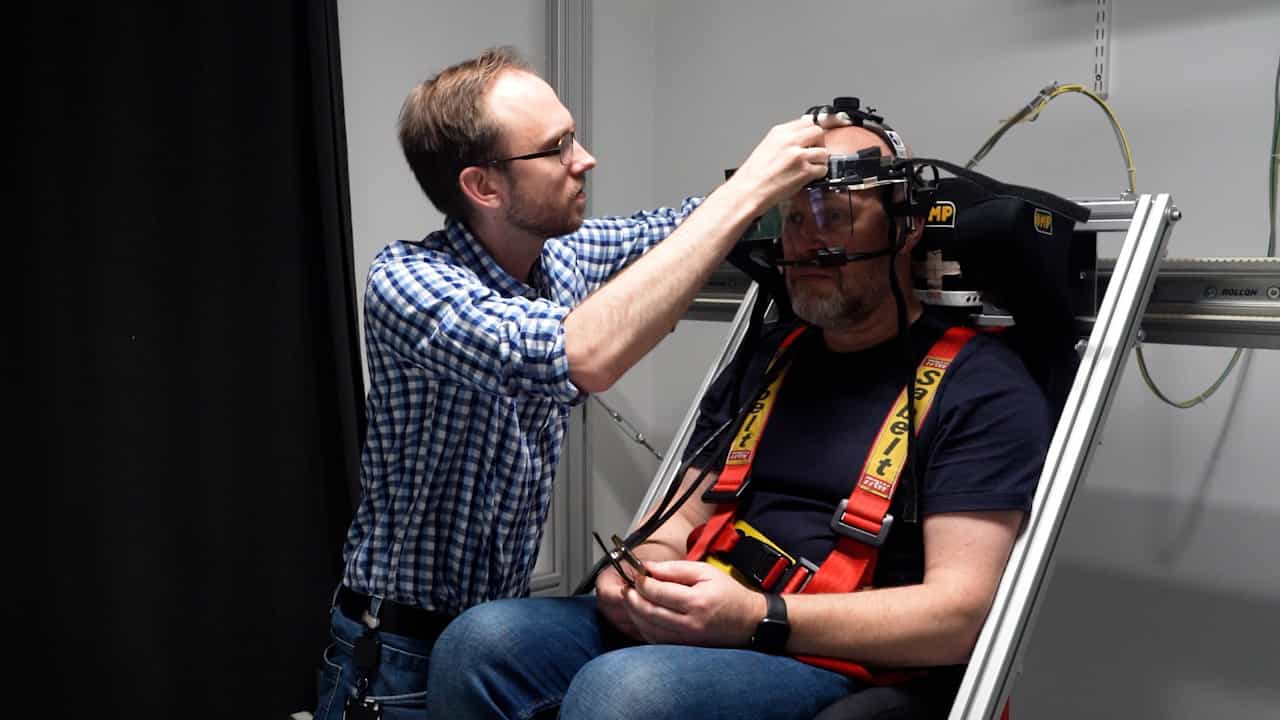

Using Eye-tracking to Assess the Relative Importance of Visual and Vestibular Input to Subcortical Motion Processing in the Roll Plane
Published on: August 22, 2025
Kinematic synergies during saccades involving whole-body rotation: a study based on the uncontrolled manifold
Adriana M Degani1, Alessander Danna-Dos-Santos, Thomas Robert
1Department of Kinesiology, The Pennsylvania State University, University Park, PA 16802, USA.

Abstract:
We used the framework of the uncontrolled manifold hypothesis to study the coordination of body segments and eye movements in standing persons during the task of shifting the gaze to a target positioned behind the body. The task was performed at a comfortable speed and fast. Multi-segment and head-eye synergies were quantified as co-varied changes in elemental variables (body segment rotations and eye rotation) that stabilized (reduced the across trials variability) of head rotation in space and gaze trajectory. Head position in space was stabilized by co-varied rotations of body segments prior to the action, during its later stages, and after its completion. The synergy index showed a drop that started prior to the action initiation (anticipatory synergy adjustment) and continued during the phase of quick head rotation. Gaze direction was stabilized only at movement completion and immediately after the saccade at movement initiation under the "fast" instruction. The study documents for the first time anticipatory synergy adjustments during whole-body actions. It shows multi-joint synergies stabilizing head trajectory in space. In contrast, there was no synergy between head and eye rotations during saccades that would achieve a relatively invariant gaze trajectory.
More Related Videos
Related Concept Videos
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:22
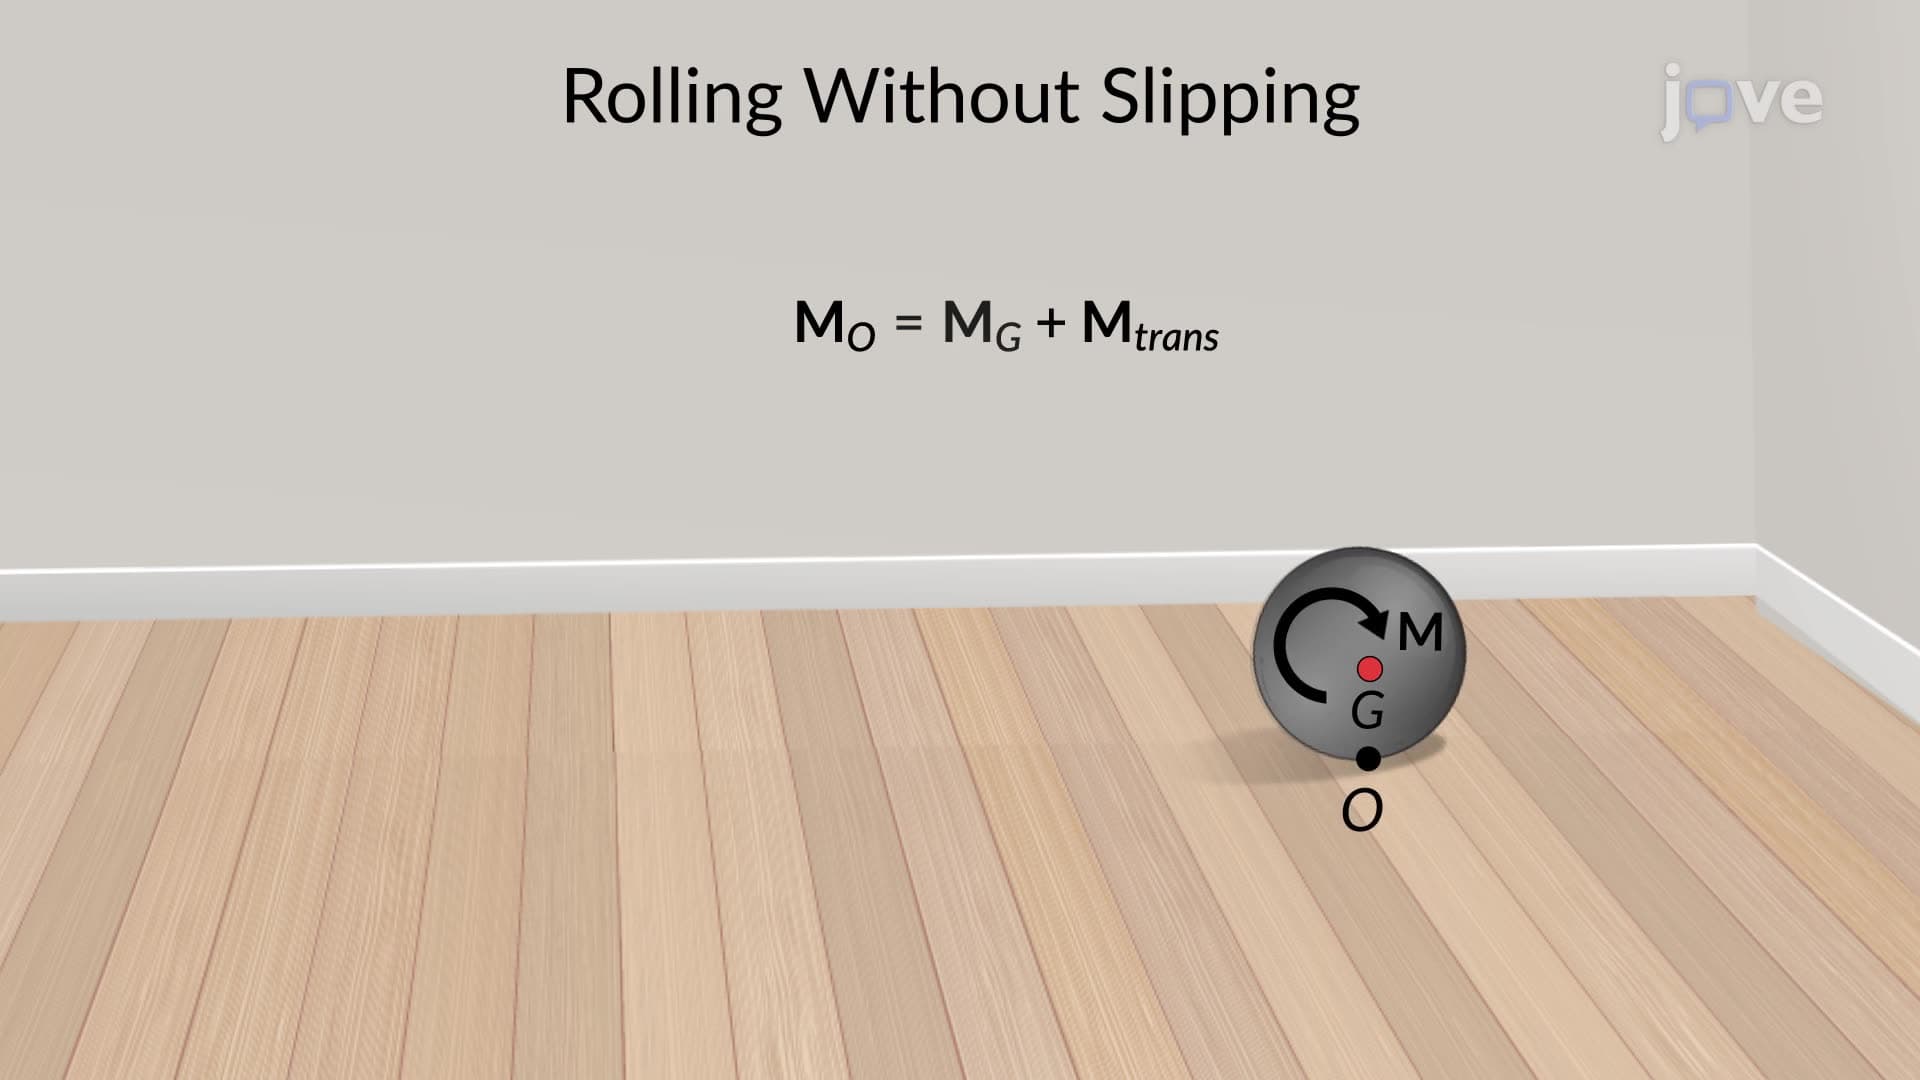
Equation of Motion: General Plane motion
Moreover, the body's center of mass experiences a rotational effect as a result of these couple moments. This rotation can be articulated as the product of the...
 01:28
Major Somatic Sensory Pathways