Interpolation of segment Euler angles can provide a robust estimation of segment angular trajectories during asymmetric lifting tasks
Related Experiment Video
Updated: Jun 14, 2026

Three-Dimensional Mapping of the Rotation of Interactive Virtual Objects with Eye-Tracking Data
Published on: October 18, 2024
Xu Xu1, Chien-Chi Chang, Gert S Faber
1Department of Environmental Health, Harvard School of Public Health, 665 Huntington Avenue, Boston, MA 02115, USA. xuxu0618@gmail.com

Abstract:
Video-based field methods that estimate L5/S1 net joint moments from kinematics based on interpolation in the sagittal plane of joint angles alone can introduce a significant error on the interpolated joint angular trajectory when applied to asymmetric dynamic lifts. Our goal was to evaluate interpolation of segment Euler angles for a wide range of dynamic asymmetric lifting tasks using cubic spline methods by comparing the interpolated values with the continuous measured ones. For most body segments, the estimated trajectories of segment Euler angles have less than 5 degrees RMSE (in each dimension) with 5-point cubic spline interpolation when there is no measurement error of interpolation points. Sensitivity analysis indicates that when the measurement error exists, the root mean square error (RMSE) of estimated trajectories increases. Comparison among different lifting conditions showed that lifting a load from a high initial position yielded a smaller RMSE than lifting from a low initial position. In conclusion, interpolation of segment Euler angles can provide a robust estimation of segment angular trajectories during asymmetric lifting when measurement error of interpolation points can be controlled at a low level.
Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:26
Orthogonal Trajectories
 01:30
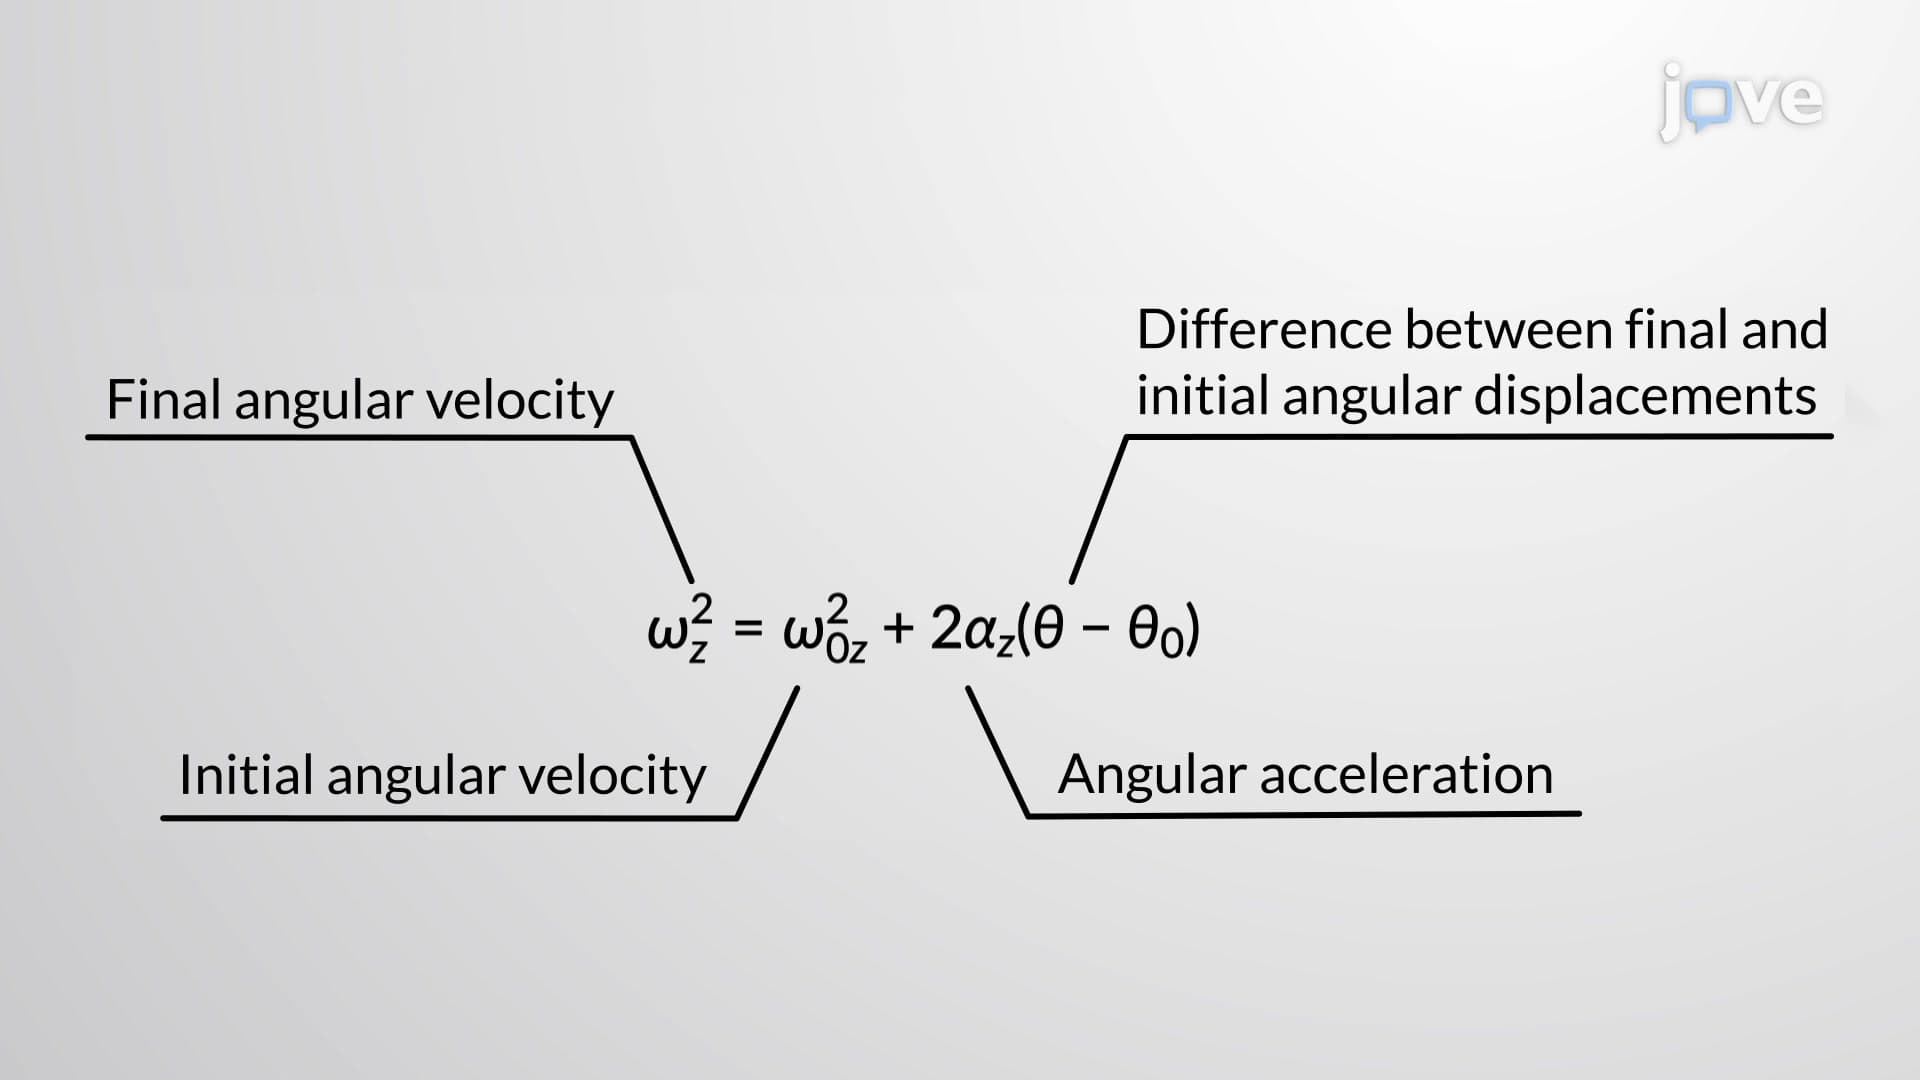
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:16
Rotation with Constant Angular Acceleration - II
The first...